Case Study
MunixTour - A Robot-Guided City Tour
TL;DR
We designed a robotic interface for city tours that serves the diverse needs of a tourist family group while adapting itself to the cityscape. Using Design Thinking methods - including moodboards, personas, focus groups and wireframes, we created a human-robot-interface concept. The concept was visualized in a video prototype.
Read Time: 7 min
| Duration: | 3 Months (approx. 4-6 hours per week) |
| Year: | 2022 |
| Context: | Design Workshop at University |
| The Team: | Three HCI students and one Art & Multimedia student |
| My Role: | UX Research & Design |
The Problem
How can the City of Munich enhance their tourist services by introducing a robotic interface for city tours that adapts to their tourists' diverse needs and does not interfere with the cityscape?
The Process
After evaluating requirements and user needs, we developed a concept for a robotic interface resulting in a video prototype as deliverable. The process we followed can be structured into four discrete steps: Discovery, Define, Ideate, and Hand-off.

Moodboard
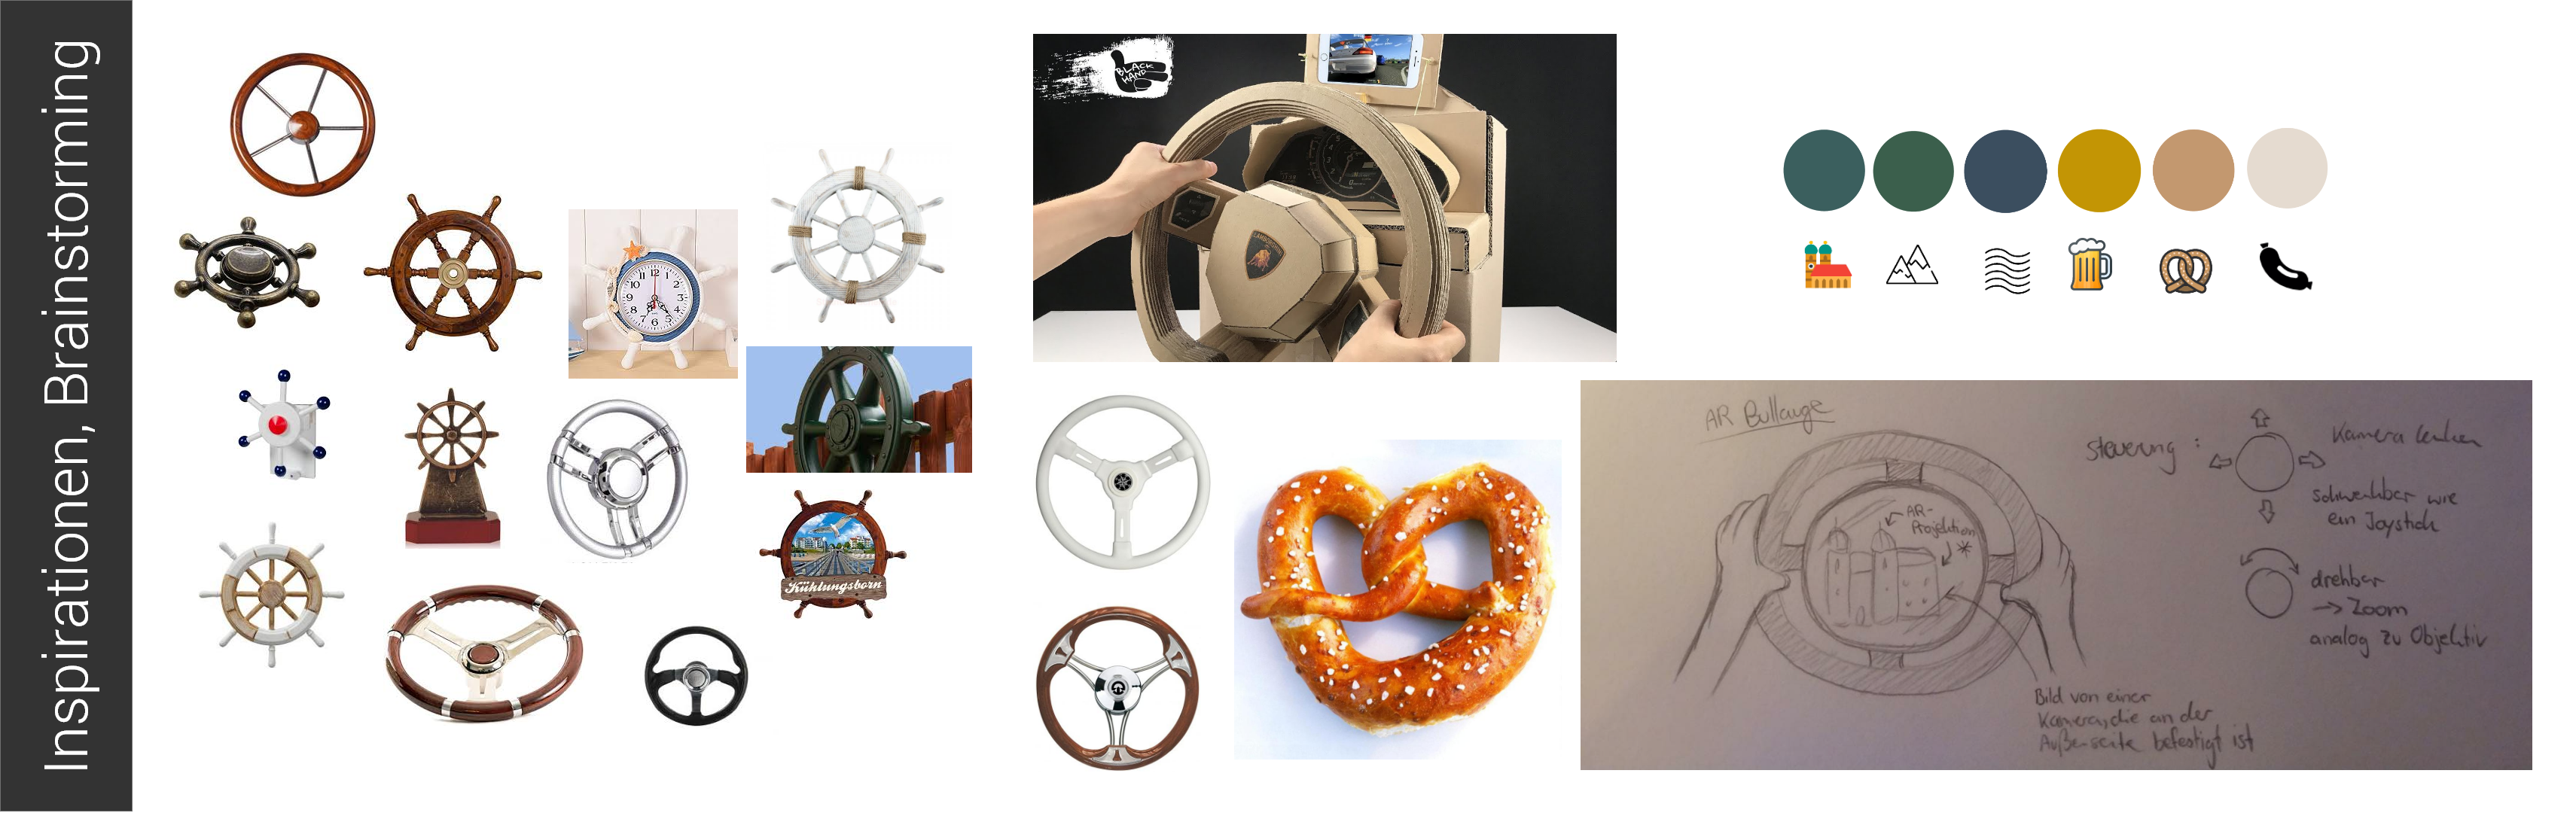
Using moodboards we explored the cityscape of munich with its various sights and buildings. We wanted our robotic interface to reflect the visual identity of munich including the bright fronts of the architecture and the bronze material of the sculptures. Since the city offers many parks and green spaces, we explored more organic forms to complement these traits. Our robotic interface might also be used by children, so we took inspiration of steering wheels, playgrounds and pretzels to apply an affordance for them to interact with the robot in a playful and exploring way.
Scribbles
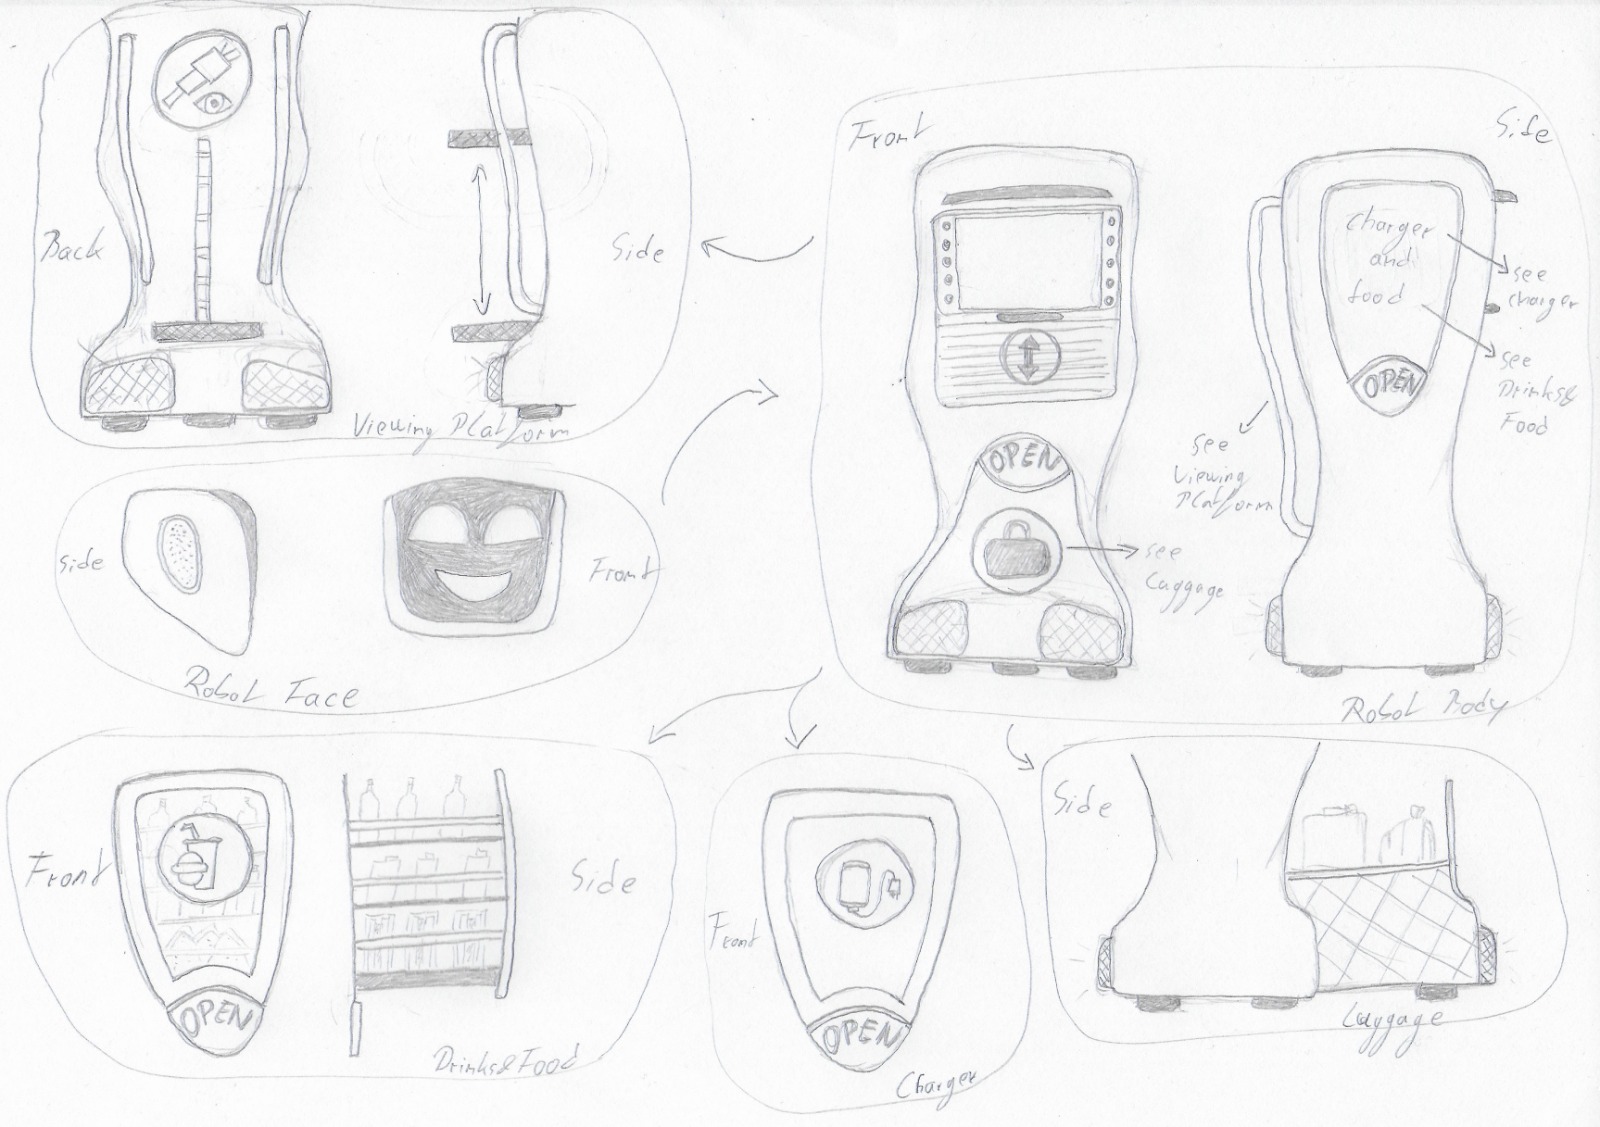
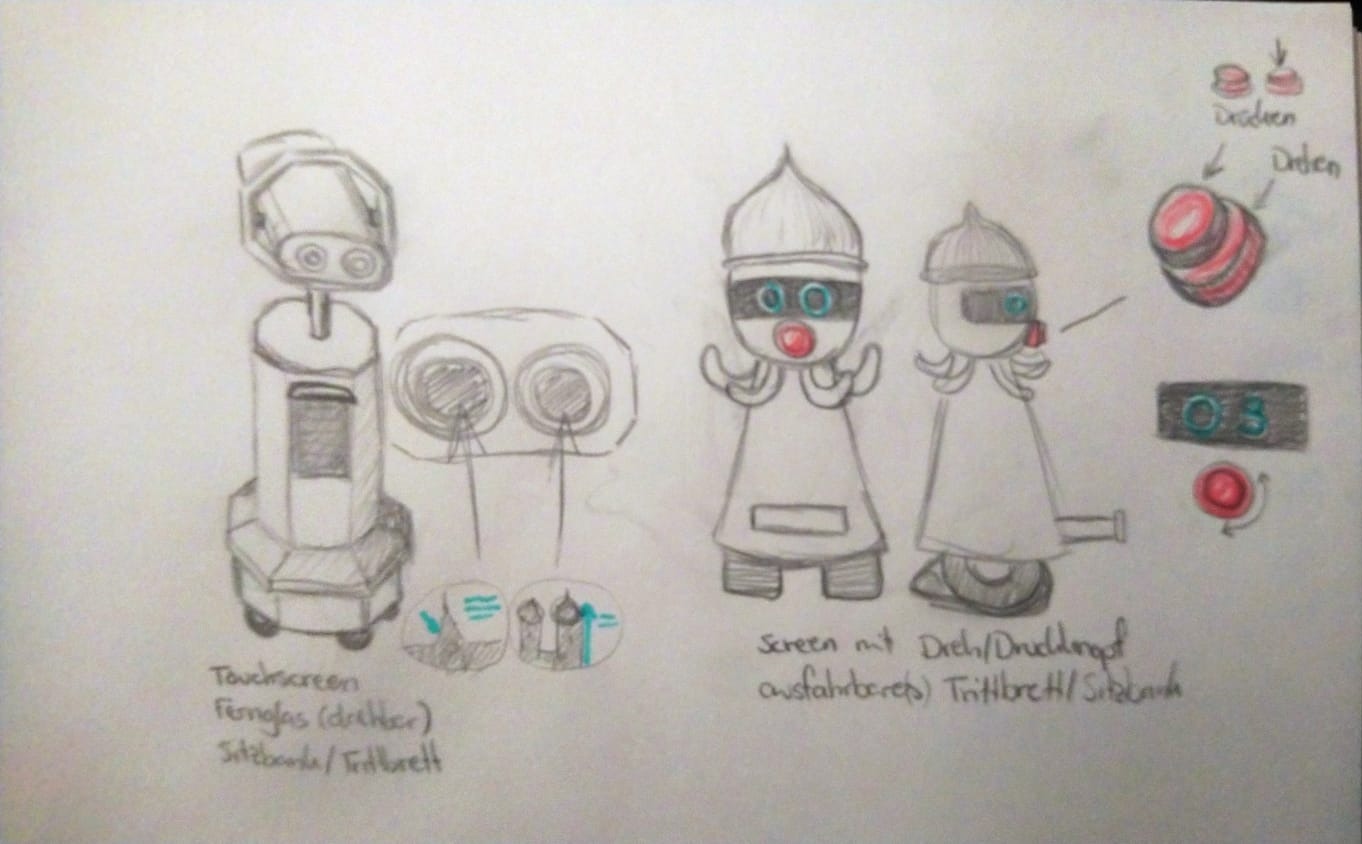
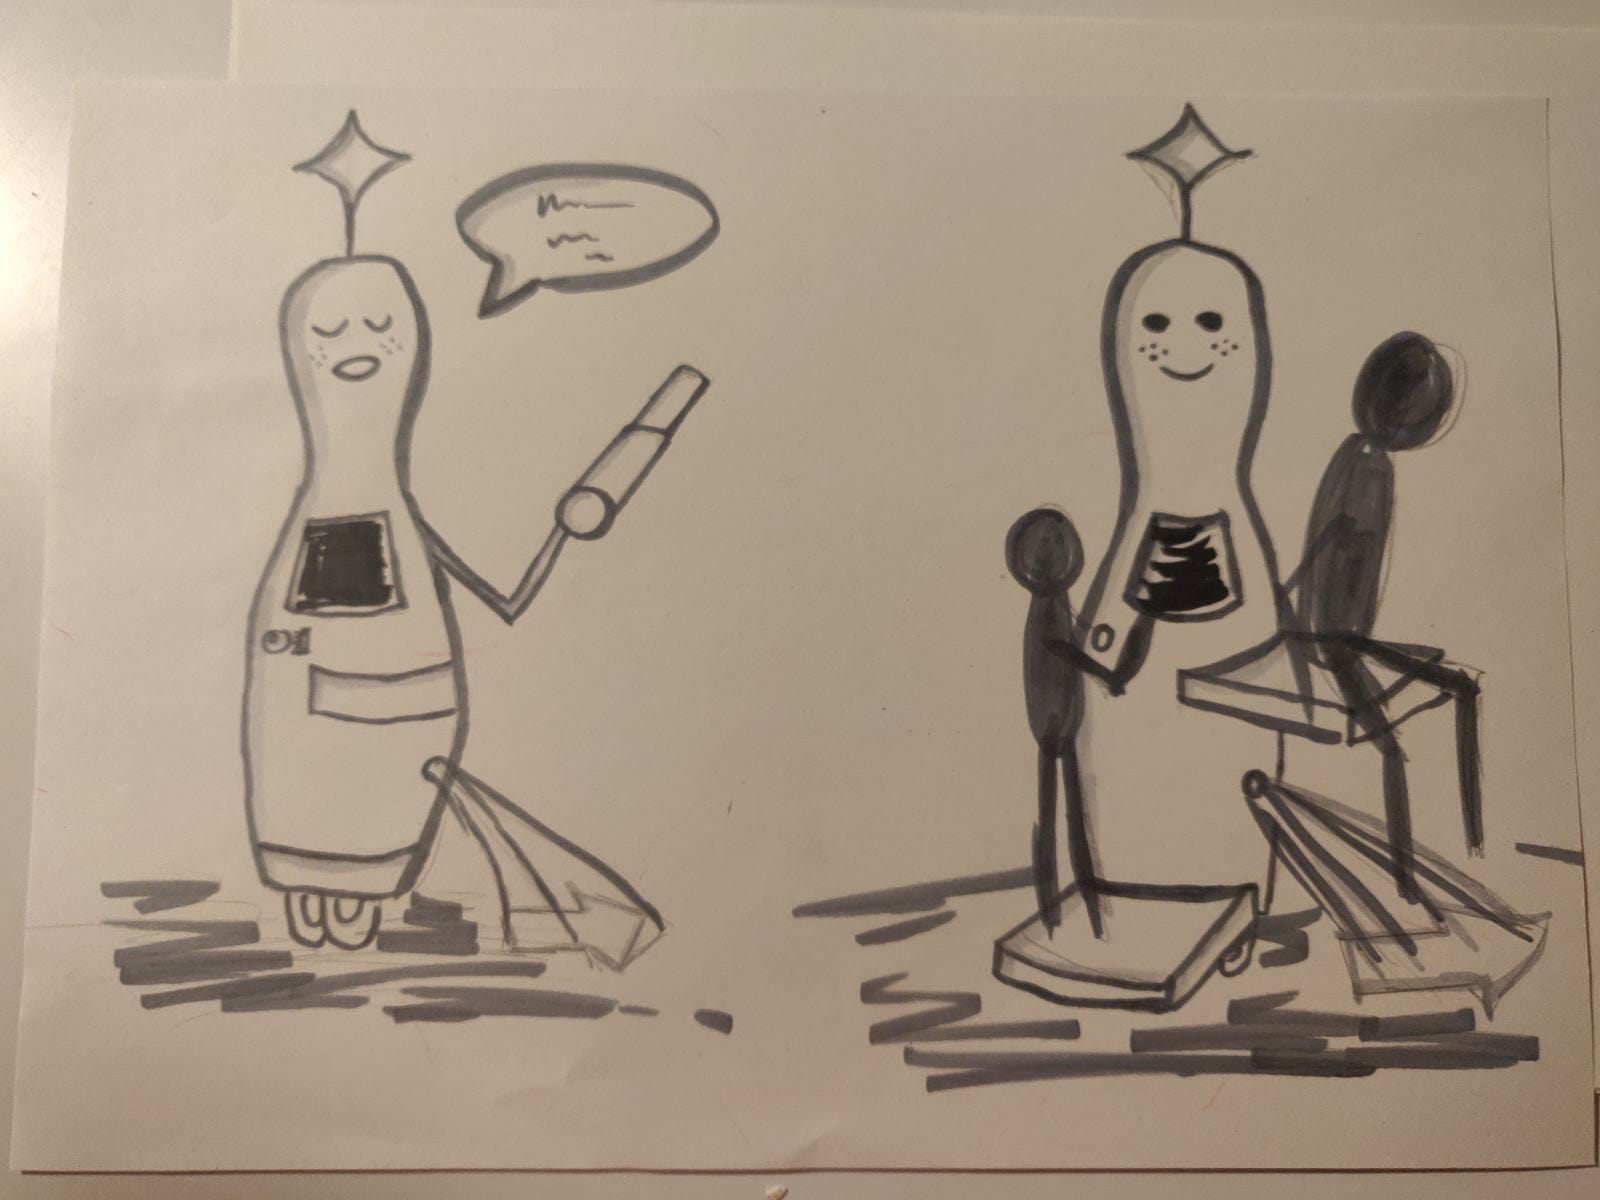
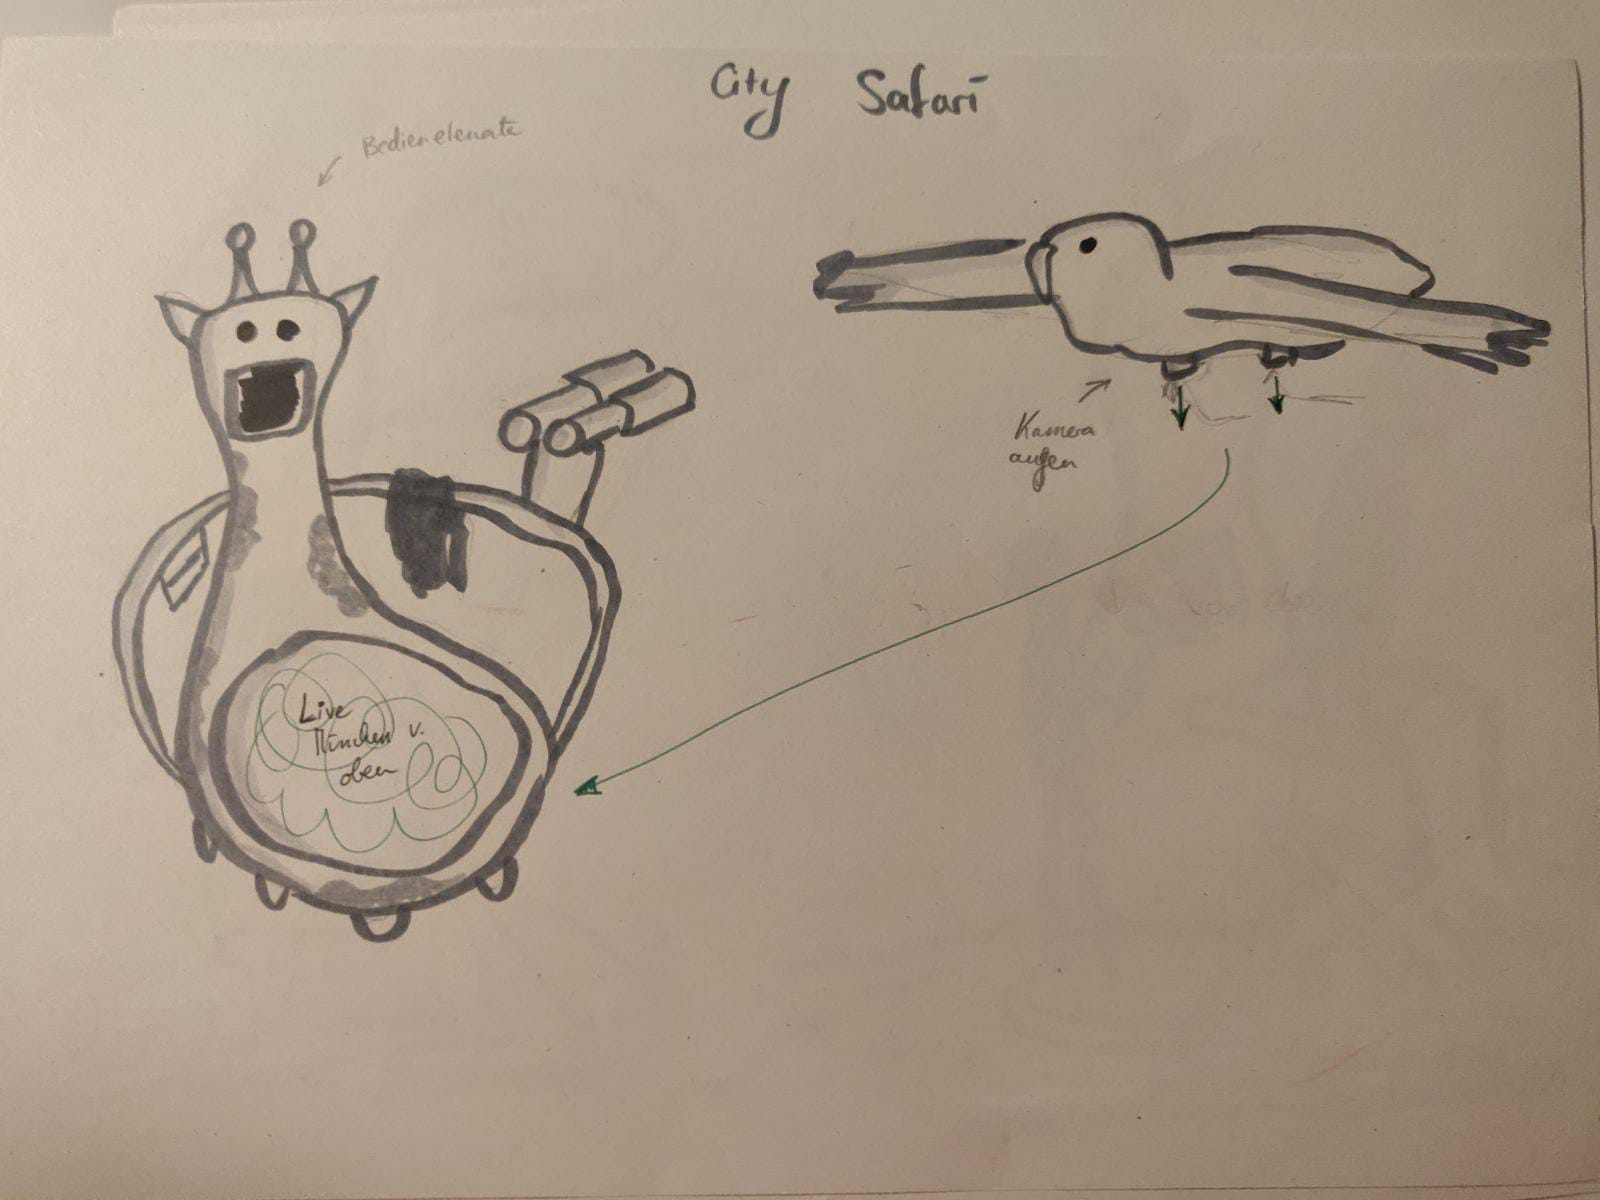
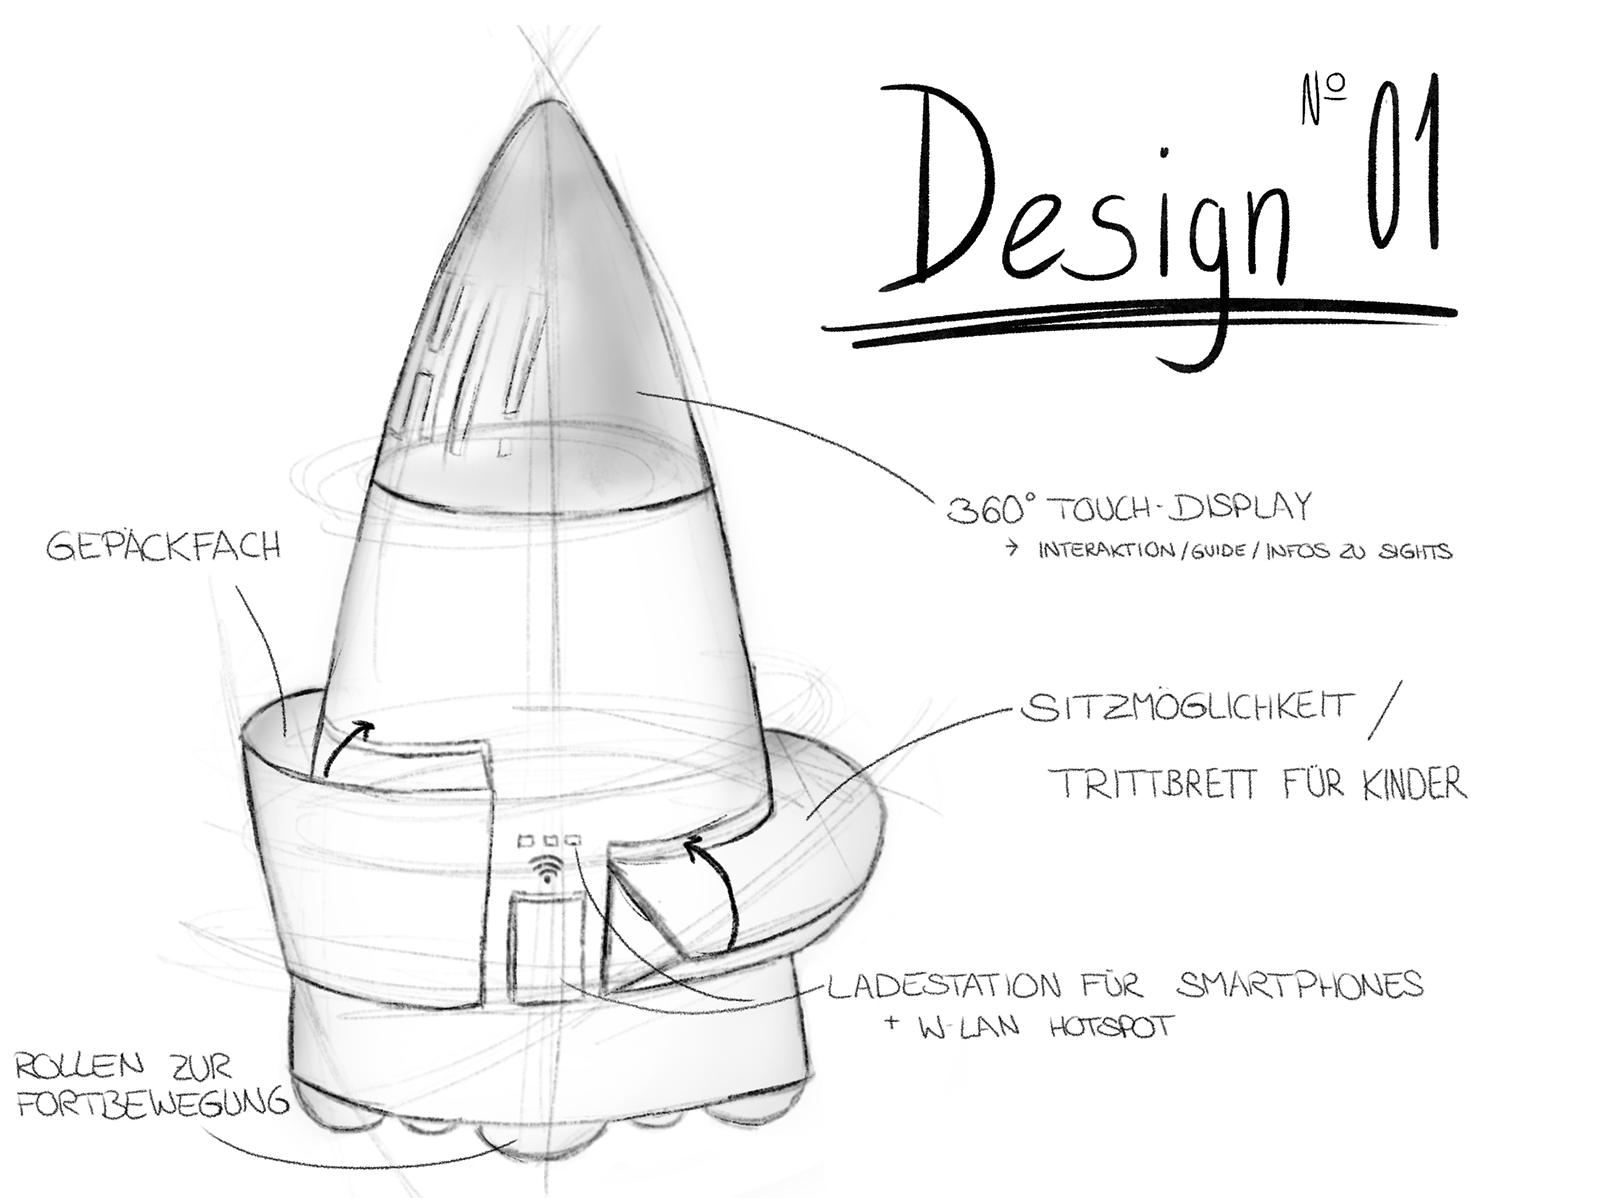
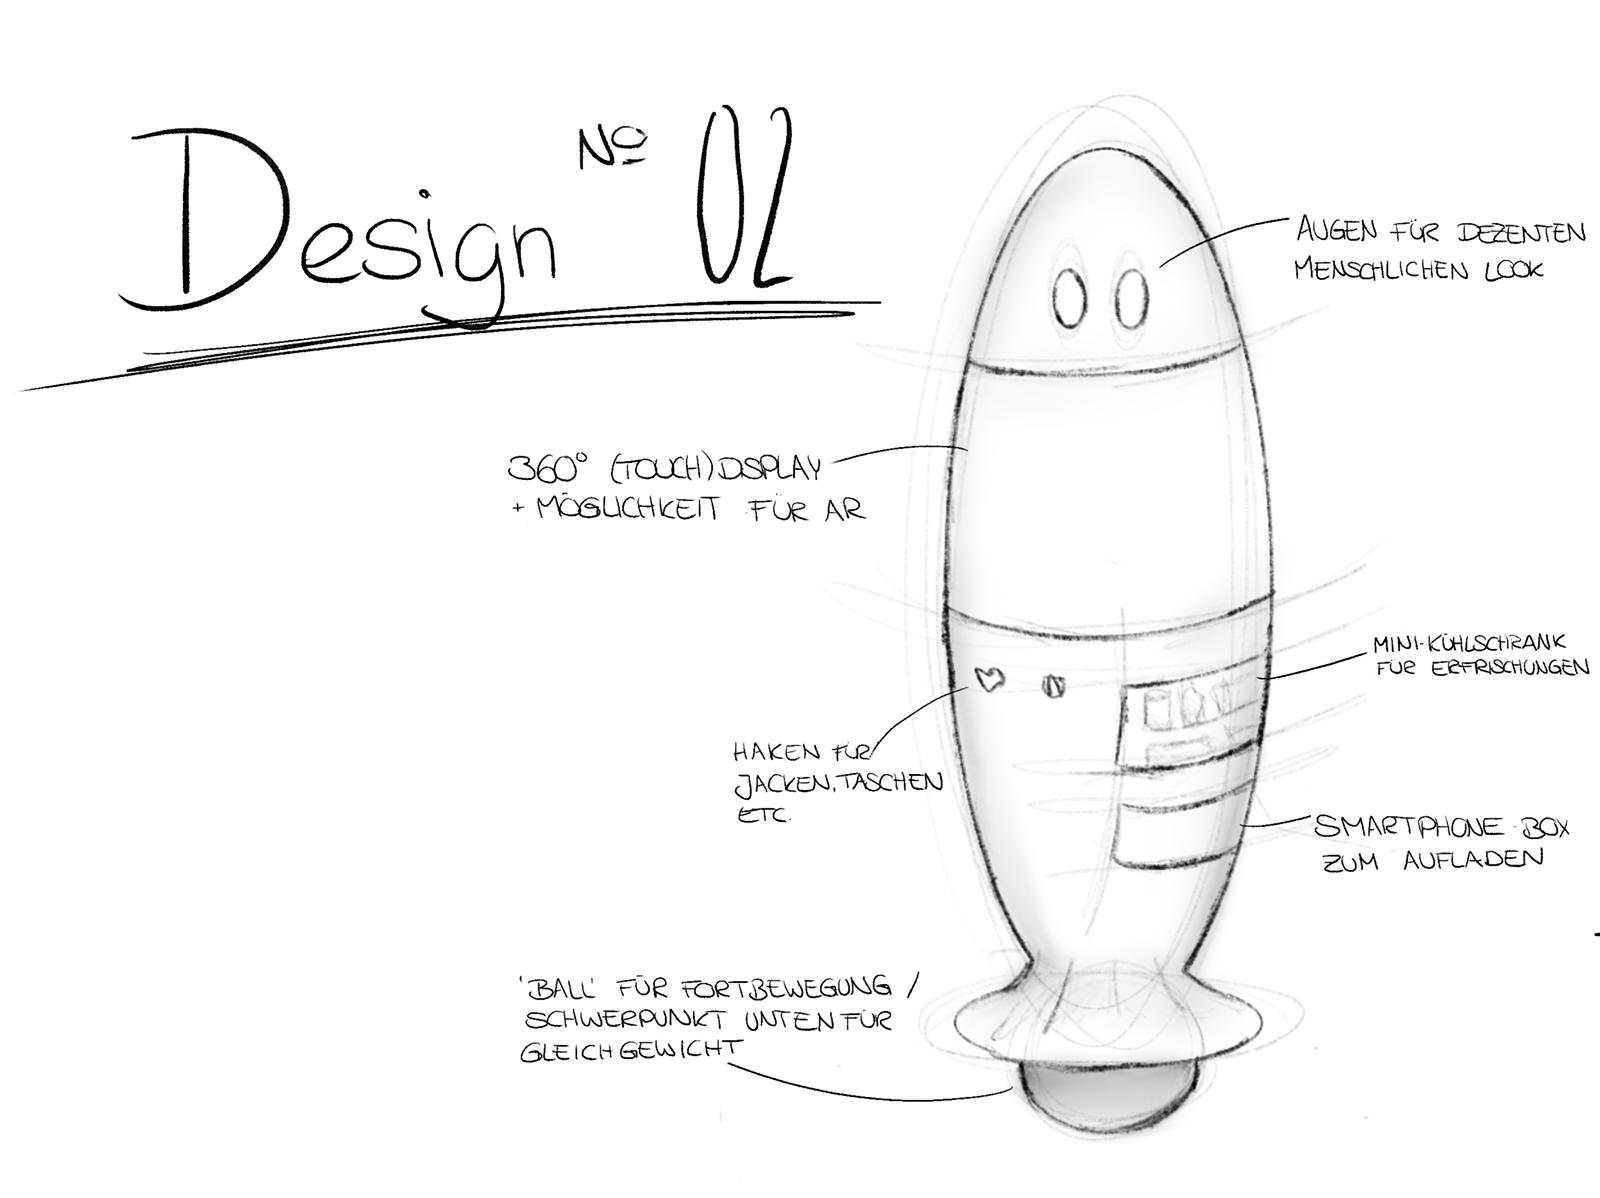
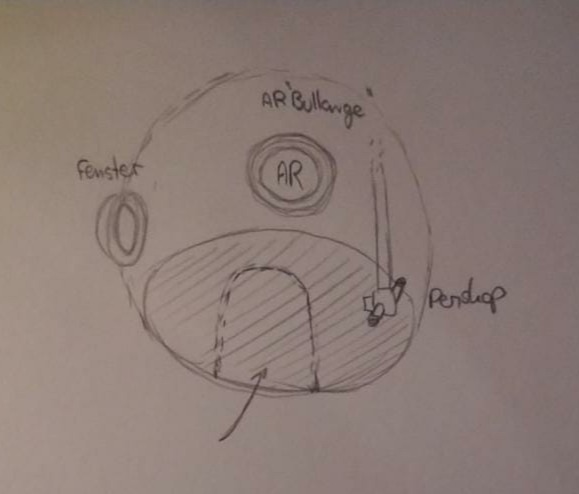
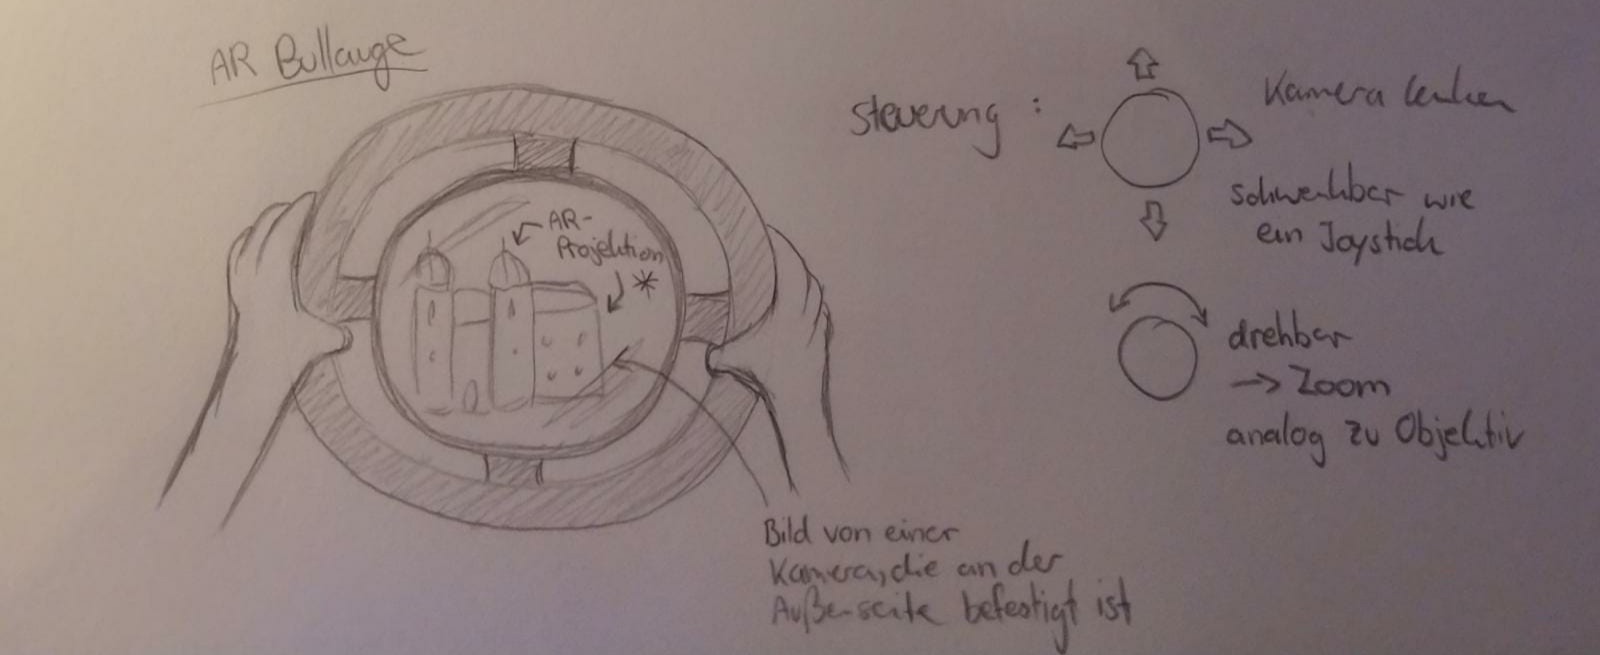
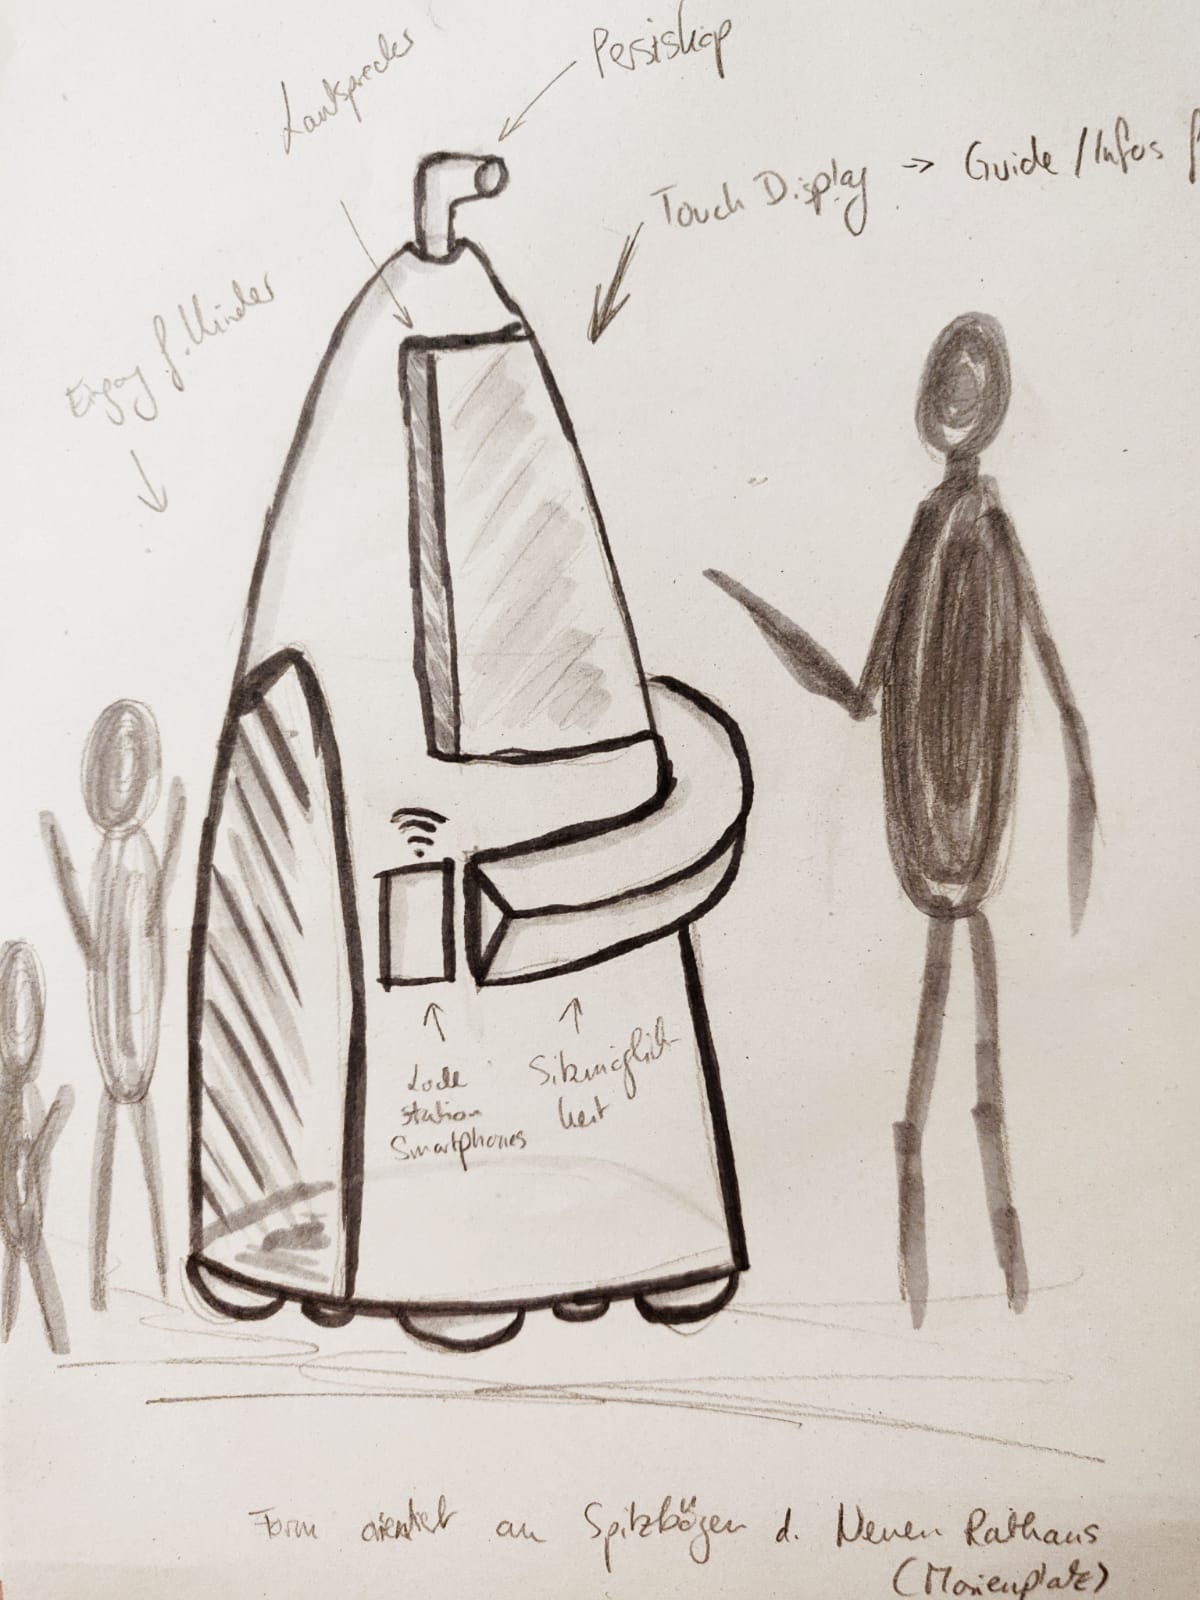
We sketched diverse ideas for a robotic cityguide based on a diversity of robot inspirations in several iterations. We used these scribbles later in the process to discuss design decisions and present features in our focus group. At this stage we were sure about integrating an AR-enhanced interactive feature for underaged users.
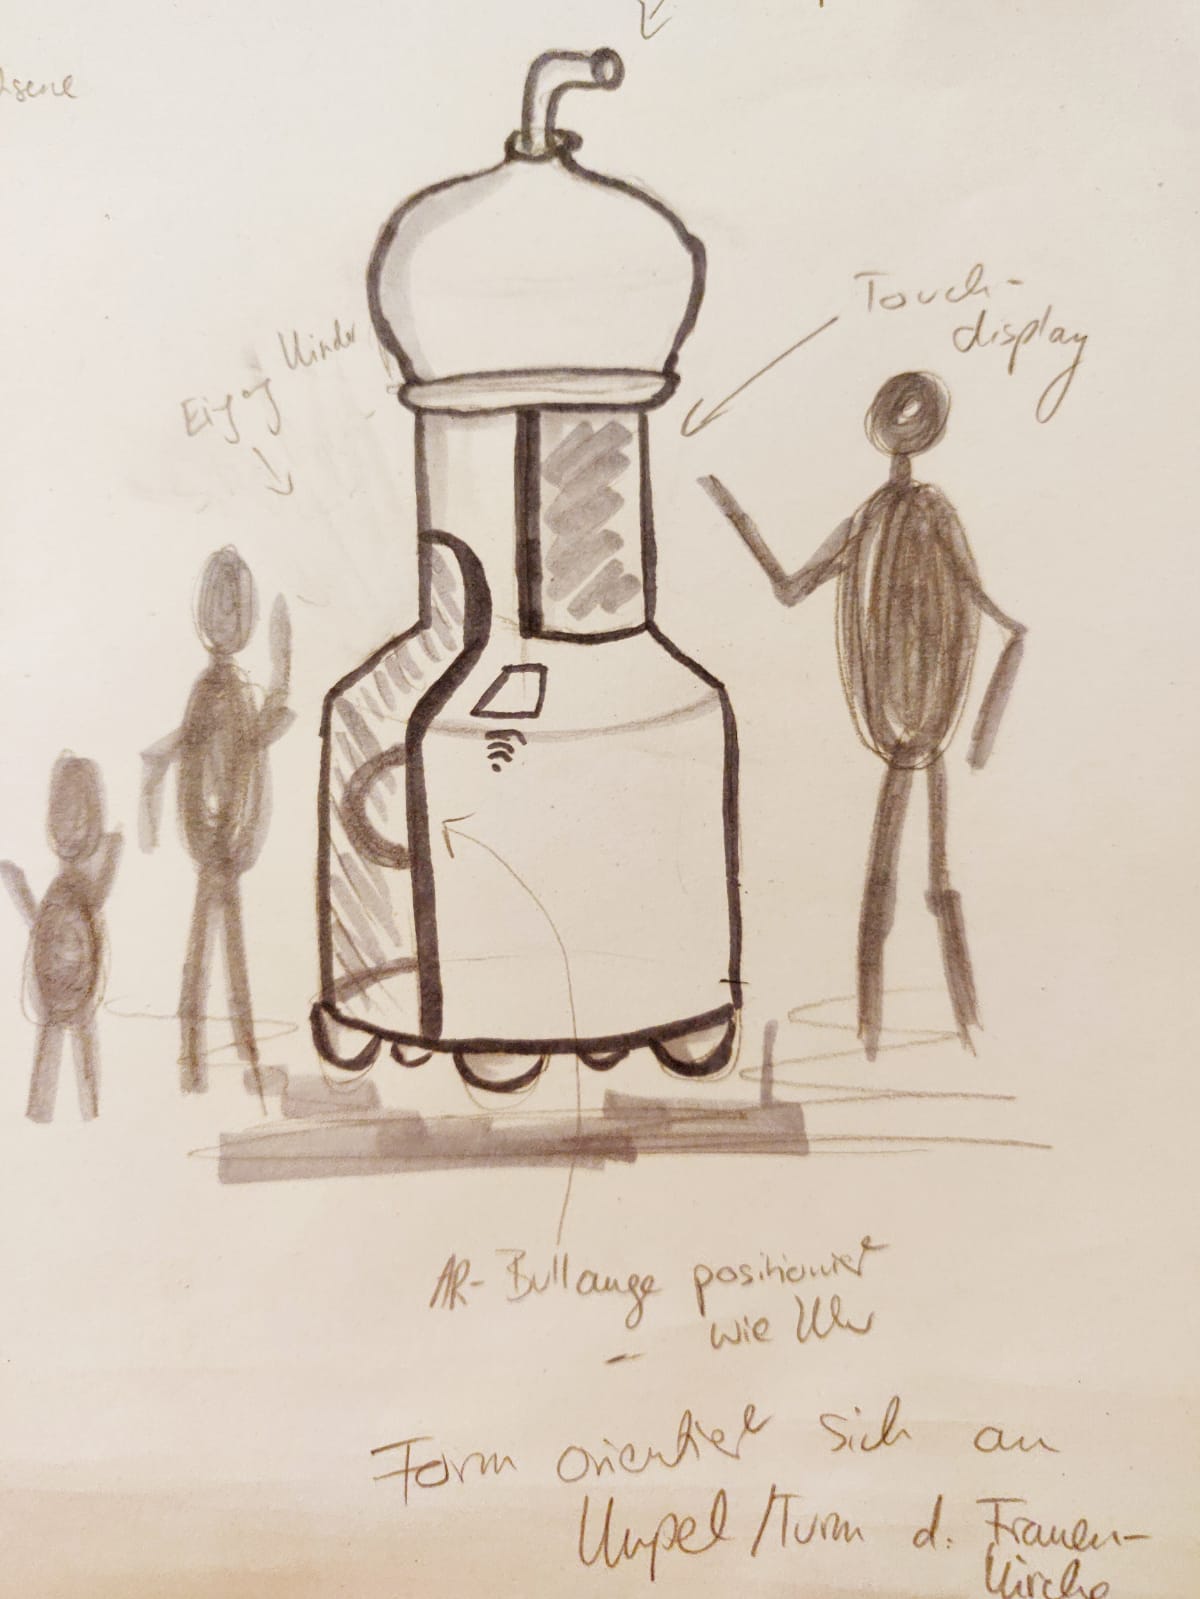
Personas
As a preparation for our focus group we developed three different personas that represent possible user groups of our robot. We included a parent that just wants an uncomplicated citytour, a senior that needs flexibility and carefulness, and an elementary student that demands fun and entertainment.
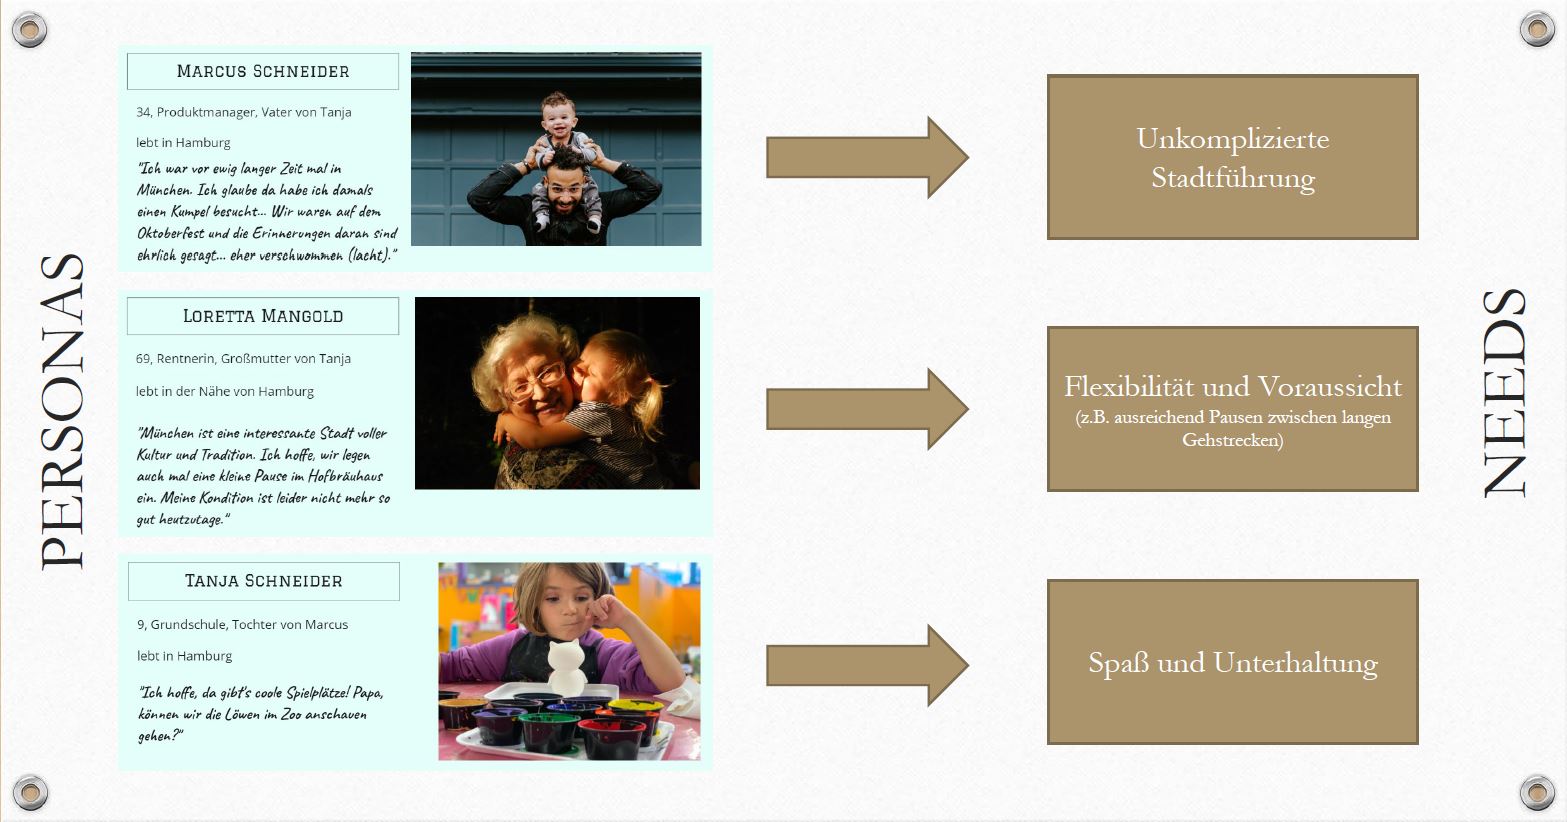
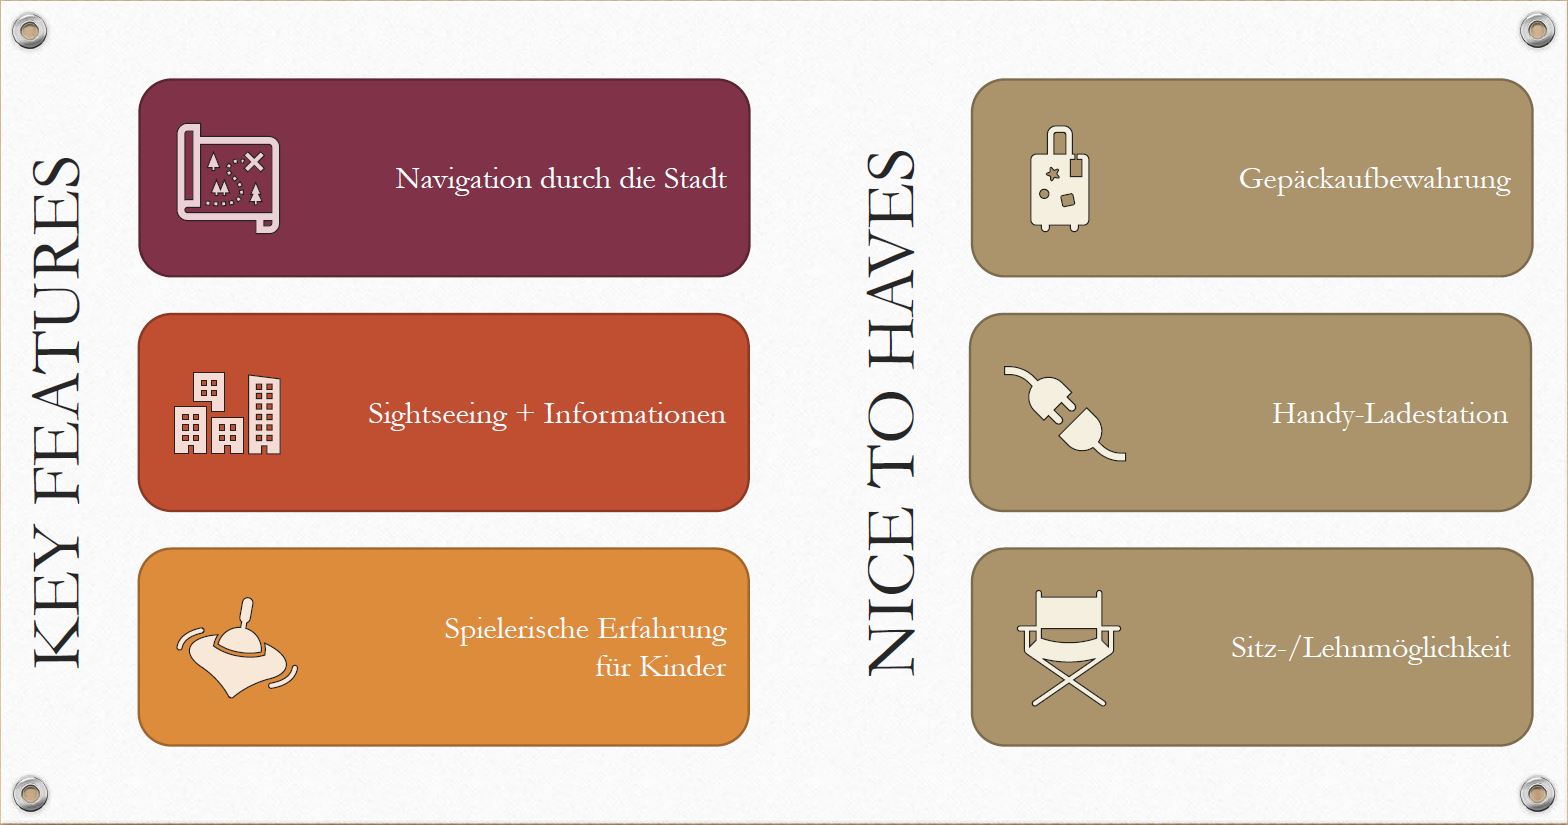
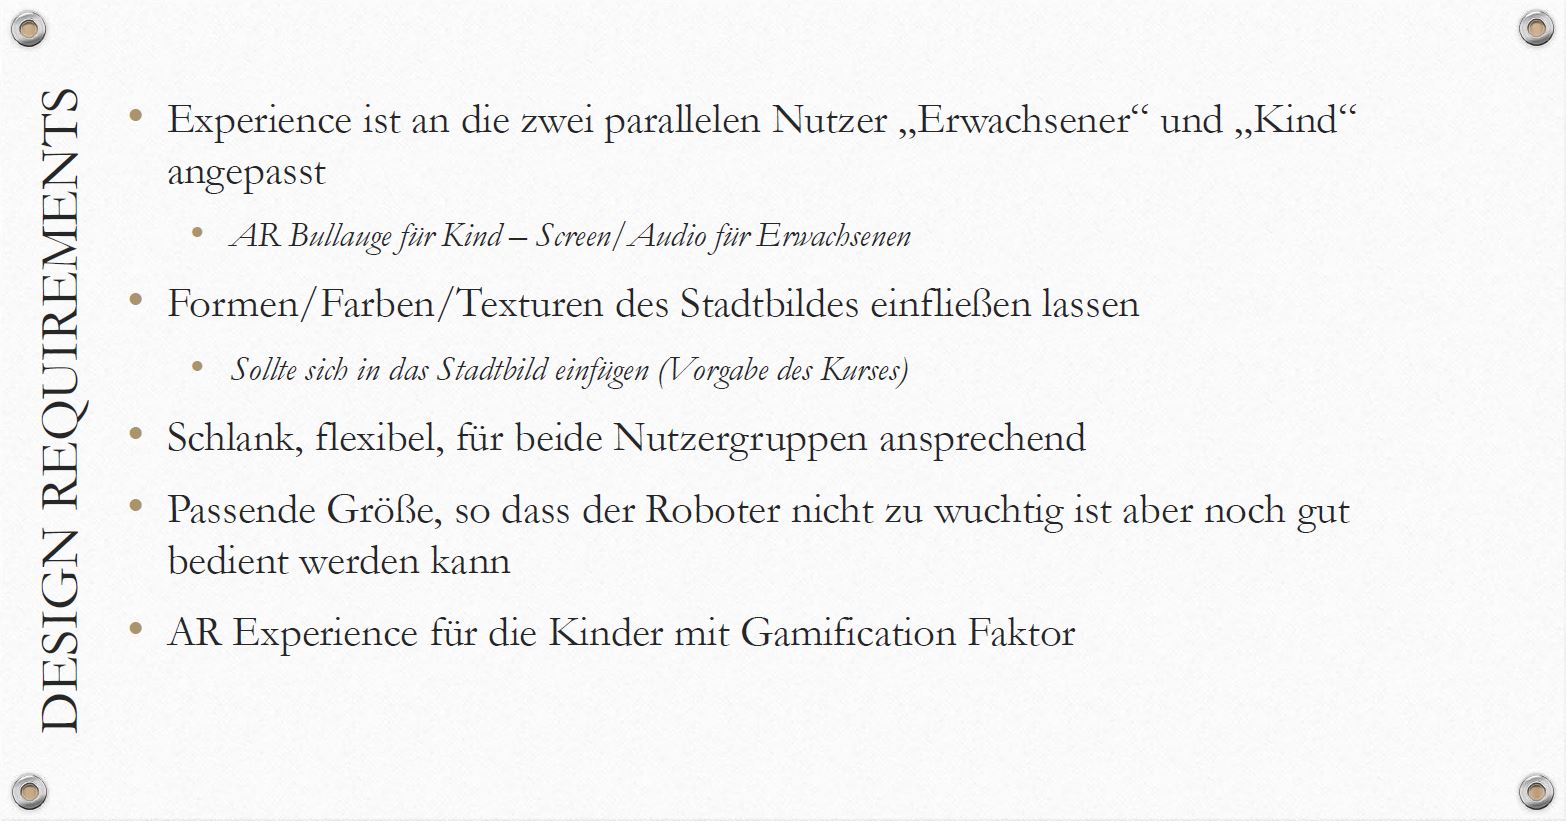
Based on these three personas, three key features (navigation, informative sightseeing, and playful experience for kids), and three nice to have features (baggage room, phone charging, and seating). Furthermore, we defined the condition that the sightseeing experiences for both the adults and children should be possible to take place at the same time without interfering.
Focus Group
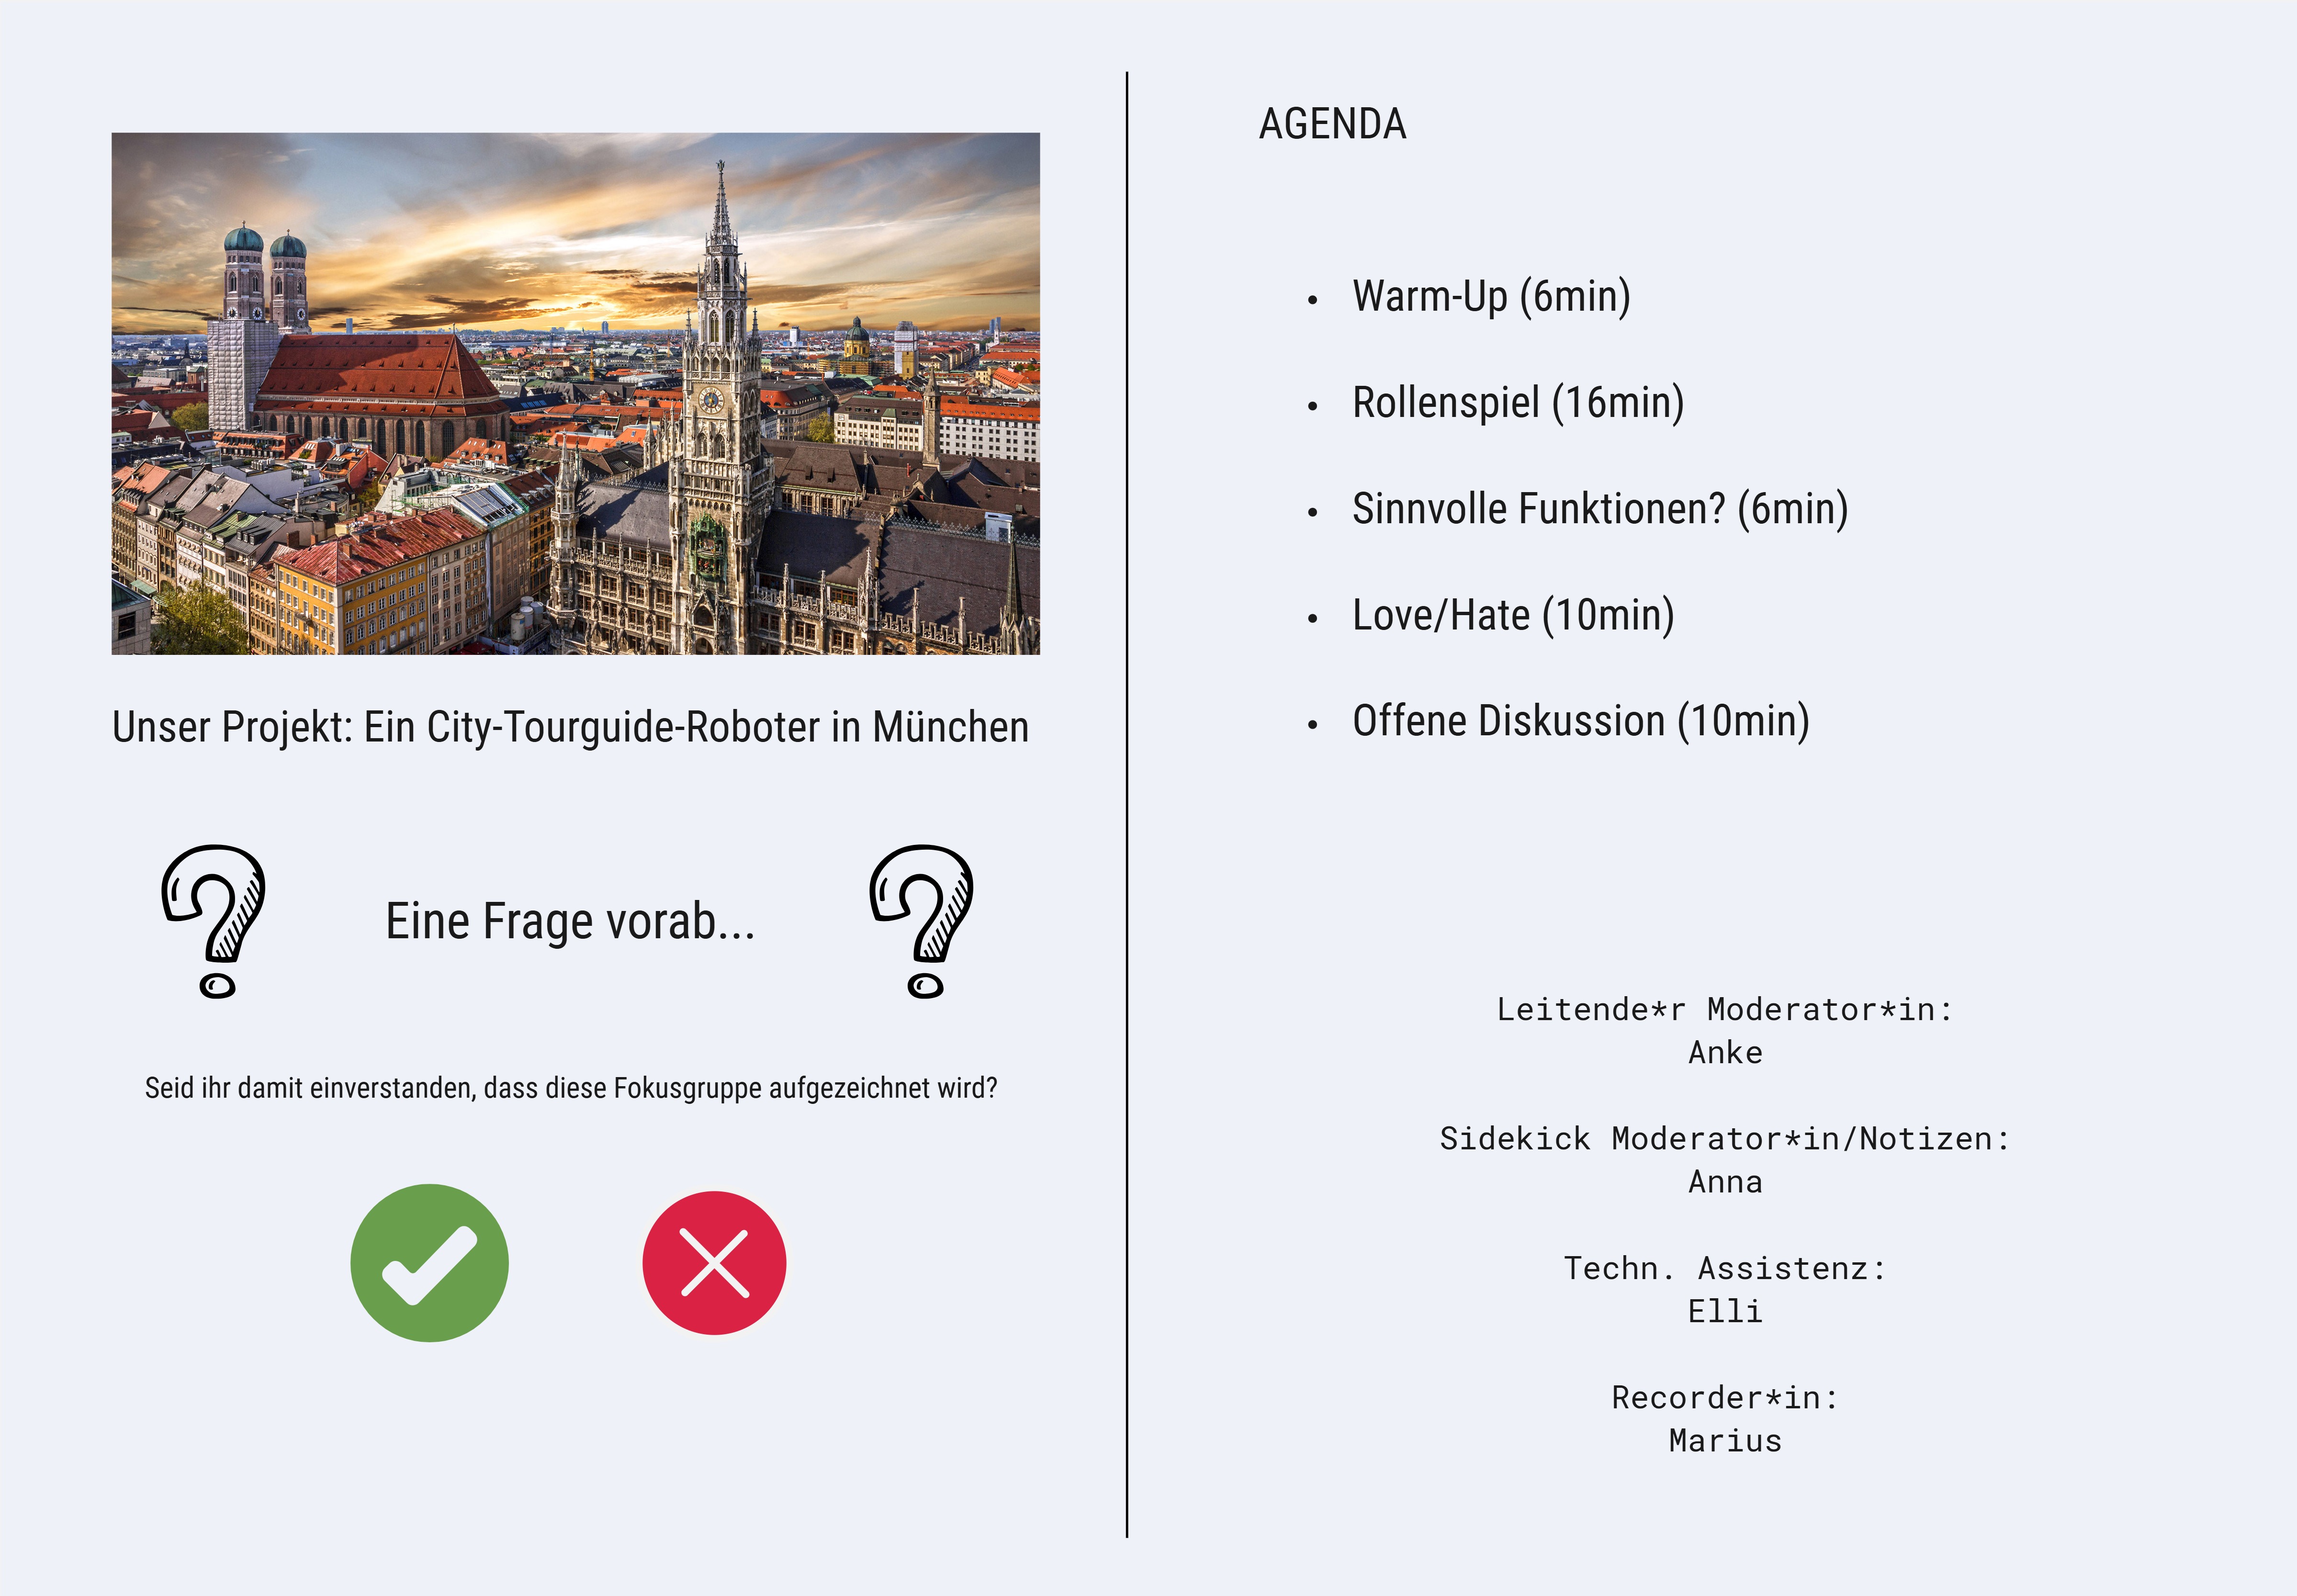
To gain more insights from potential users, we organized a remote focus group to discuss ideas, problems and features. For the material we used a Miro board and for the communication a Zoom call. We invited six individuals - four actually joined the call. The agenda started with a short warm-up, followed by a role play, where the participants took over the role of the personas we defined earlier. After that, they discussed several feature and design ideas and were invited to give their very own imagination of a robot cityguide. The session was documented using written record.
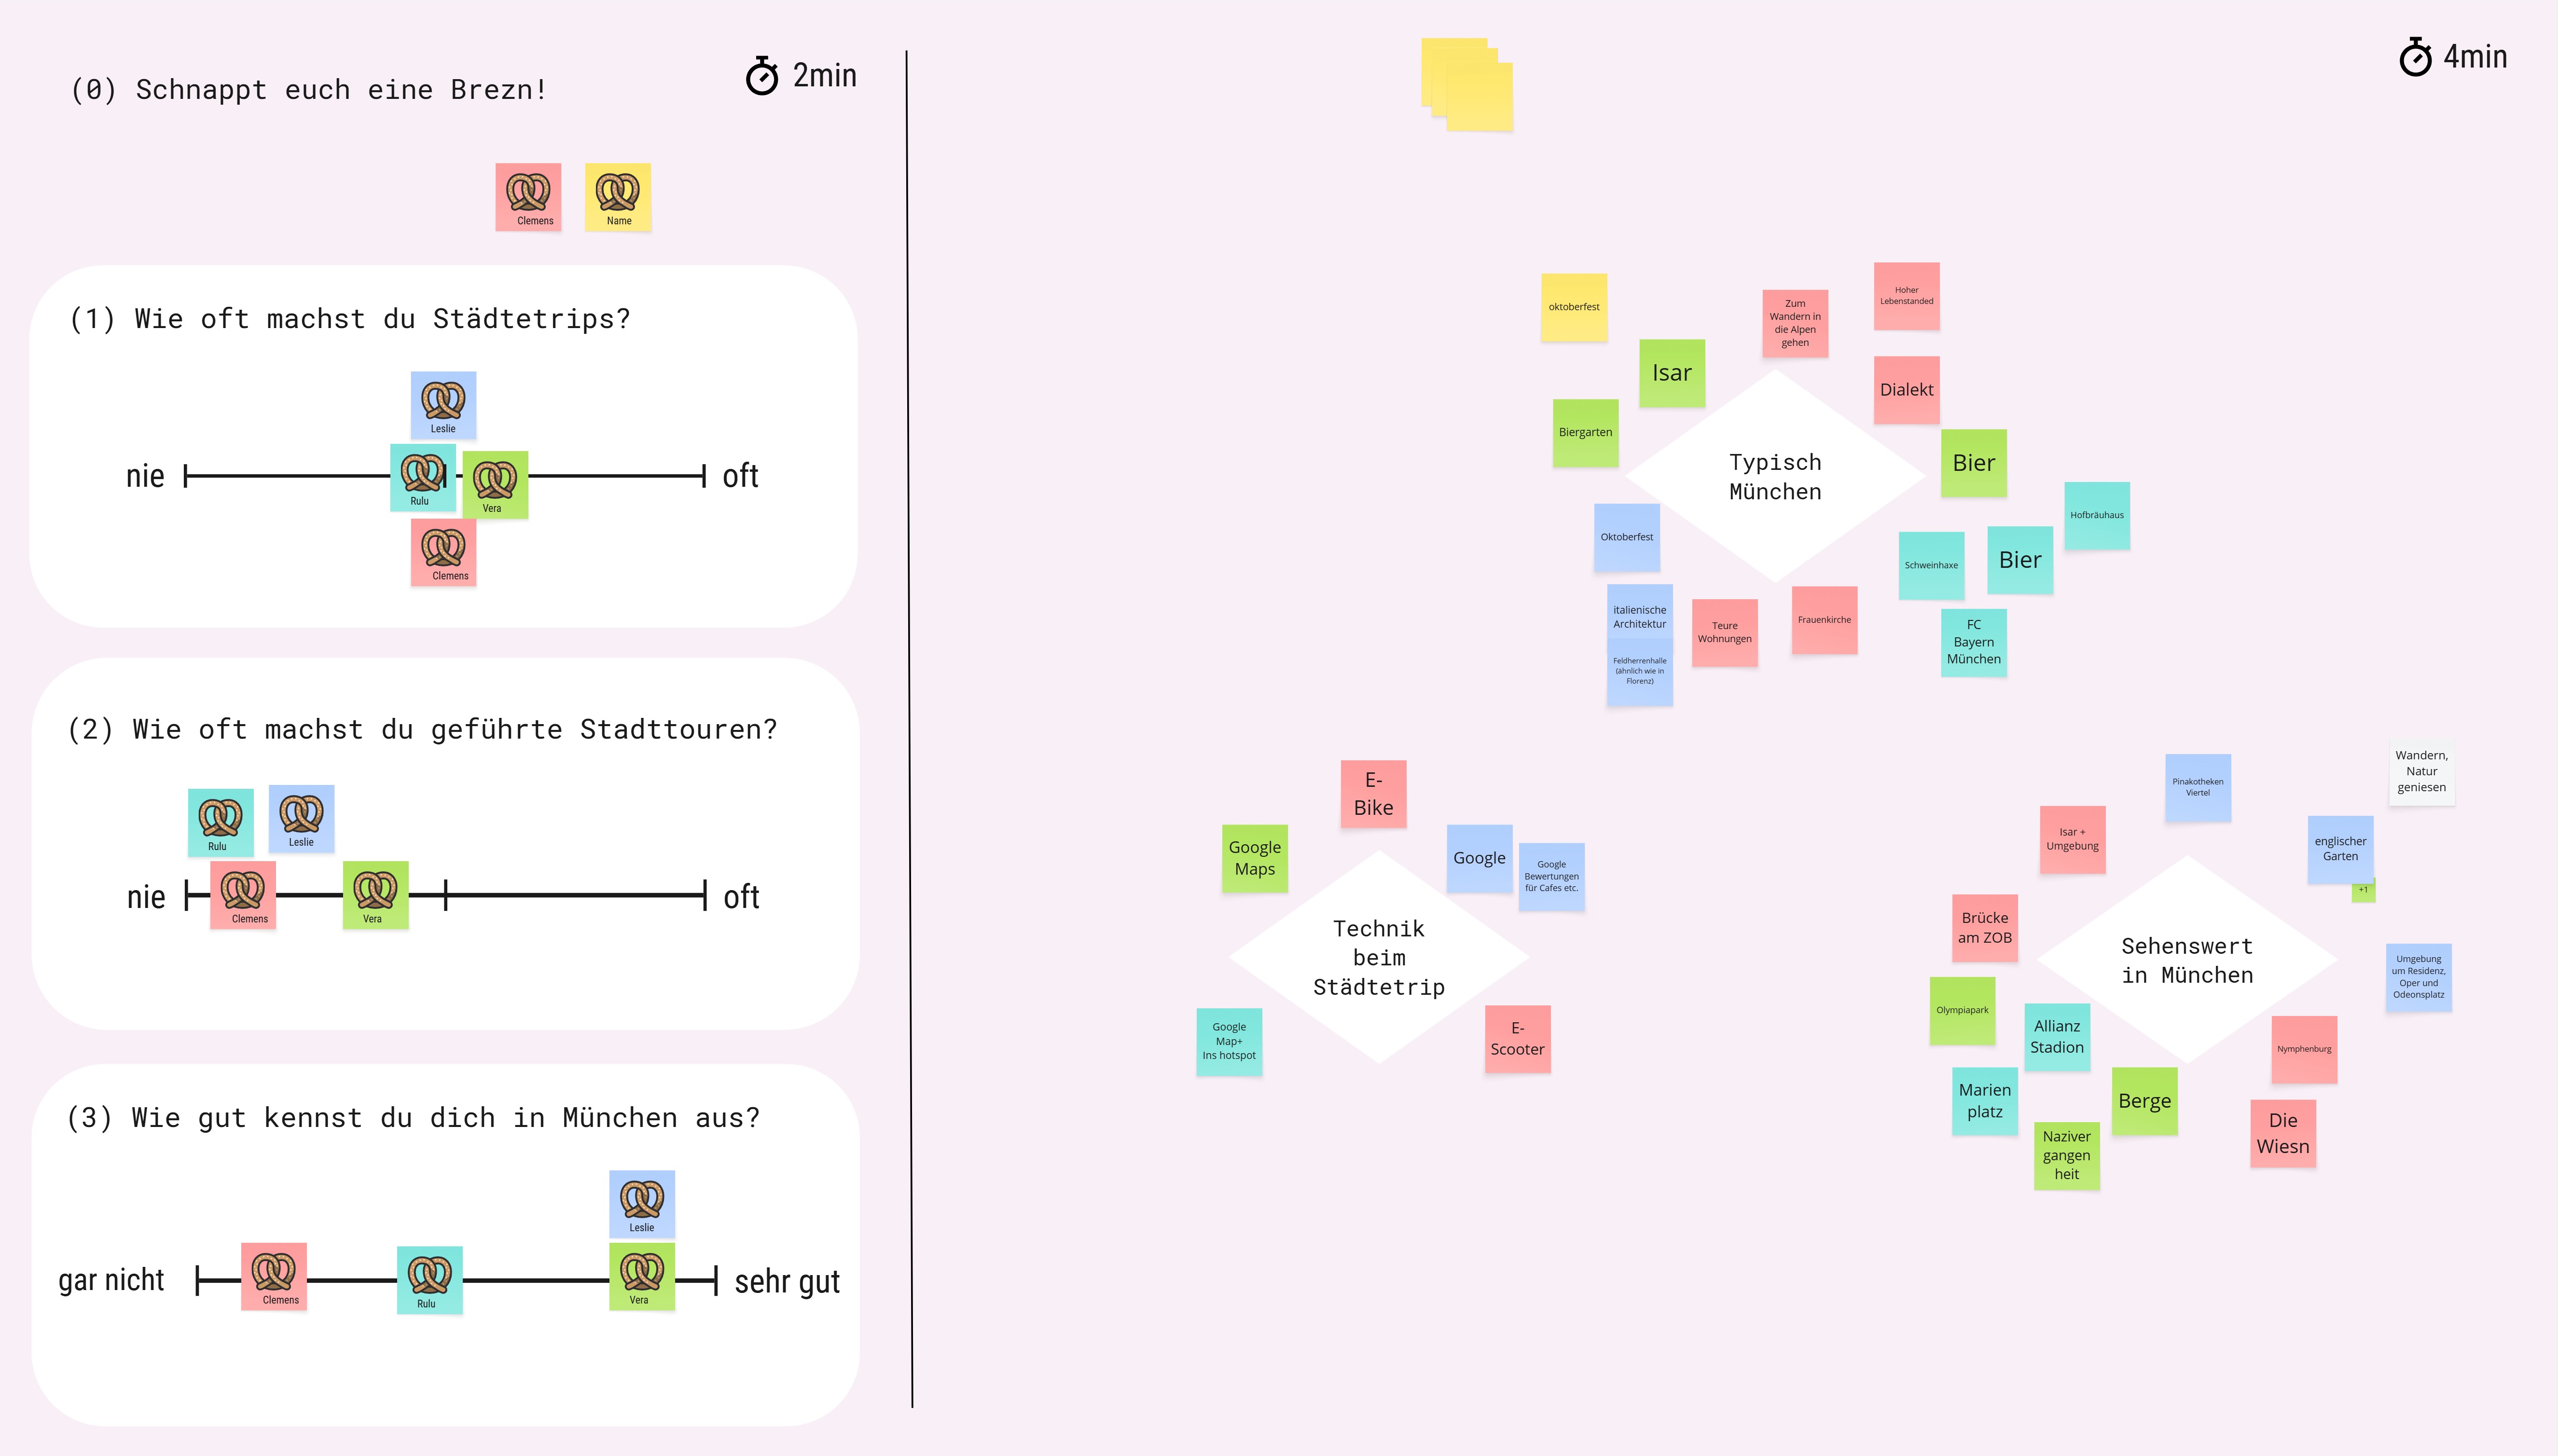
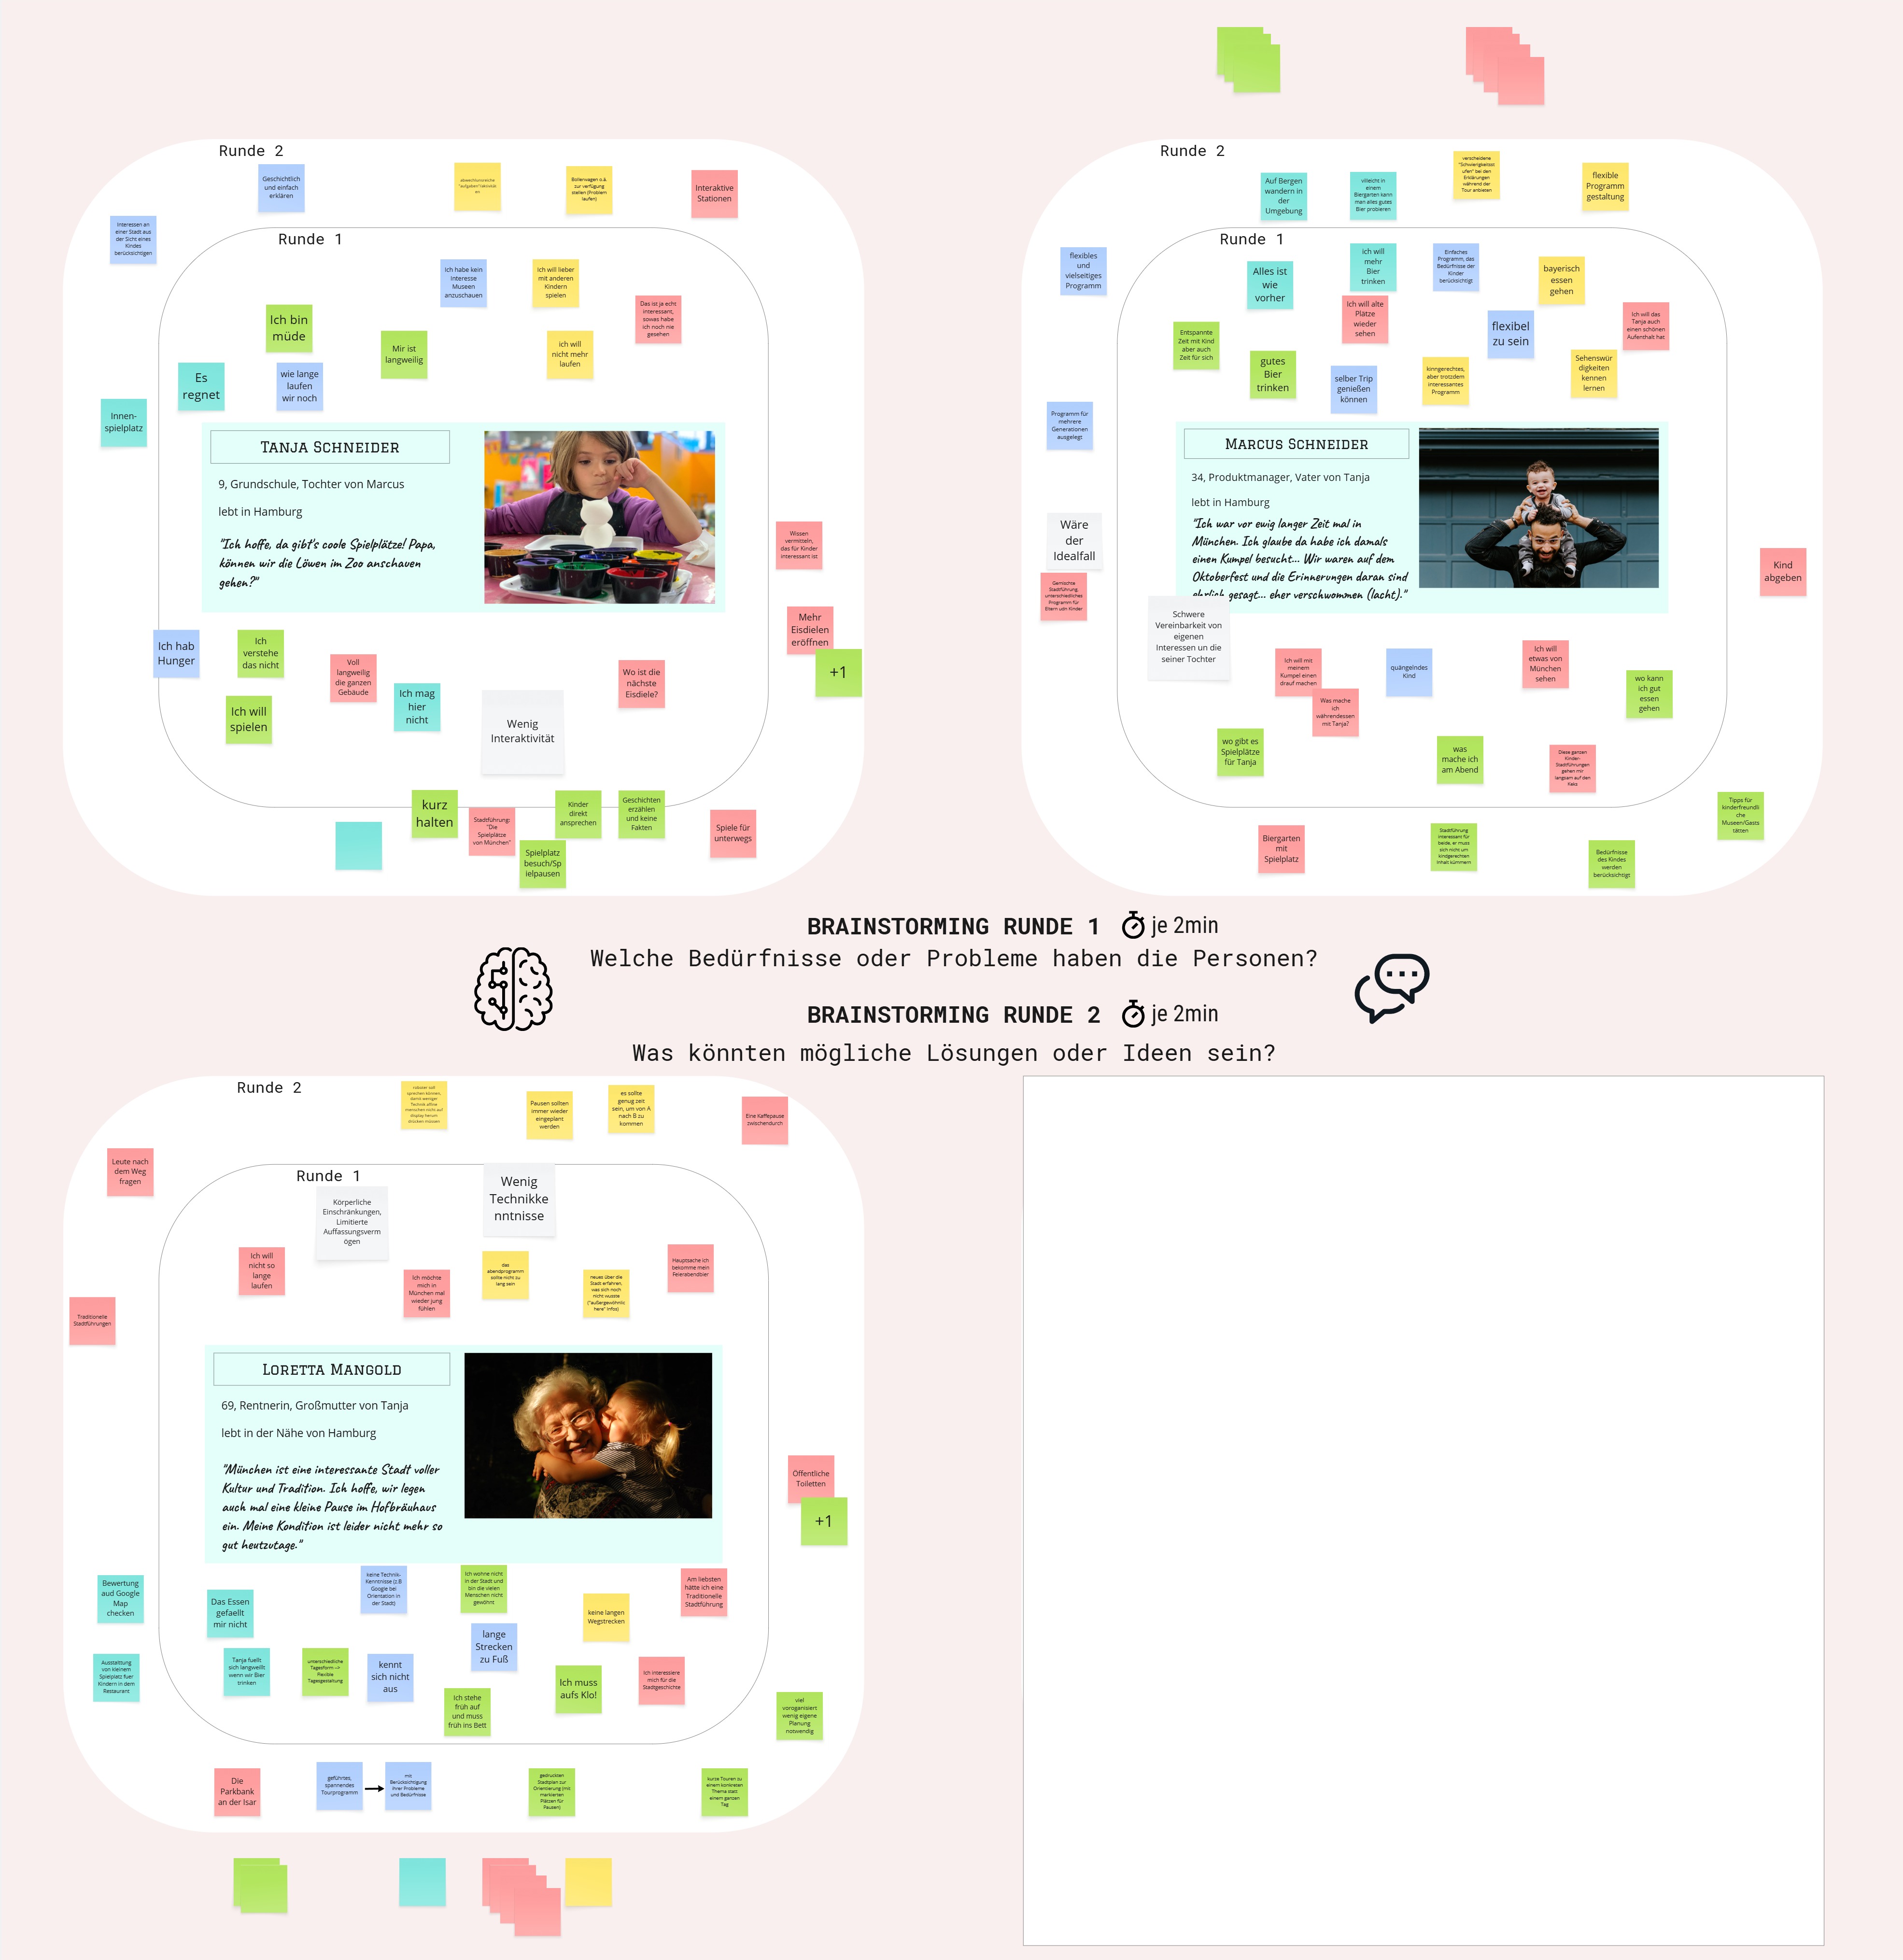
Afterwards, we systematically analysed the insights of the focus group and derived key take aways on which we based our further work. These included the visual design of the robot, interaction concepts, and general feature decisions. For example: The participants saw the requirement for a seating, but asked for a minimalistic concept, as they didn't want it to look like the main feature. On the other hand, they really liked the charging feature and described it as a useful feature for long trips and also proposed to integrate a WiFi hotspot.
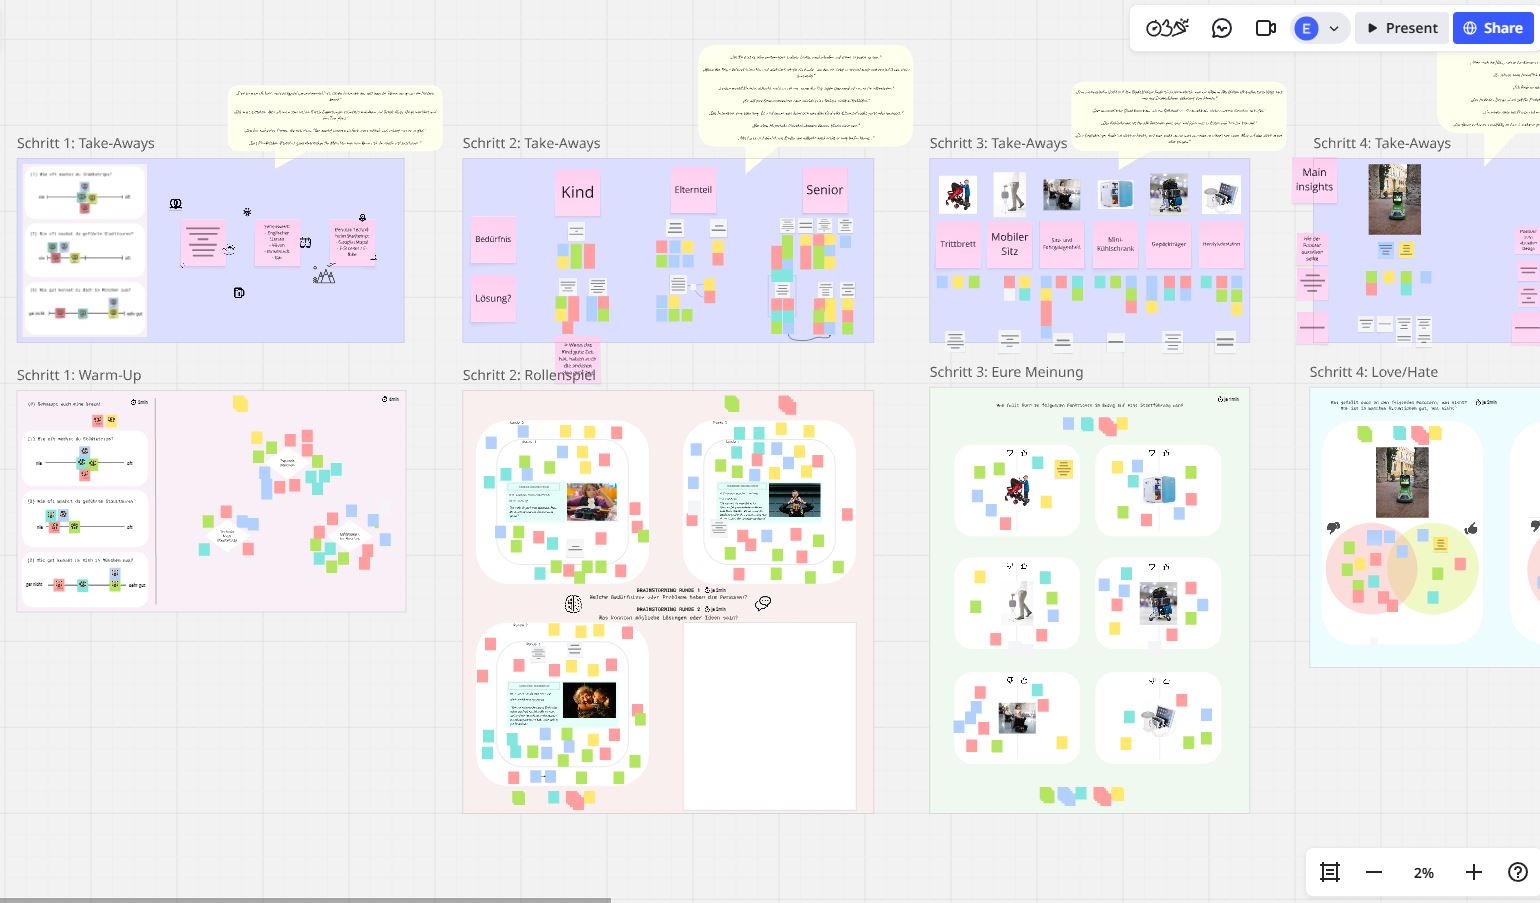
Our initial assumption was that the seating area should be a central feature of the robot. The focus group showed us the opposite: While participants wanted to be able to use it, they didn’t want it to be perceived as a dominant design element—the robot should remain recognizable primarily as a guide, not as a bench. This insight led us to design the seating area to be minimalist and recessed into the background, while placing greater emphasis on the charging and navigation features, which were well received.
Storyboard
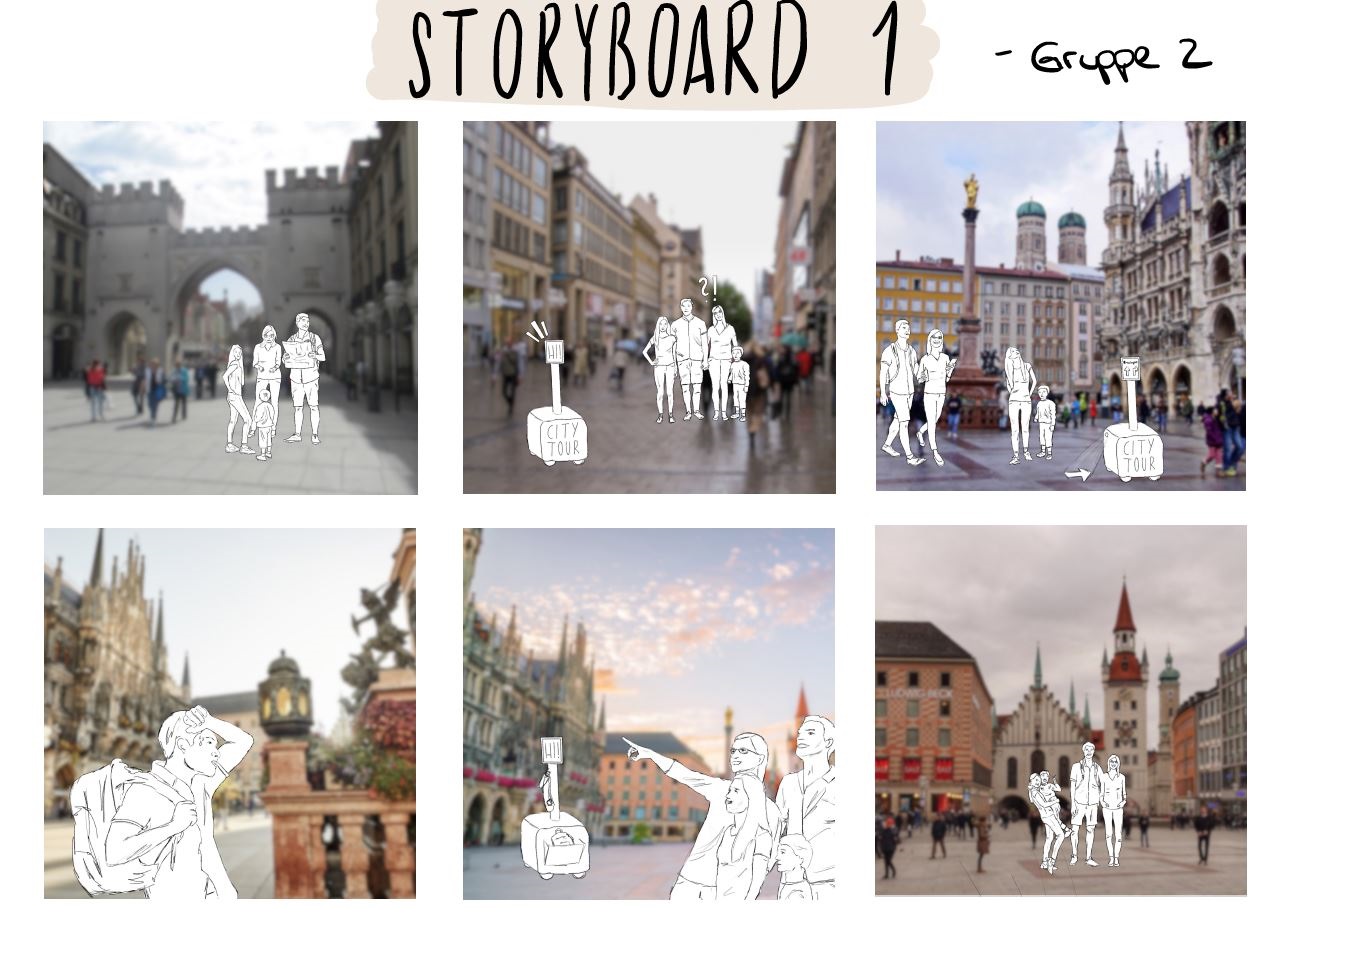
The insights gained from the focus group participants inspired us to explore multiple key and nice to have features for the robot by creating three storyboards. Storyboard 1 displays a minimalistic robot head that serves as attention signal and projector for navigation symbols on the floor while it offers a small space for baggage.
Storyboard 2 presents a robot with voice interface and a height-adjustable footboard for children.
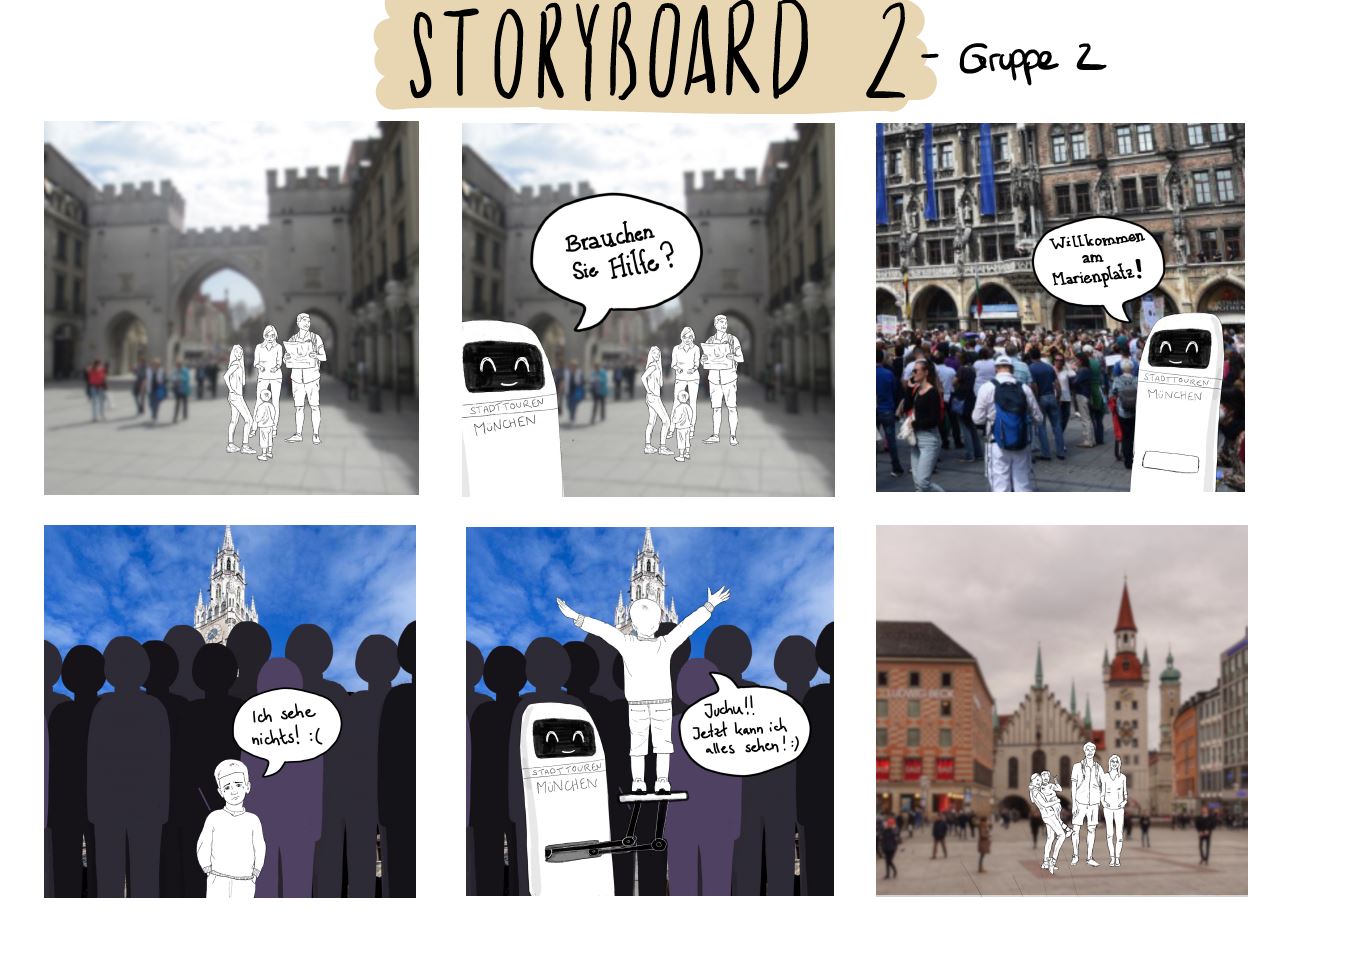
Finally, Storyboard 3 shows the interaction by a phone application and the charging feature.
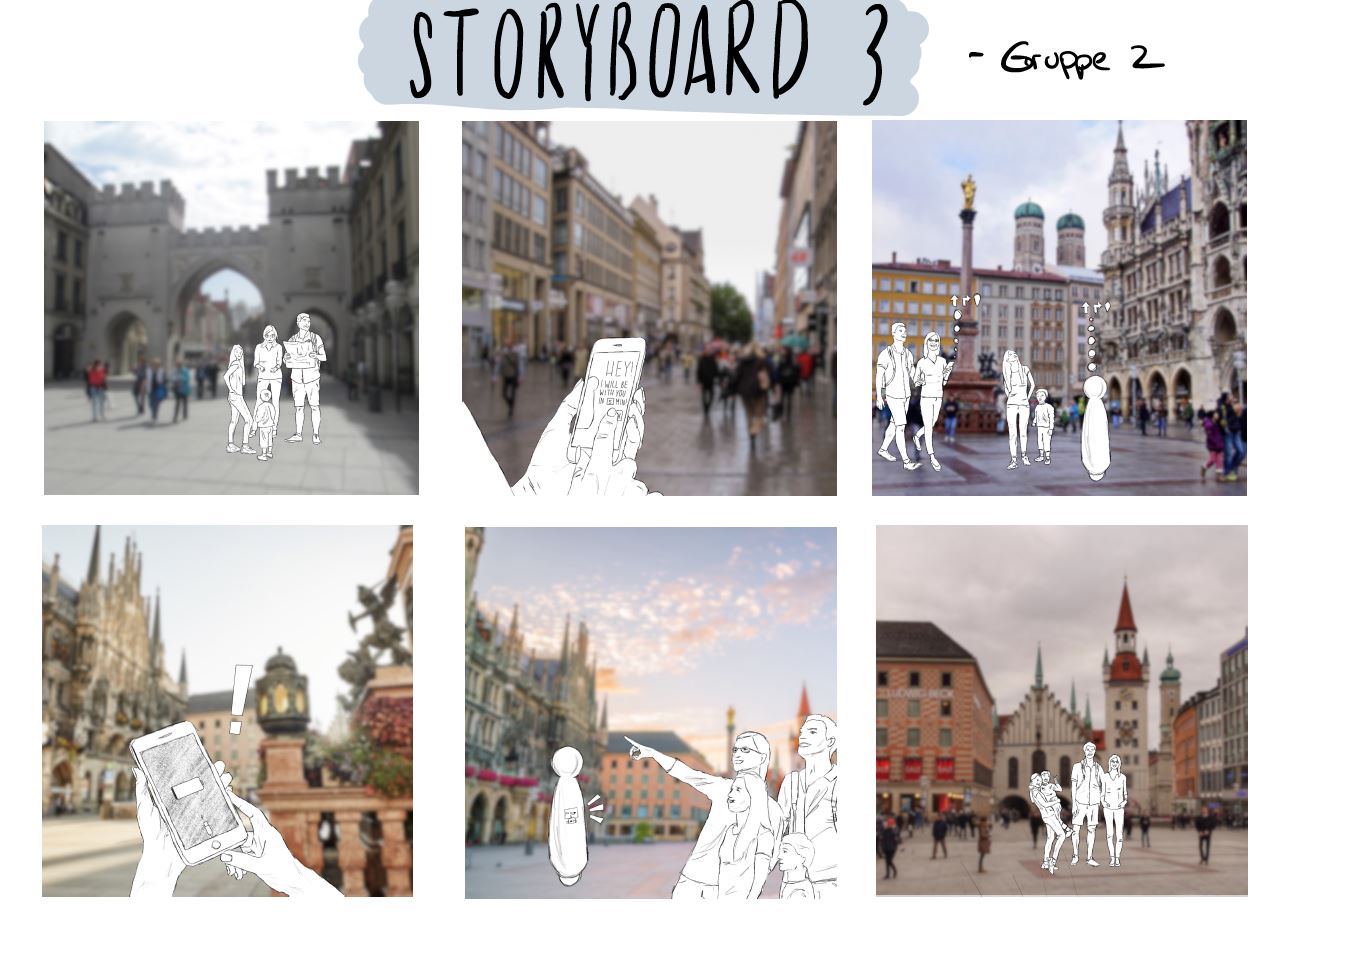
Overall, we had a look at not only the navigation, sightseeing, and certain additional features but also on how a tourist group would start their interaction with the robot and what interaction paradigm would fit such a citytour context (visual signals vs. voice vs. app remote).
Paper Prototype & Lo-Fi Models
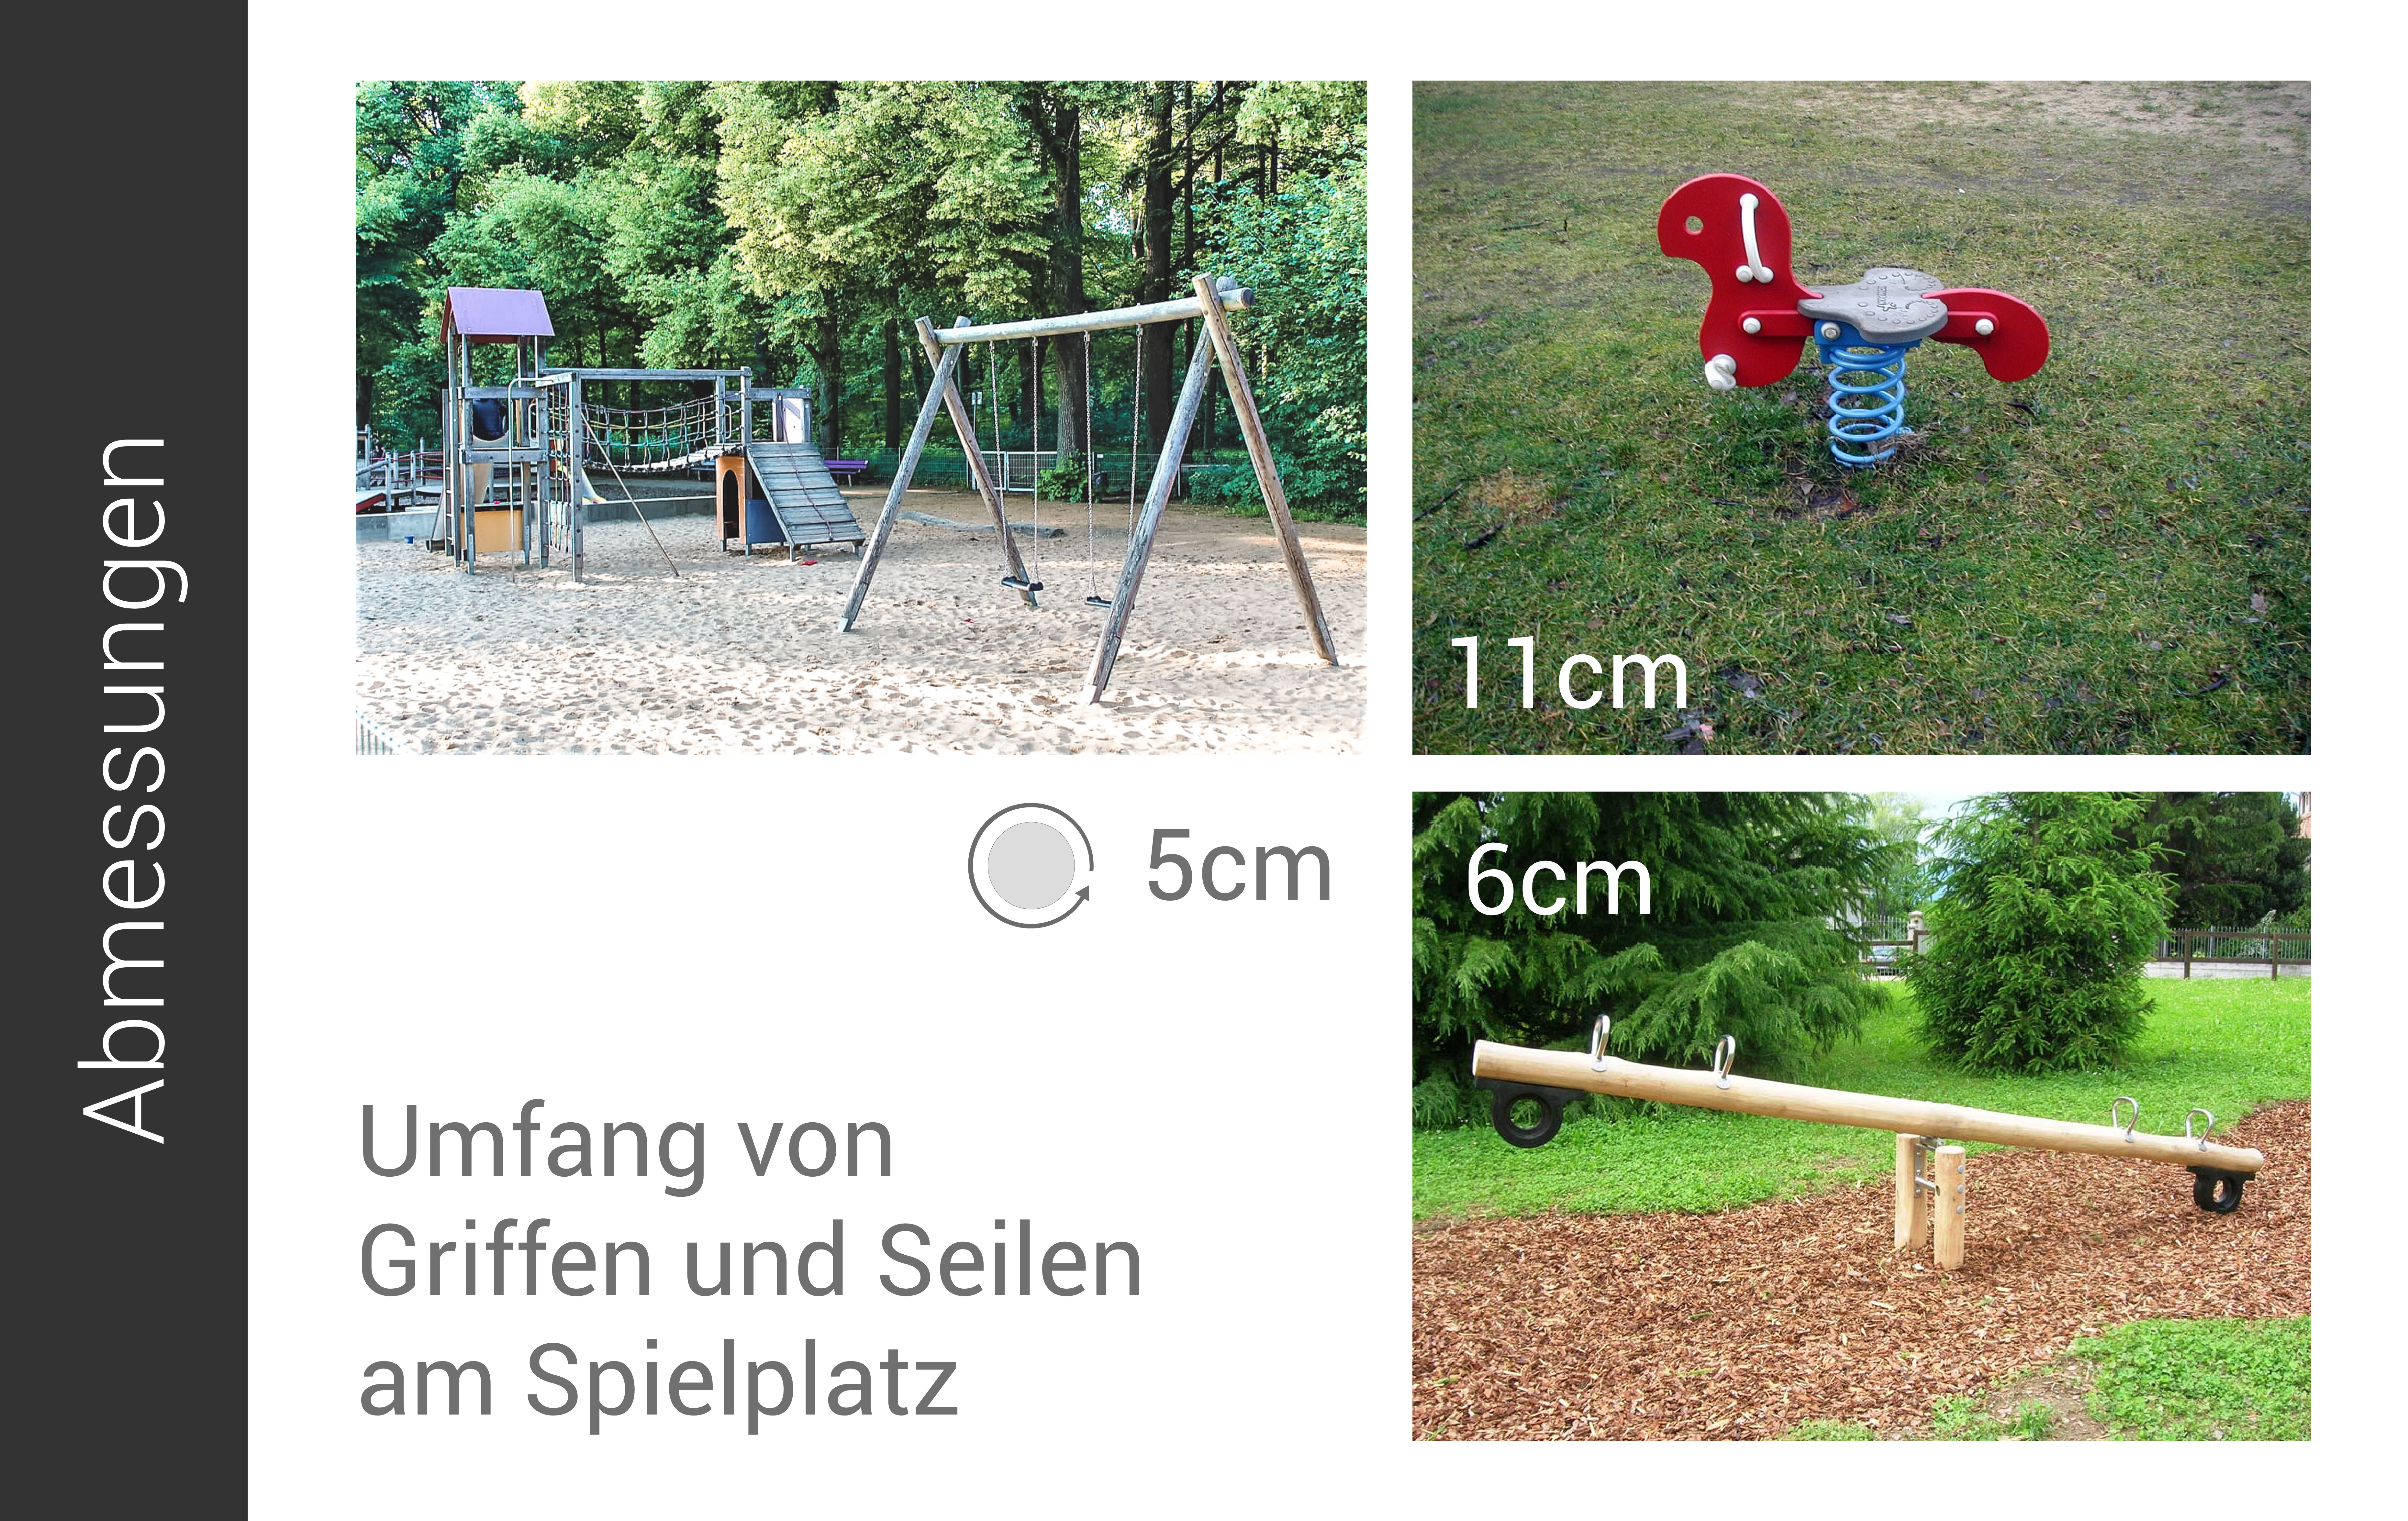
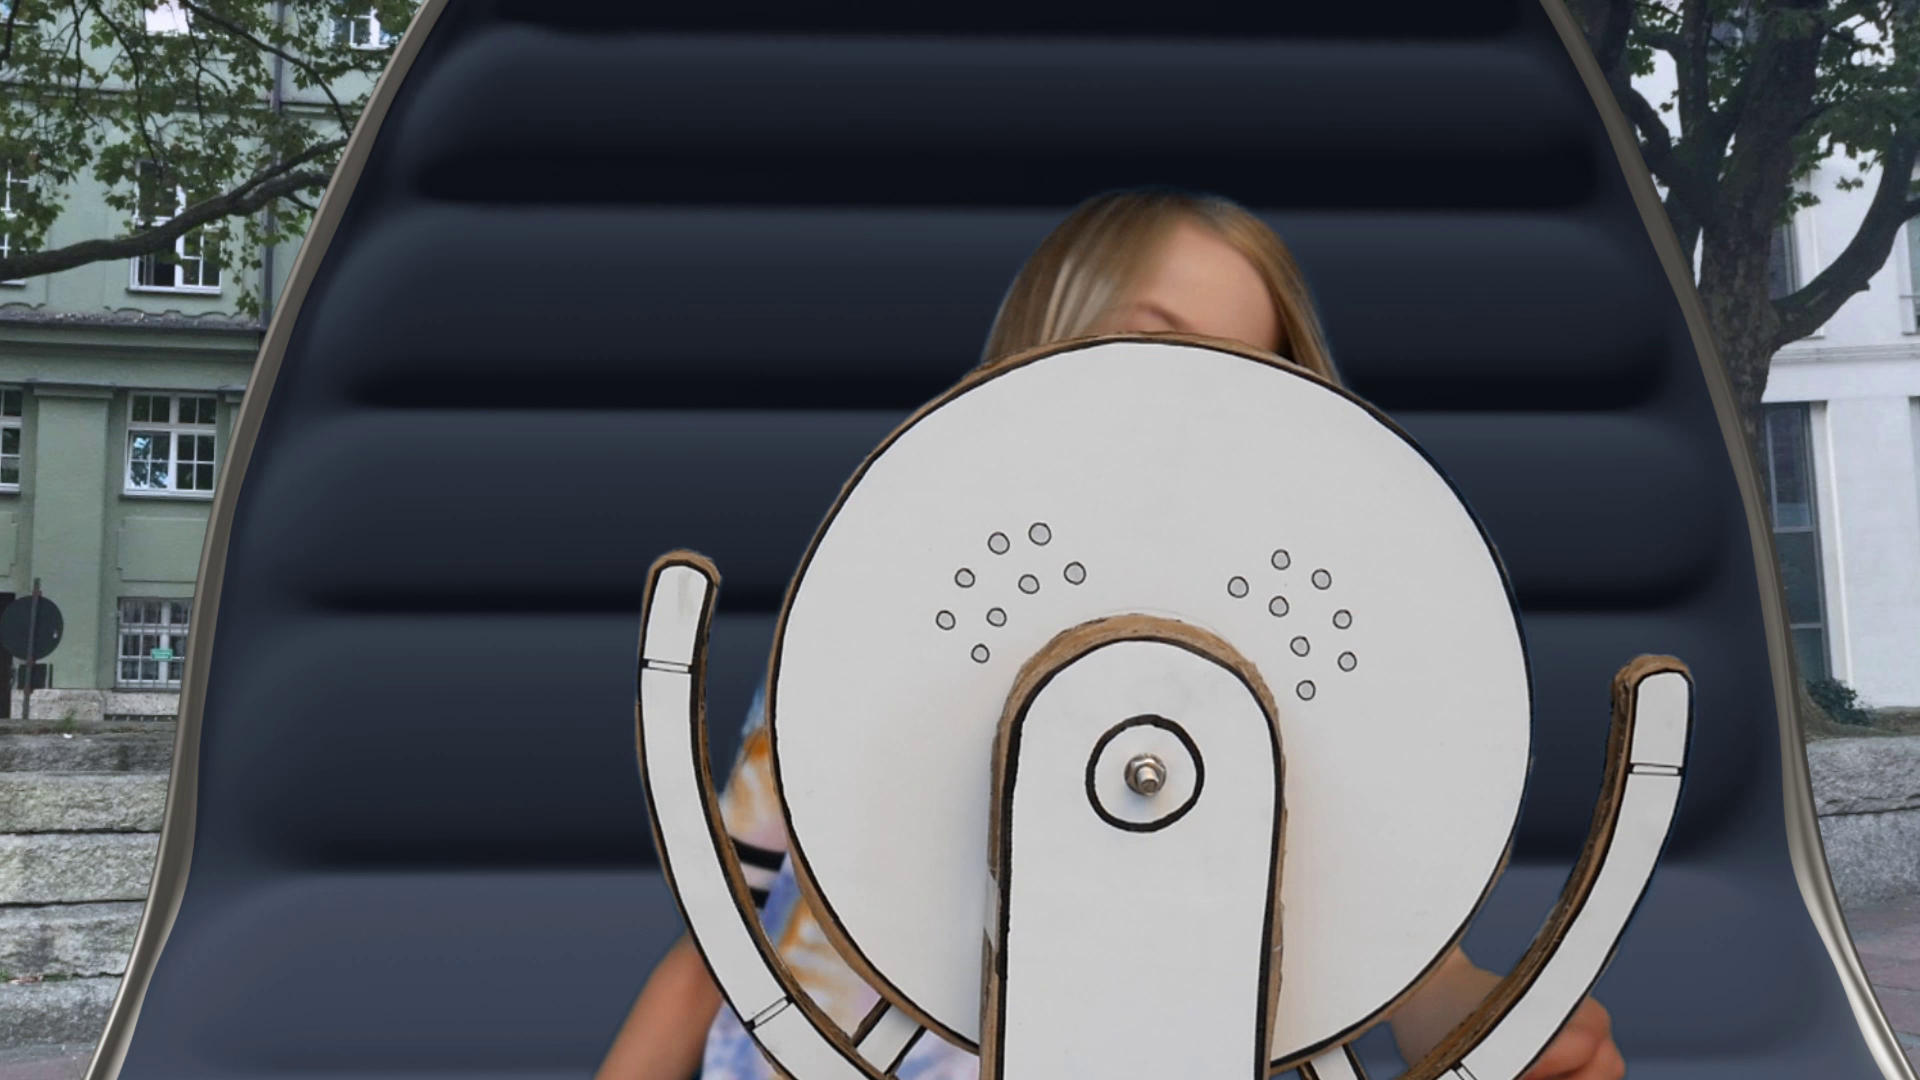
To explore the haptic interaction with the robot interface, we designed several paper prototypes and low fidelity models. They later served as a guidance for the 3D modeling of the robot in our final prototype version. The picture above shows multiple stages of the lo-fi prototyping of the steering wheel for the gamified feature for the underaged user group. The measures we used were derived from measurements taken from sights on a playground to match the ergonomic requirements of children.
Robot Concept
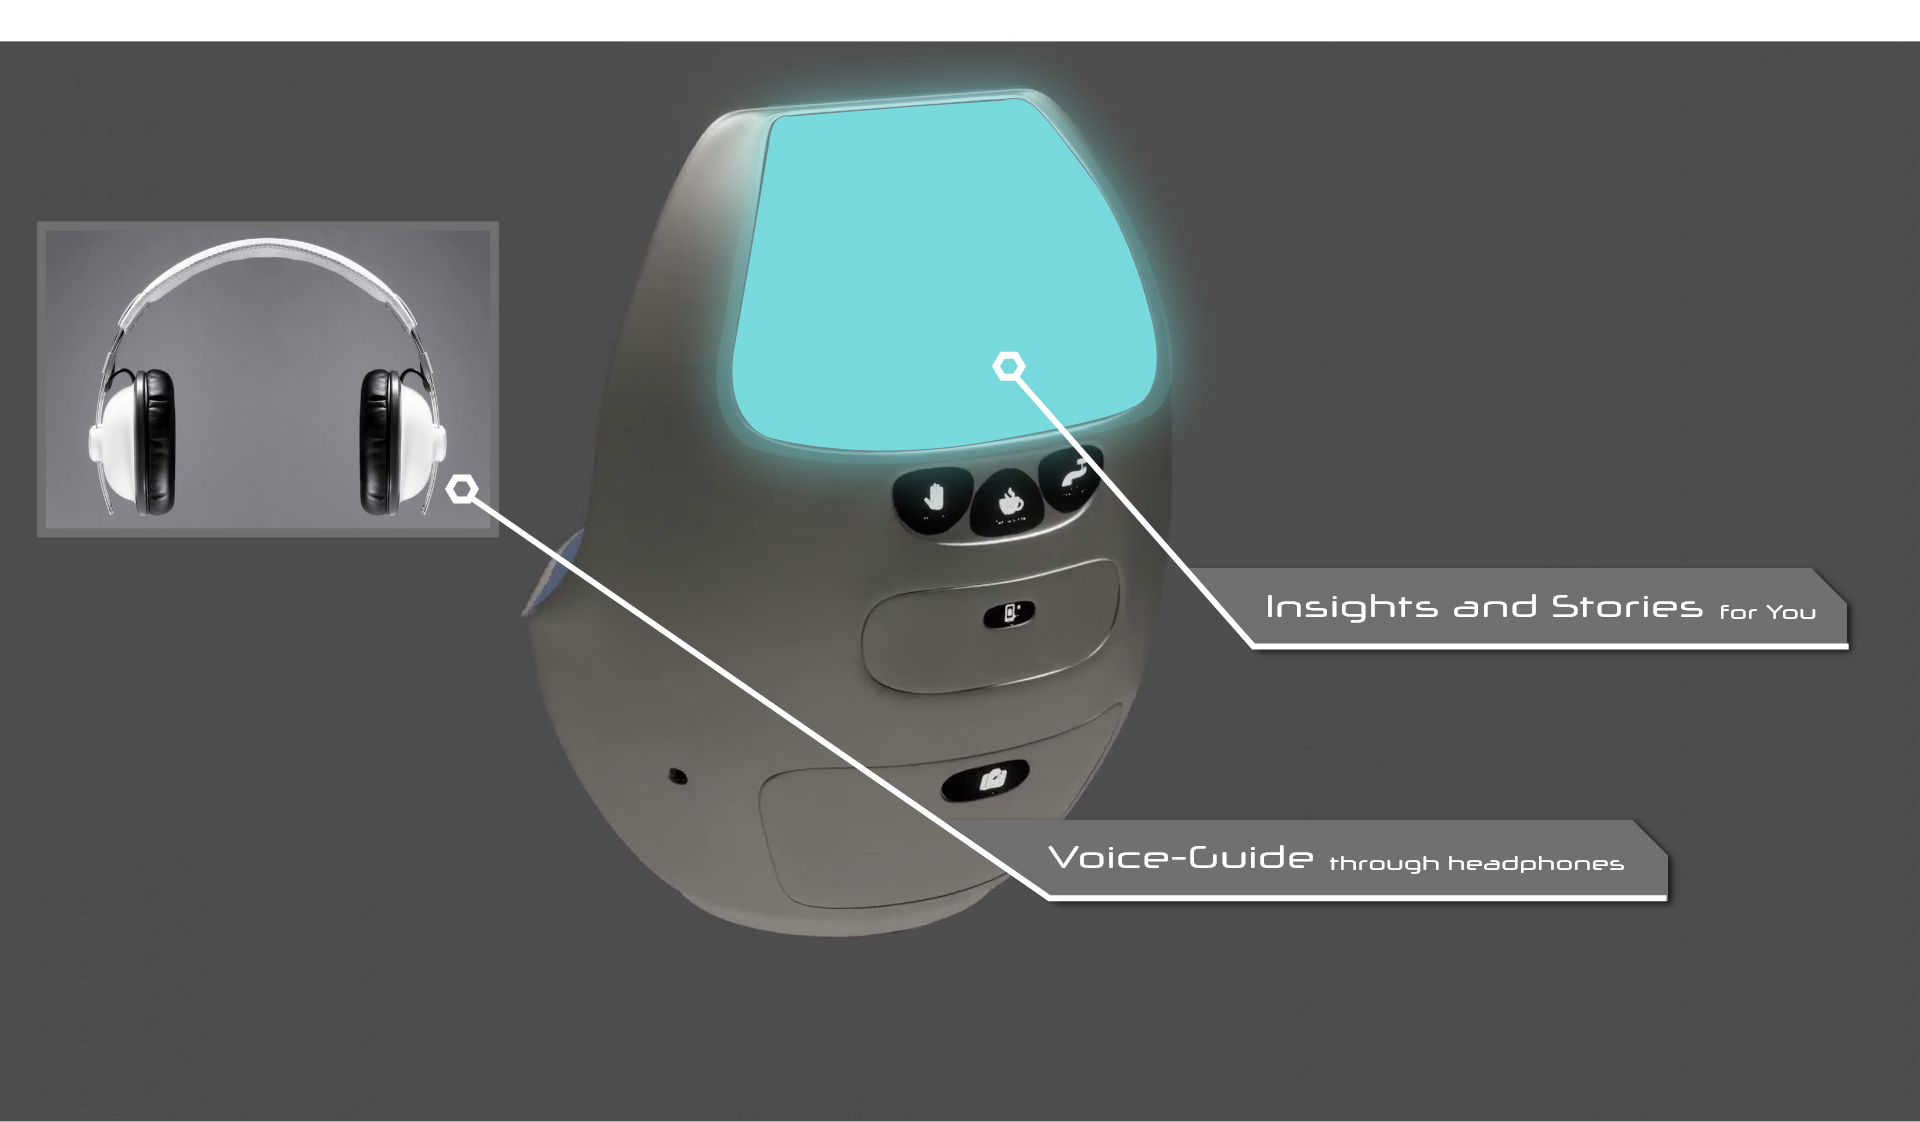
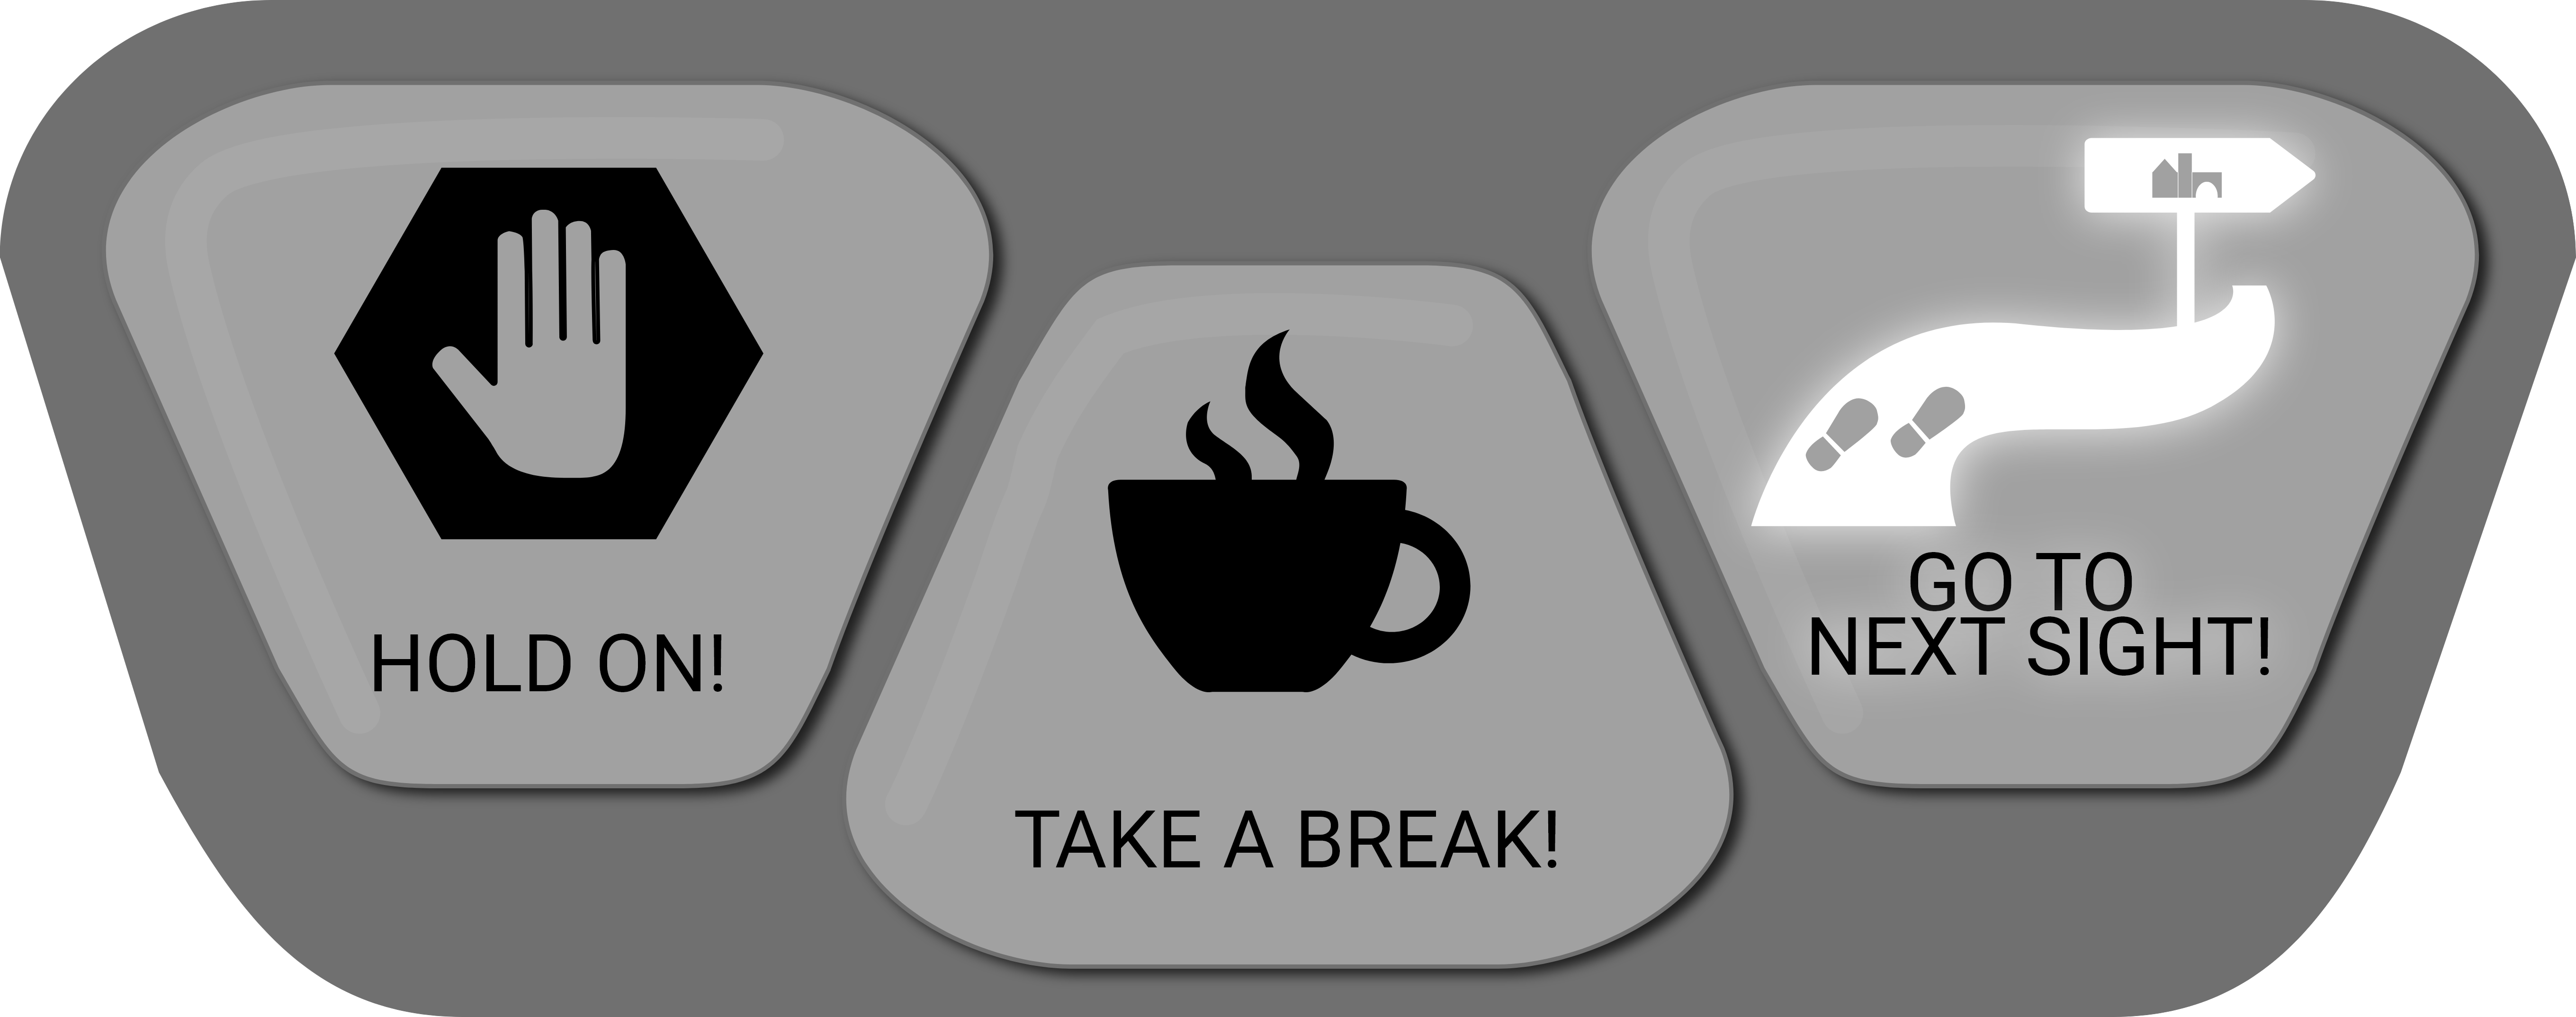
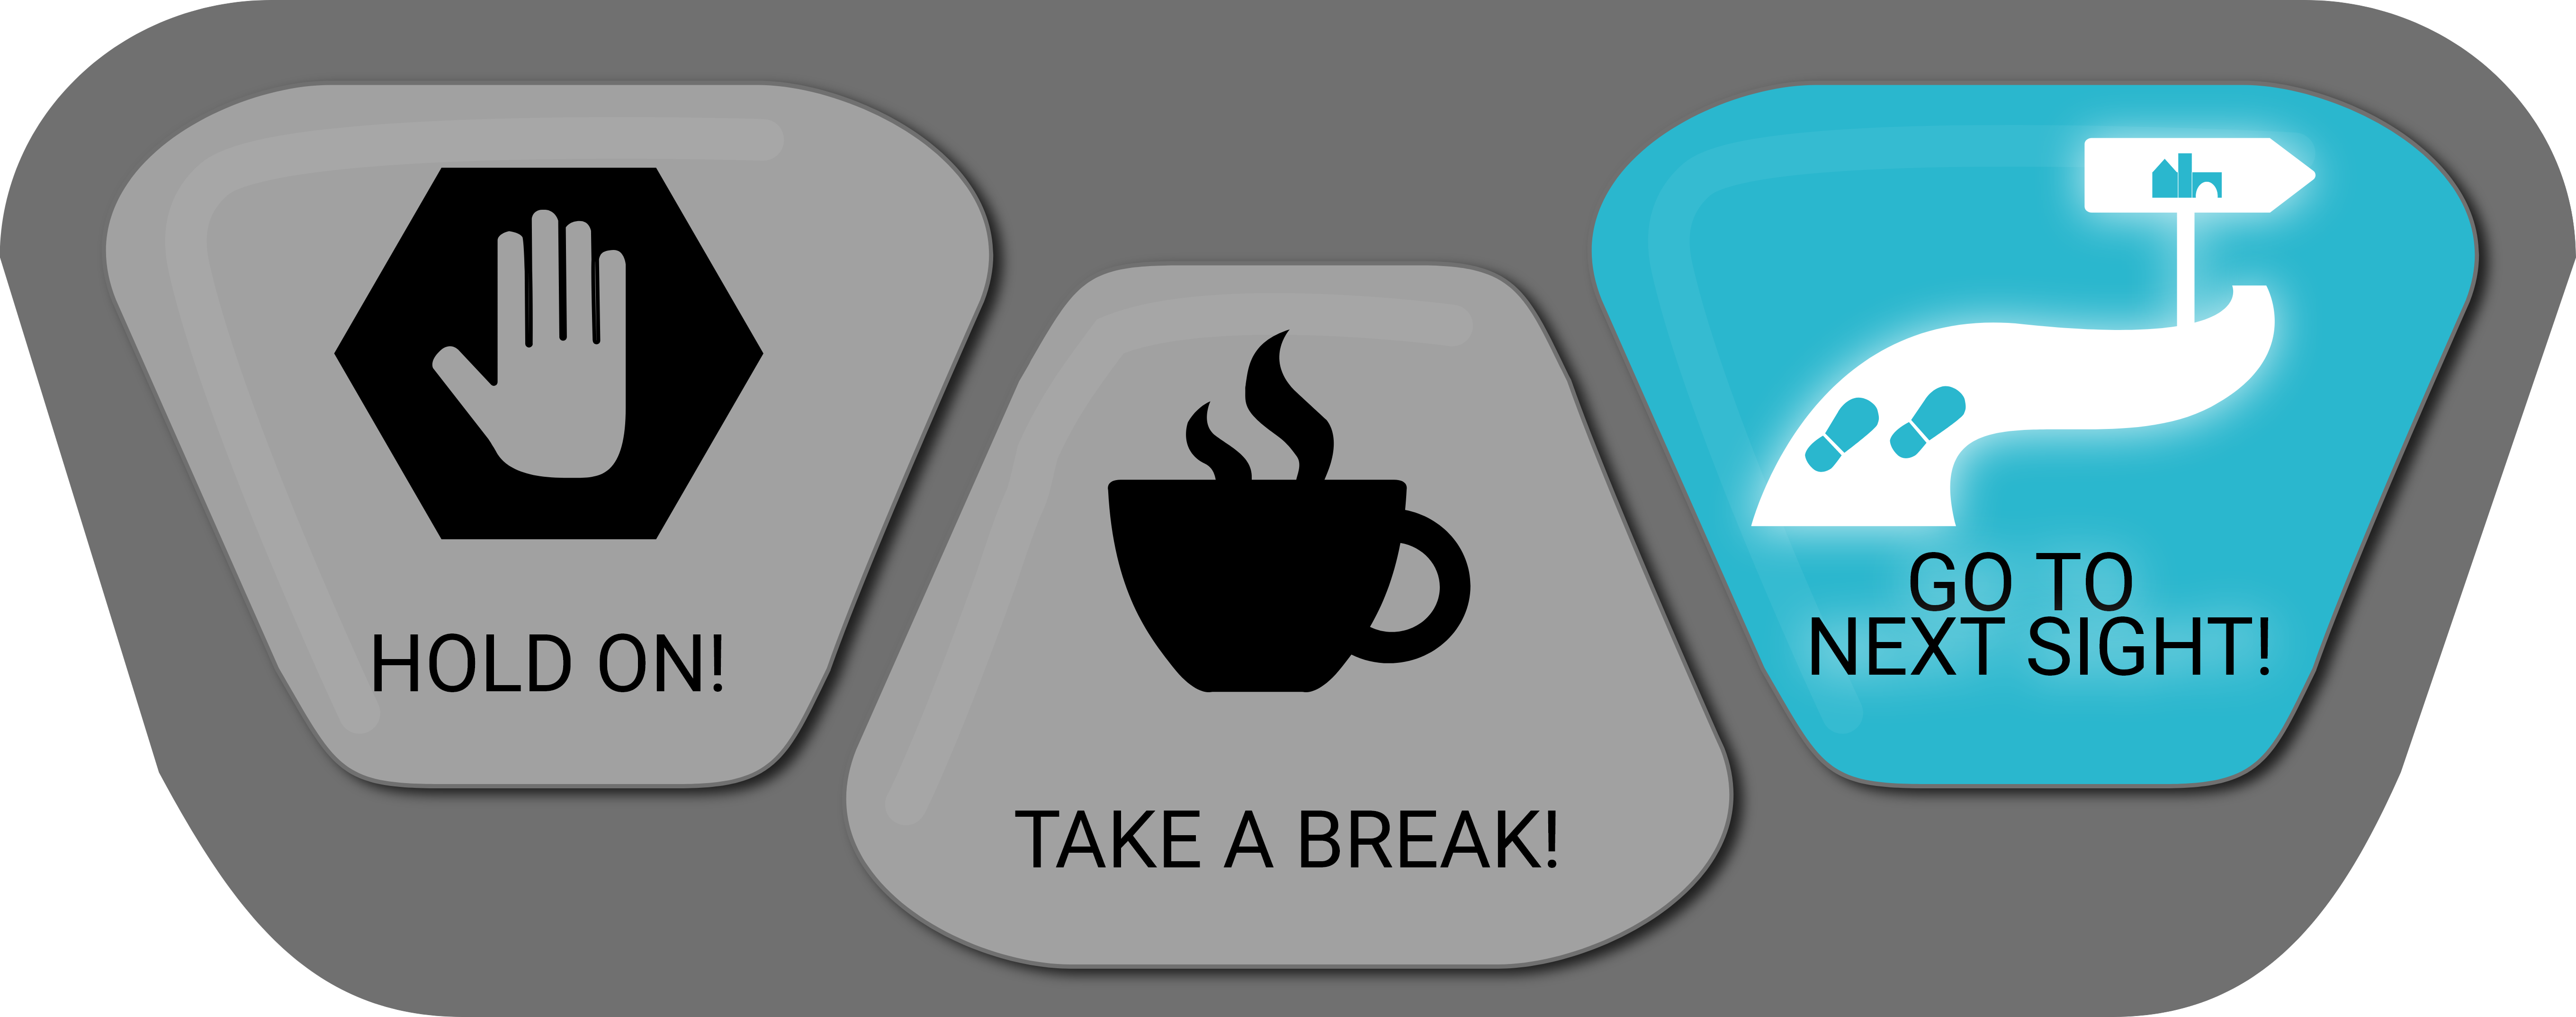
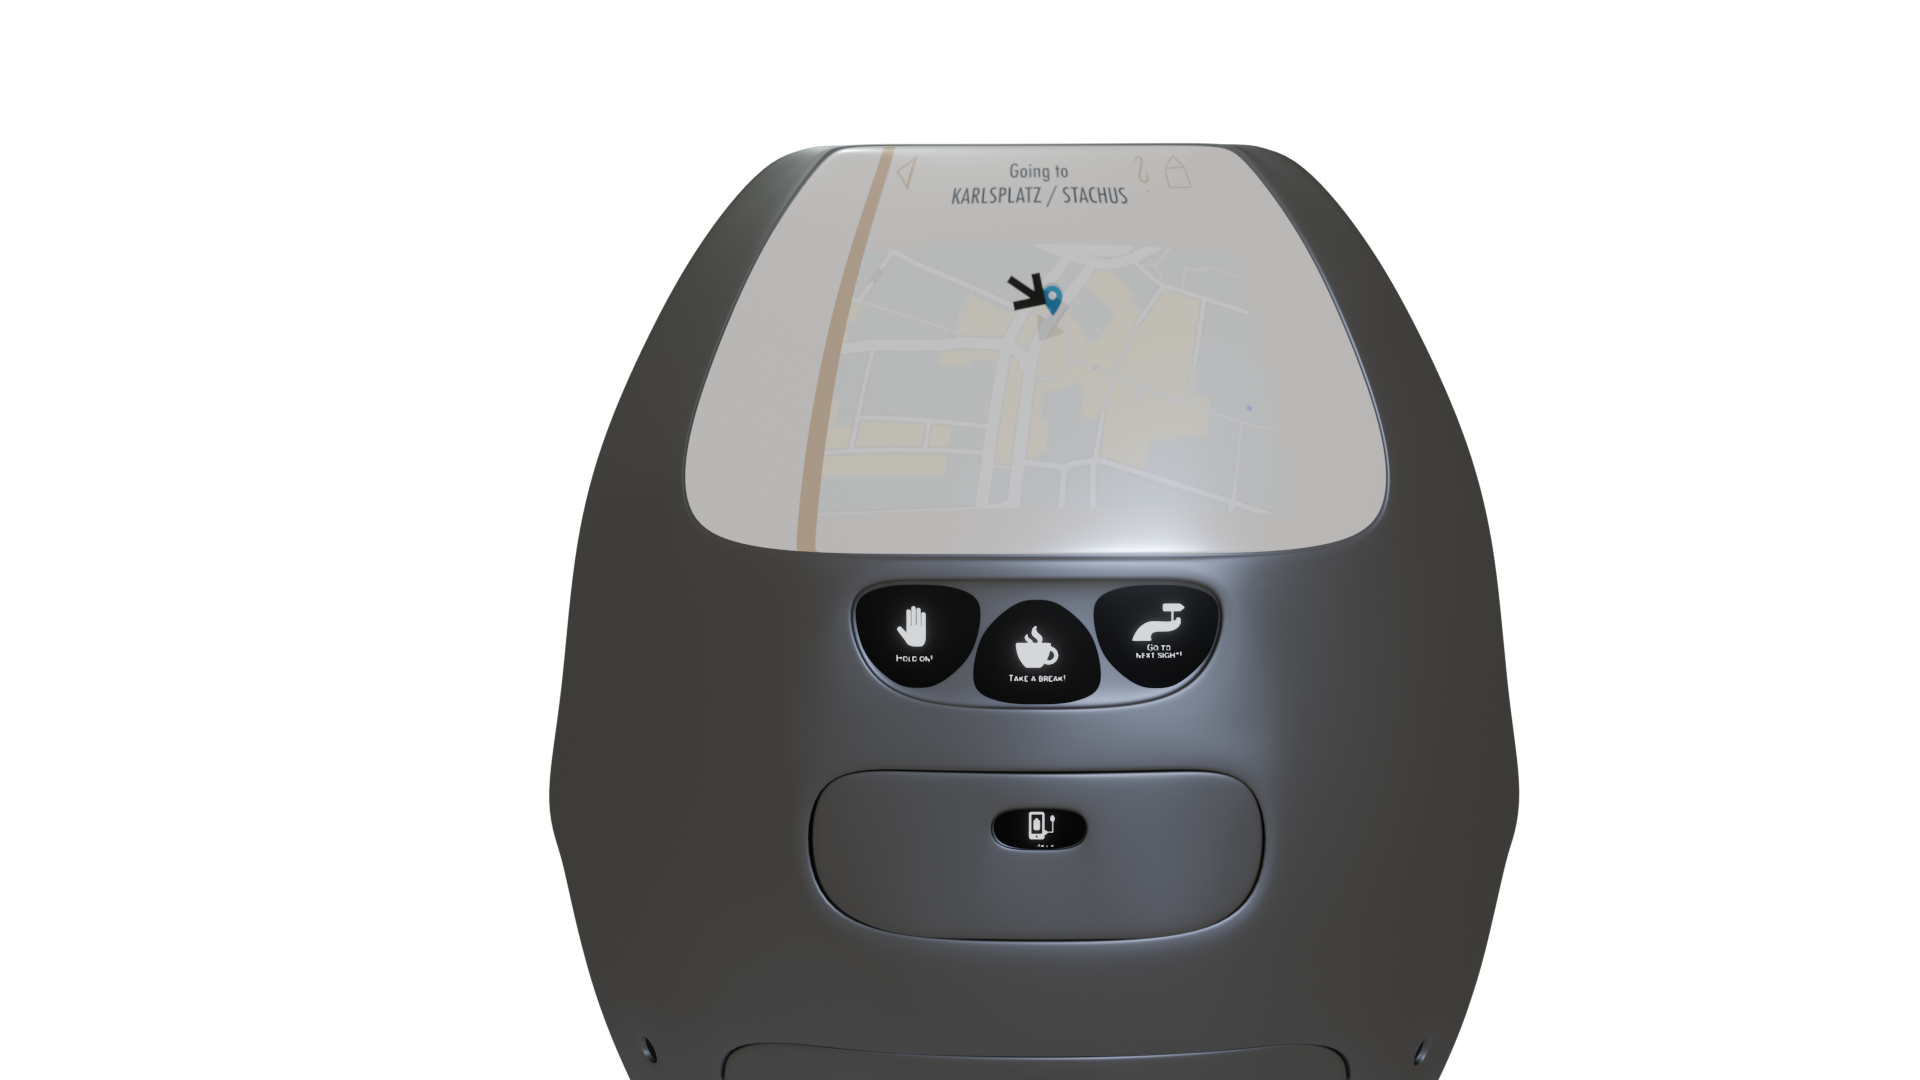
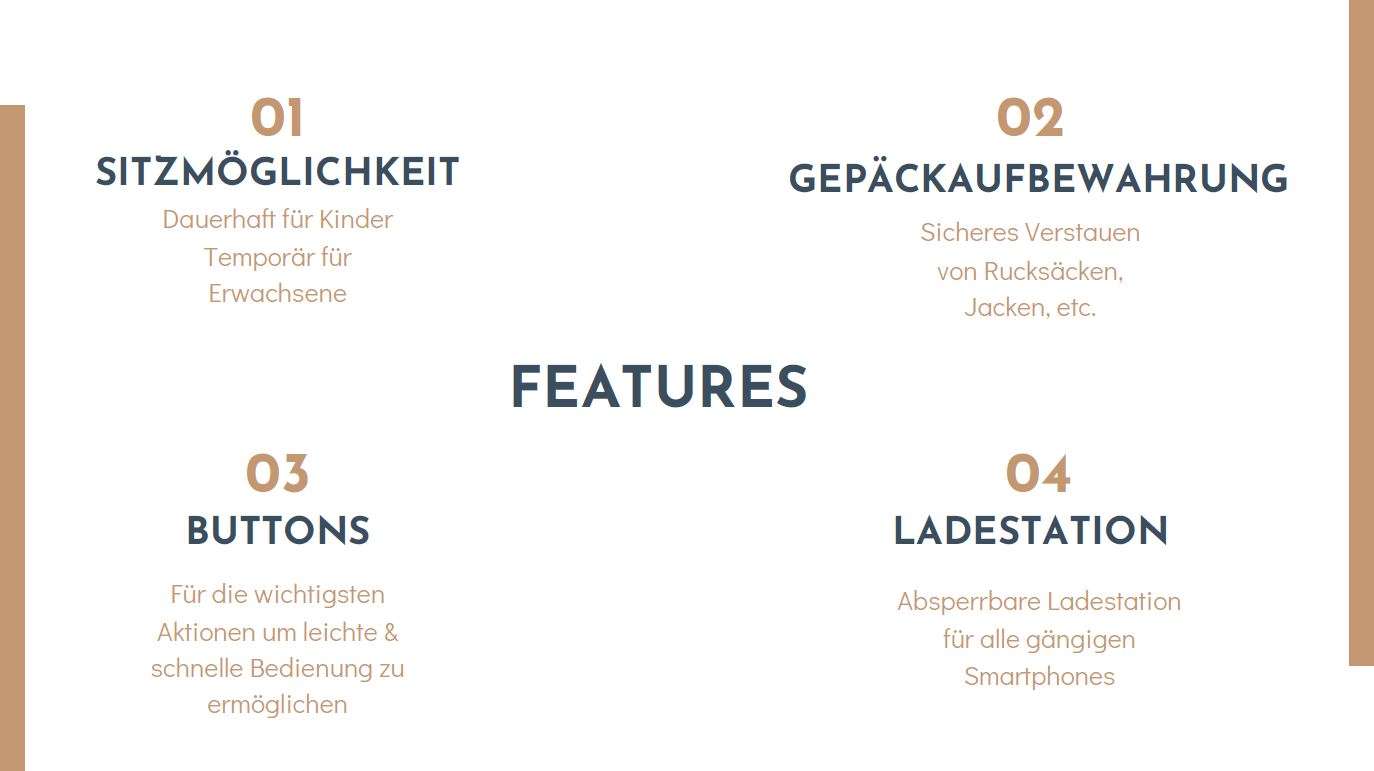
The final concept of our robot cityguide included a huge touchscreen complemented with three hand-size physical buttons offering a function to stop the robot, to take a break, and to go to the next sight.
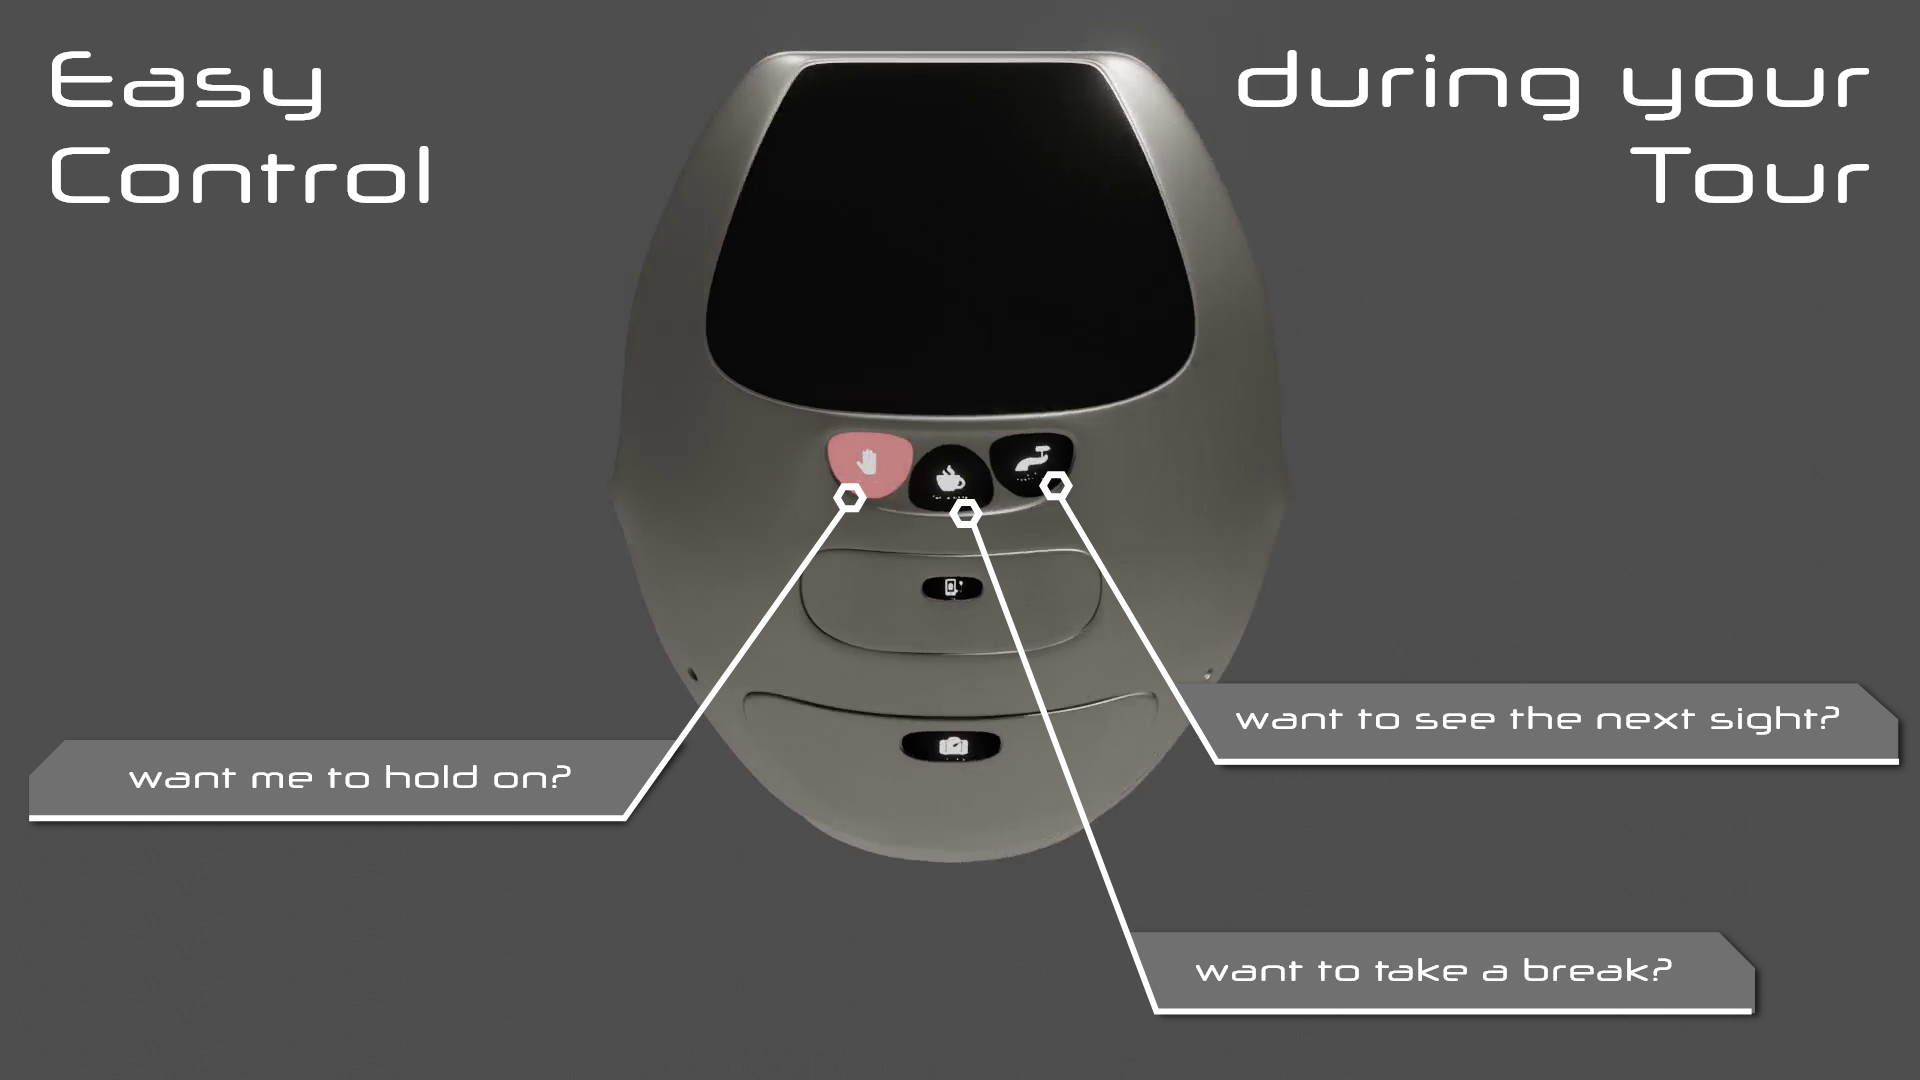
On the backside, there is a large seat that can be used to sit down during breaks or for children to join the gamified experience on the steering wheel. The steering wheel is extendible by pushing a button on the lower end of the seat.
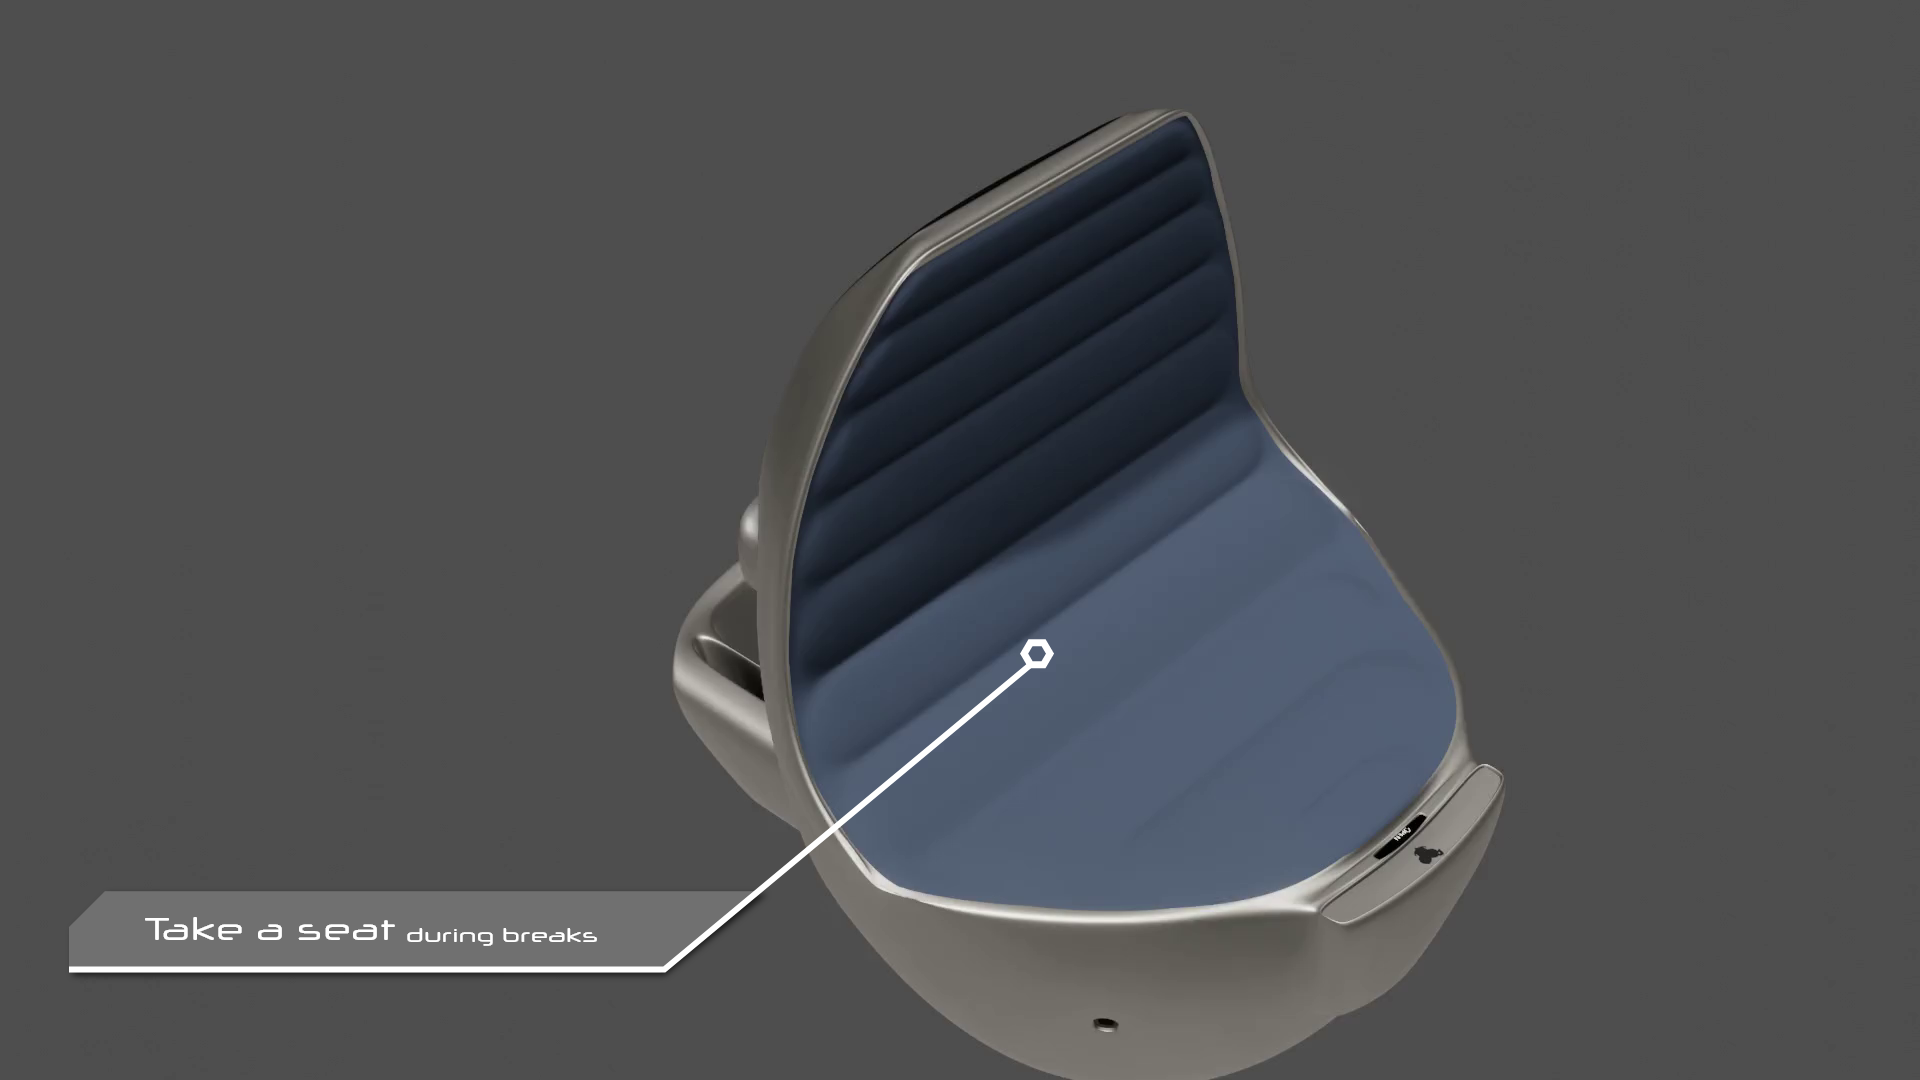
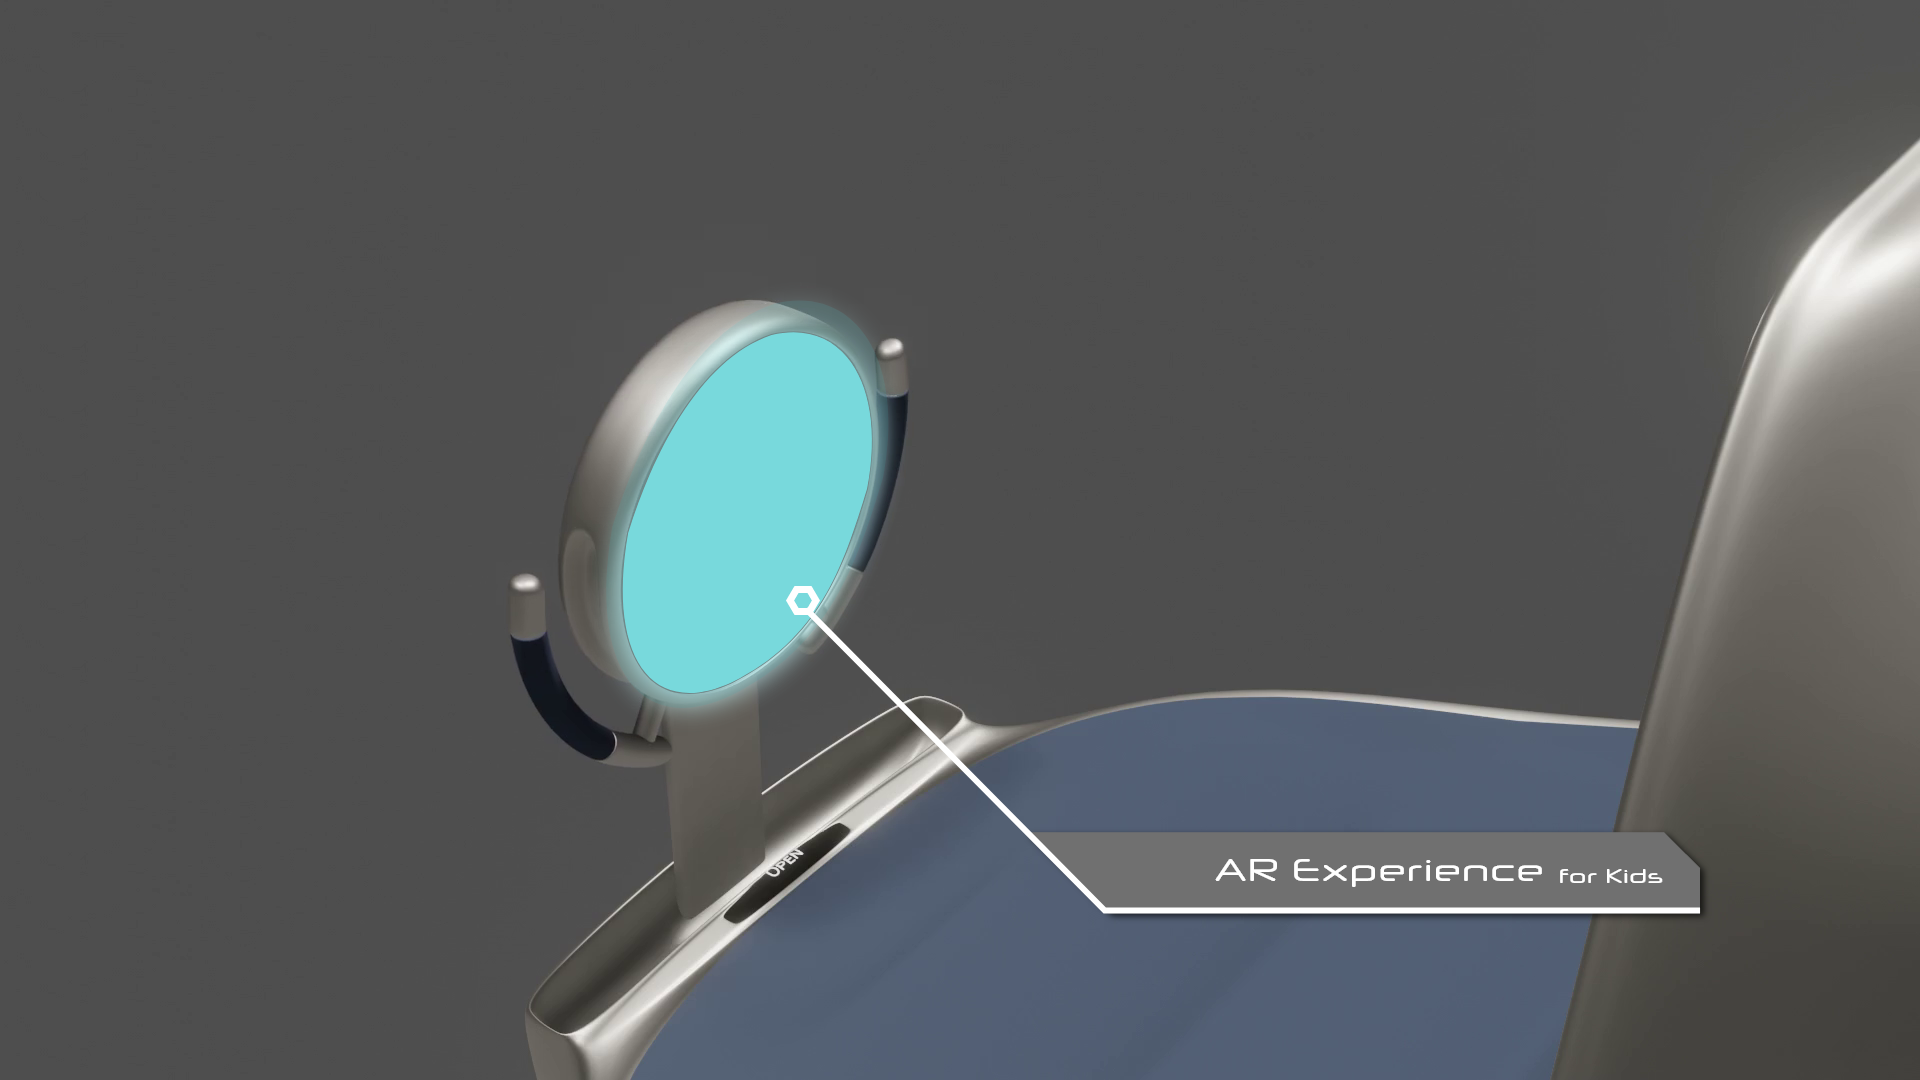
During the tour, the screen shows visual insights and navigation hints by showing a map and indicators. The robot includes headphones but can also be used with privat bluetooth headphones. The voice guide presents the information on the screen auditory so that the tour group can enjoy the sightseeing without staring at the screen.
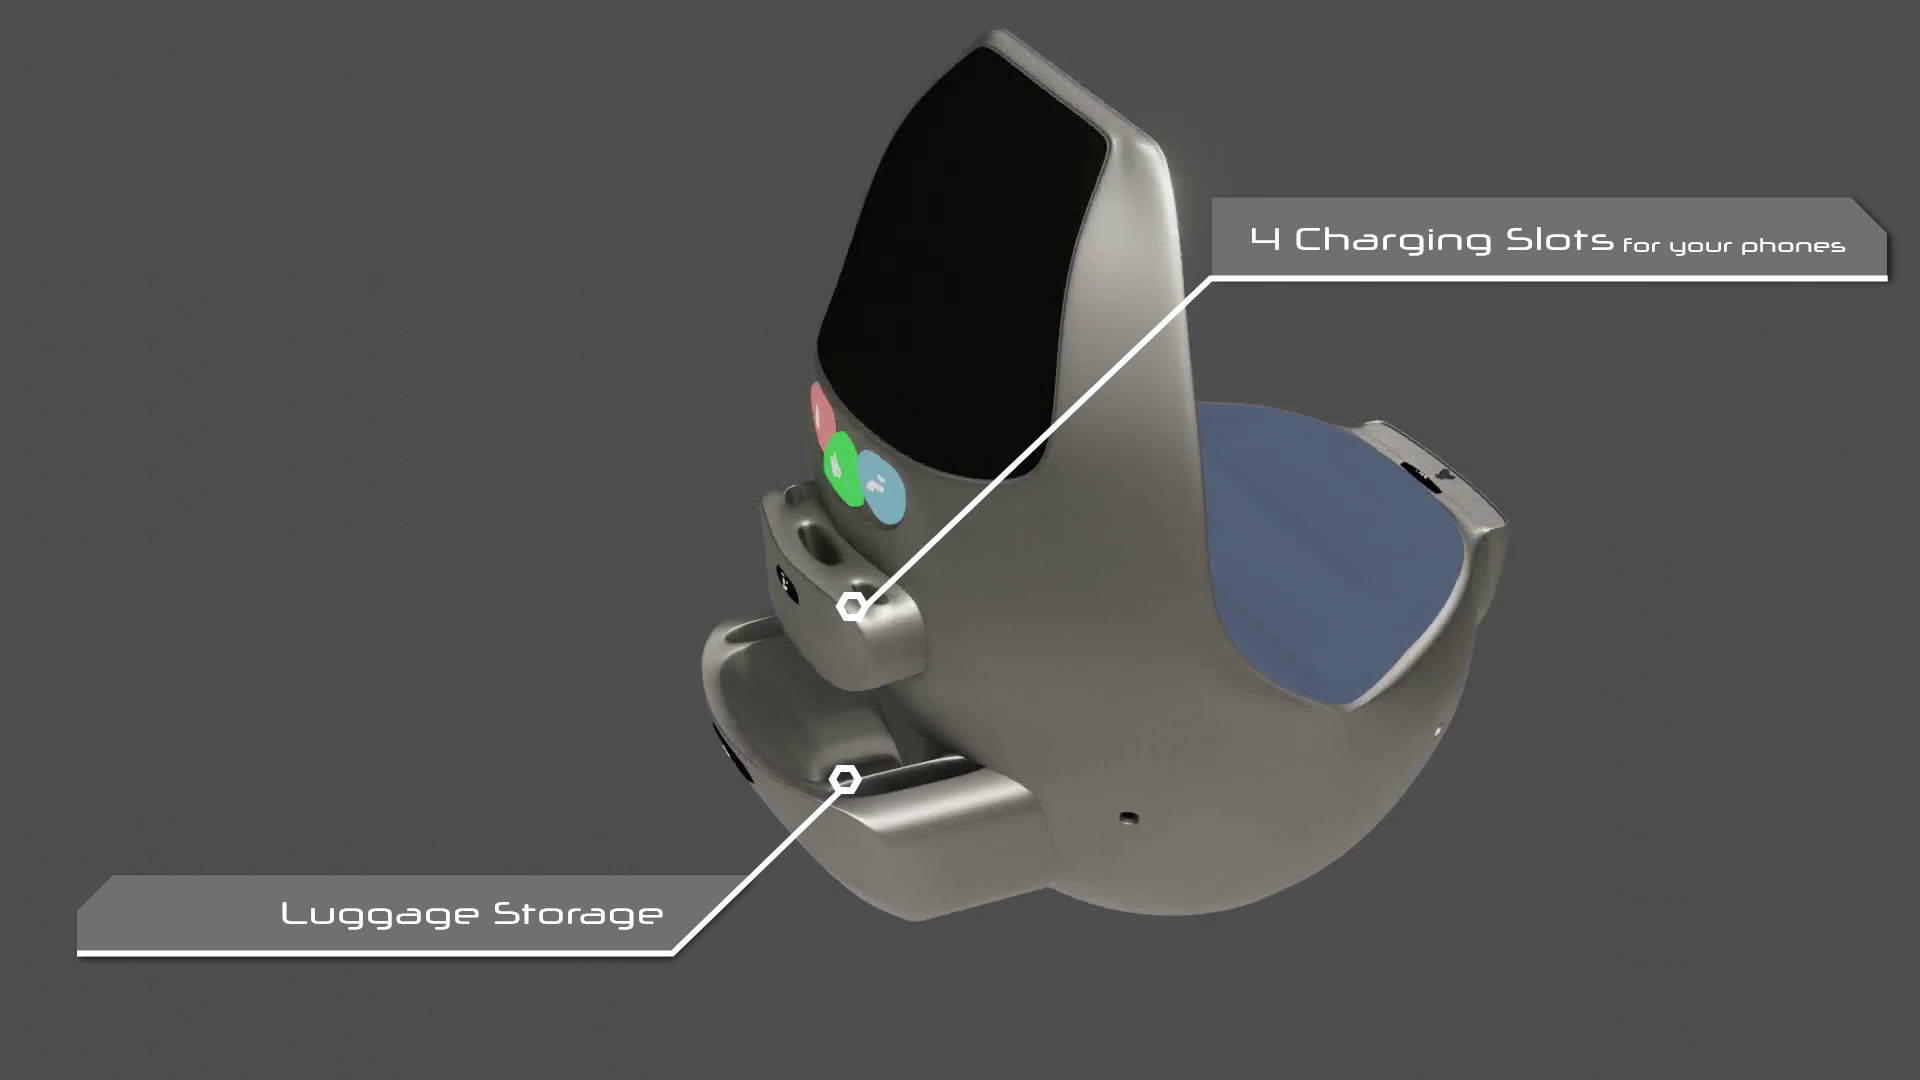
As additional features, the robot contains two shelves. A small shelf directly under the screen with four charging slots for phones and one bigger shelf to store luggage.
Robot UI
As already mentioned, the large touchscreen on the front shows visual information crucial for navigating in the city and complements the auditory information of the sightseeing. It is also used to communicate with the tourist group and to advertise the citytour when not in use.
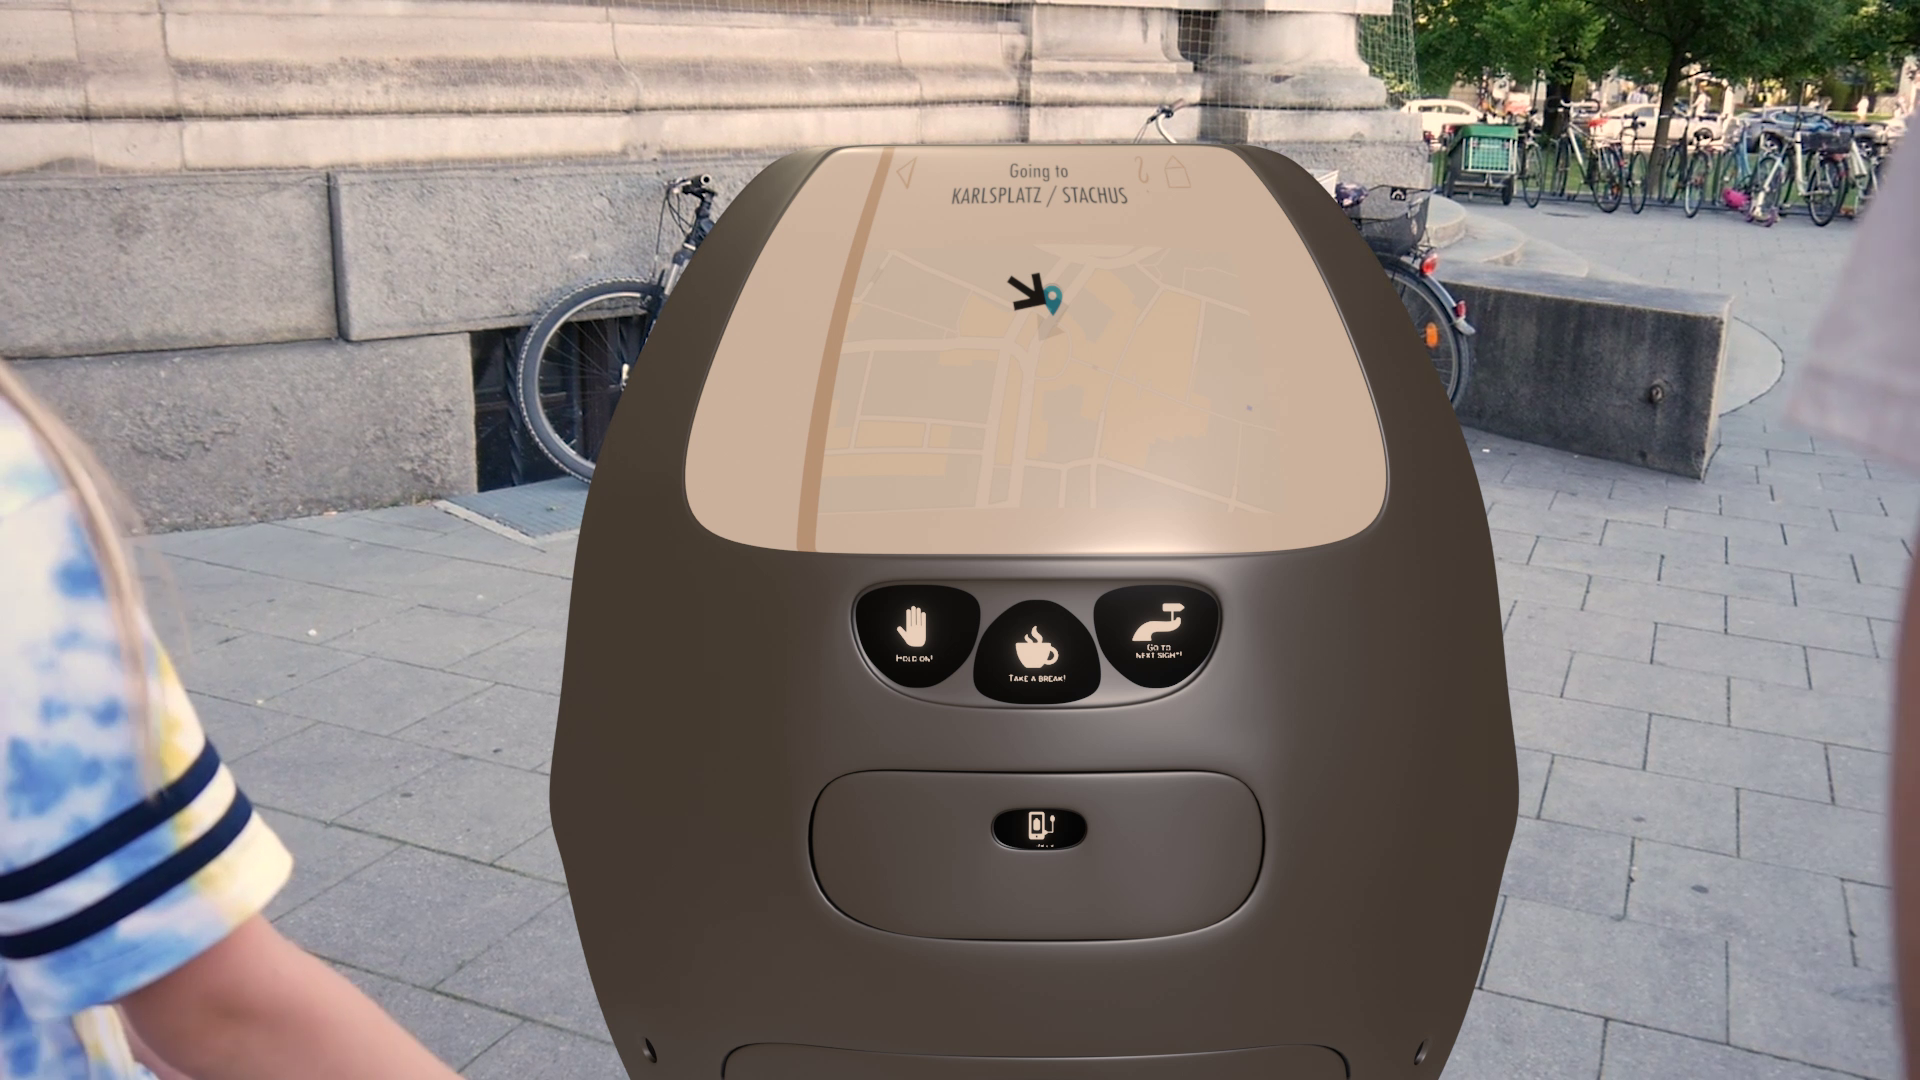
The UI on the screen and the physical buttons (below the screen, on the shelves, and on the lower end of the seat) use a warm and easy to understand visual language with big icons and short text. The GUI color theme is based on the colors we explored in our munich moodboard.
Game Design
The gamified part of the robot tourguide takes place on the steering wheel. It includes a screen in the center, a tangible interface with the two grips left and right, as well as a small camera on the back for the AR features. The whole experience is structured based on the sightseeing spots. Each sightseeing spot represents one part of the interactive experience, that the children can join casually. Each part features a story mode and a game mode.
The story mode presents the current sight and combines information with narration. It guides the child with AR elements that overlap with the physical sight to narrate a certain legend or to teach the child about interesting facts regarding that place. The aim of this mode is to let the child explore the sight in a playful way and to awaken their inner explorer.
The game mode invites the child to search for pretzel coins that are hidden around the sight. The AR pretzel coins can be found by panning and tilting the steering wheel with the handles. The screen serves as a sight pipe. When the child aims and holds on a target with the steering wheel screen it will be collected. When they've collected all hidden coins at the current sight, they win the game for this sightseeing stop.
Preproduction, Production, Postproduction
One part of our final deliverable is a video prototype of our concept. For the production we prepared various equipment including cameras, a greenscreen, props, a lo-fi prototype of the final steering wheel design, a shotlist, and a production plan. Our video prototype starred a family of three: Two of our group were casted as parents and we asked a befriended couple's daughter to act as the daugther of the fictional family.
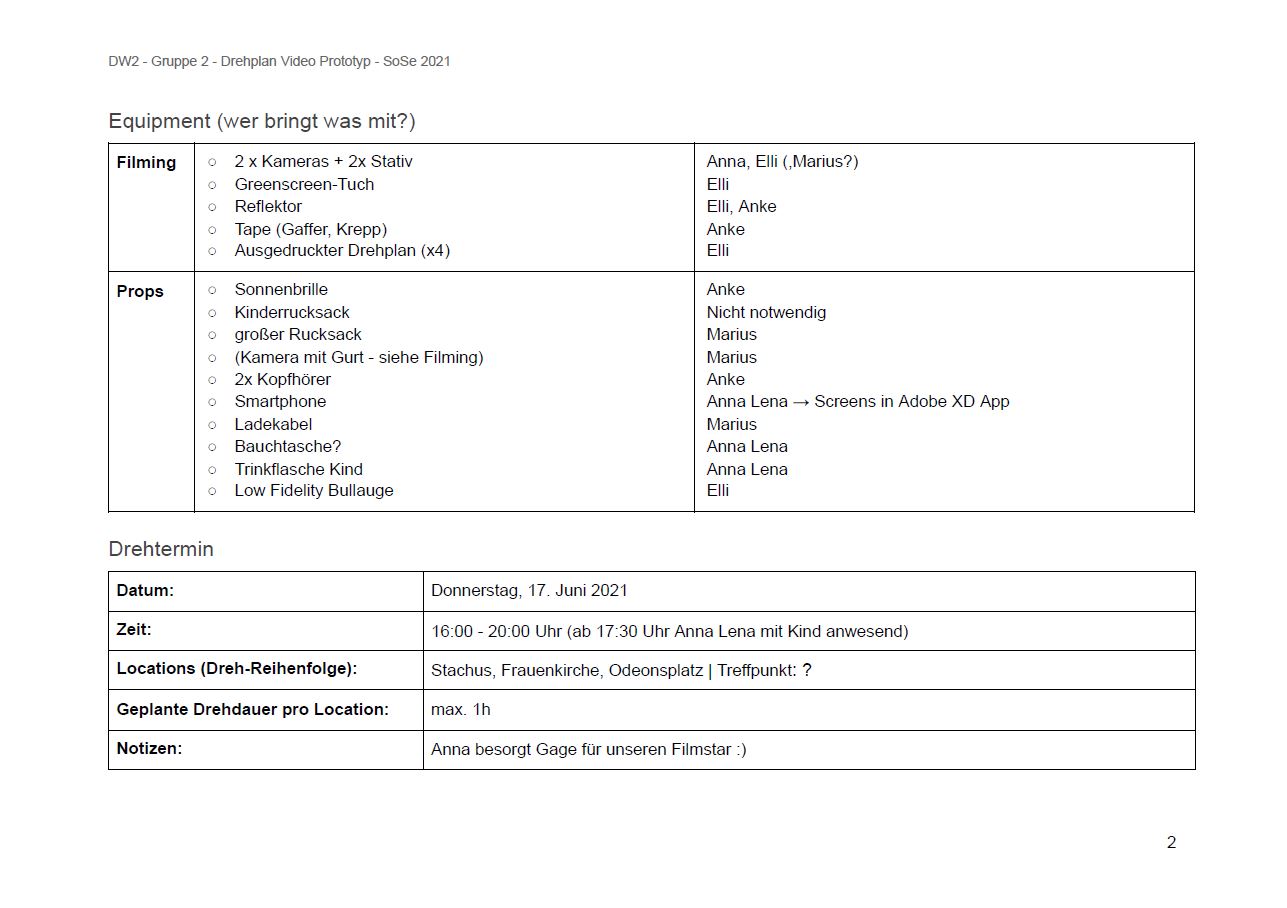
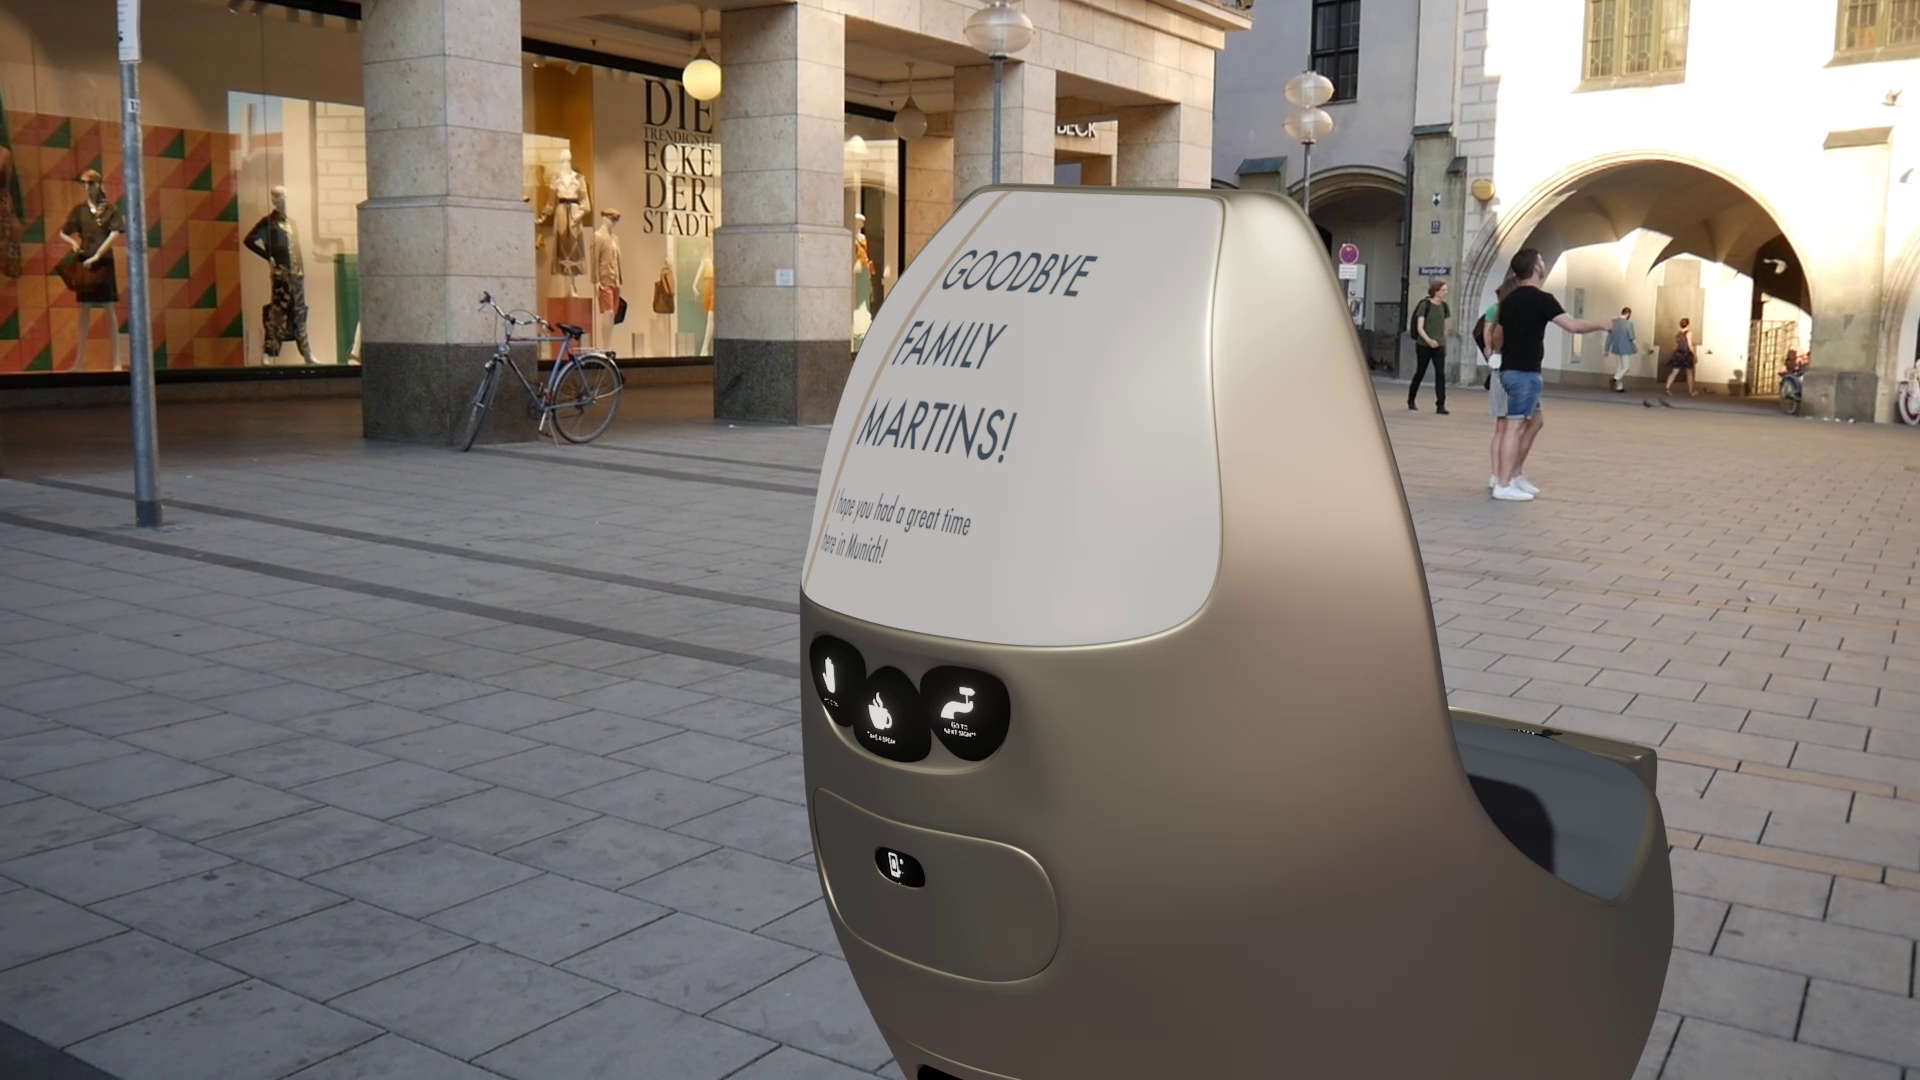
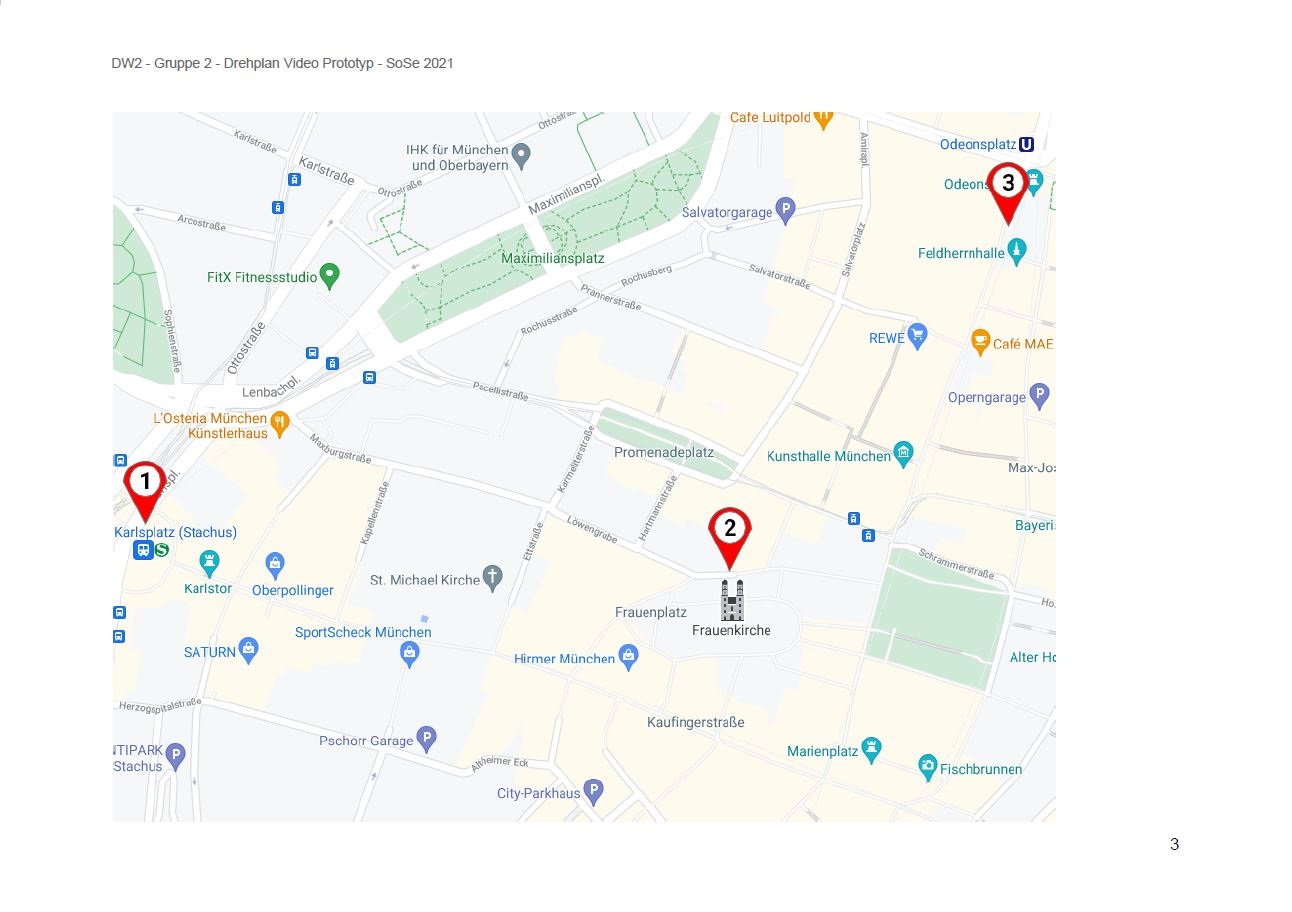
The production took place one day at three preselected locations in munich. At Stachus, we showcased the first encounter with the robot, the navigation feature, and the two add-on features (luggage, charging). At the big church Frauenkirche we presented the audio guide and the game experience. Finally at the last location (planned: Odeonsplatz, changed to: Marienplatz), we produced a final scene with the group taking a break and the end of the citytour.
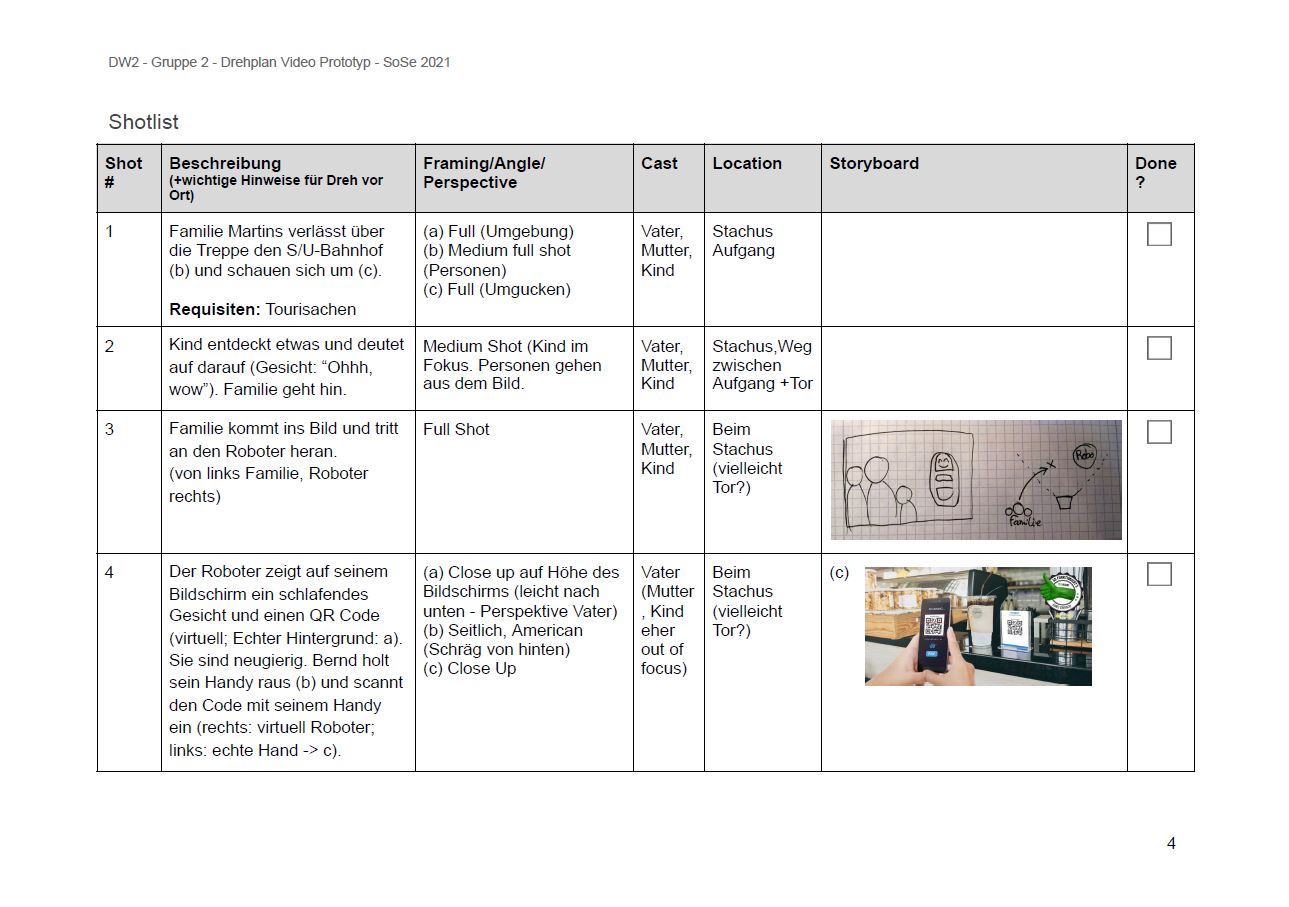
The robot model was constructed as an animated 3D model in Blender with UI elements created with Adobe XD. The animated model of the robot and the video footage were combined using AfterEffects and partly greenscreen. The final video was edited using Premiere Pro.
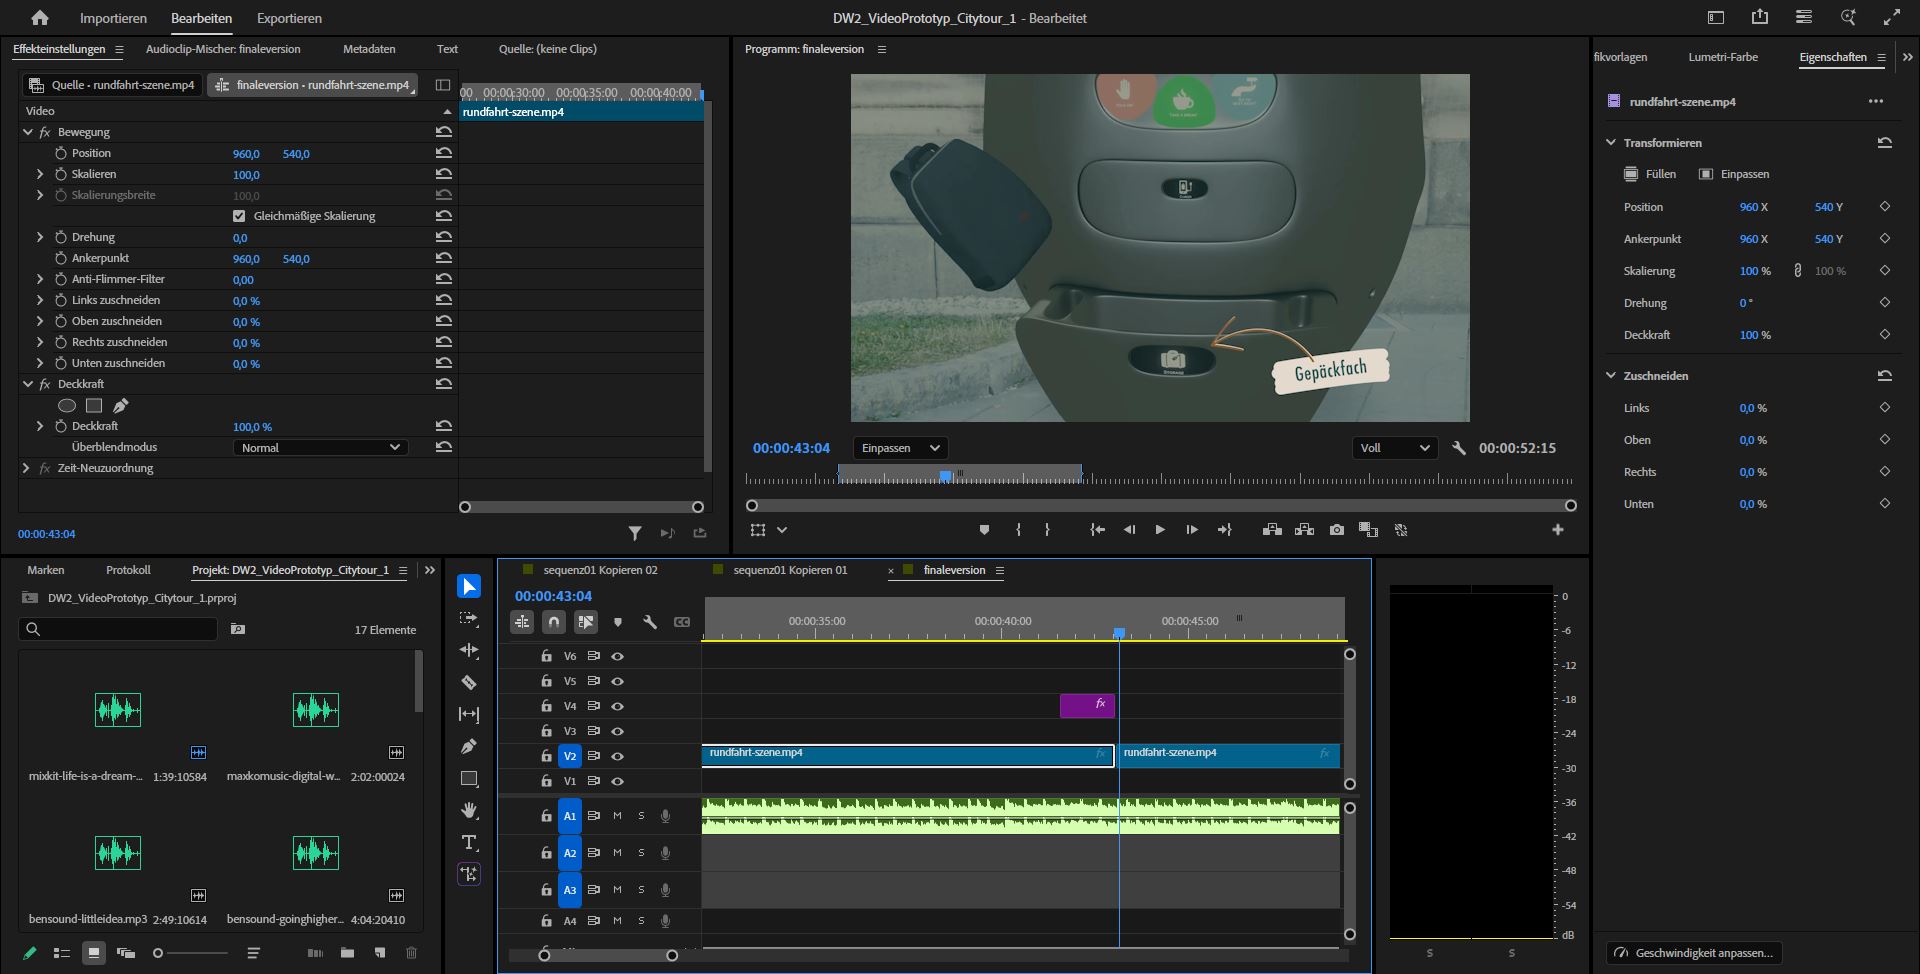
Video Prototype
The final video prototype shows the fictional family Martin that arrives a the Stachus station and wants to take a tour with our robot cityguide. After the mother scanning the QR Code on the screen, the father stores his backpack in the luggage shelf and puts his phone in the charging shelf. The robot navigates them to the sight Frauenkirche, where the parents are looking at the church while listening to the audio guide and their daughter following the story mode and playing the game mode. The story mode features information about the towers of the church and the famous legend of the devil's footprint in the entrance area of the church. In the game mode, she collects flying pretzels around the church while sitting on the seat. The last scenes show the family taking a break after pushing the robot's "take a break" button and the robot saying goodbye after the final sight.
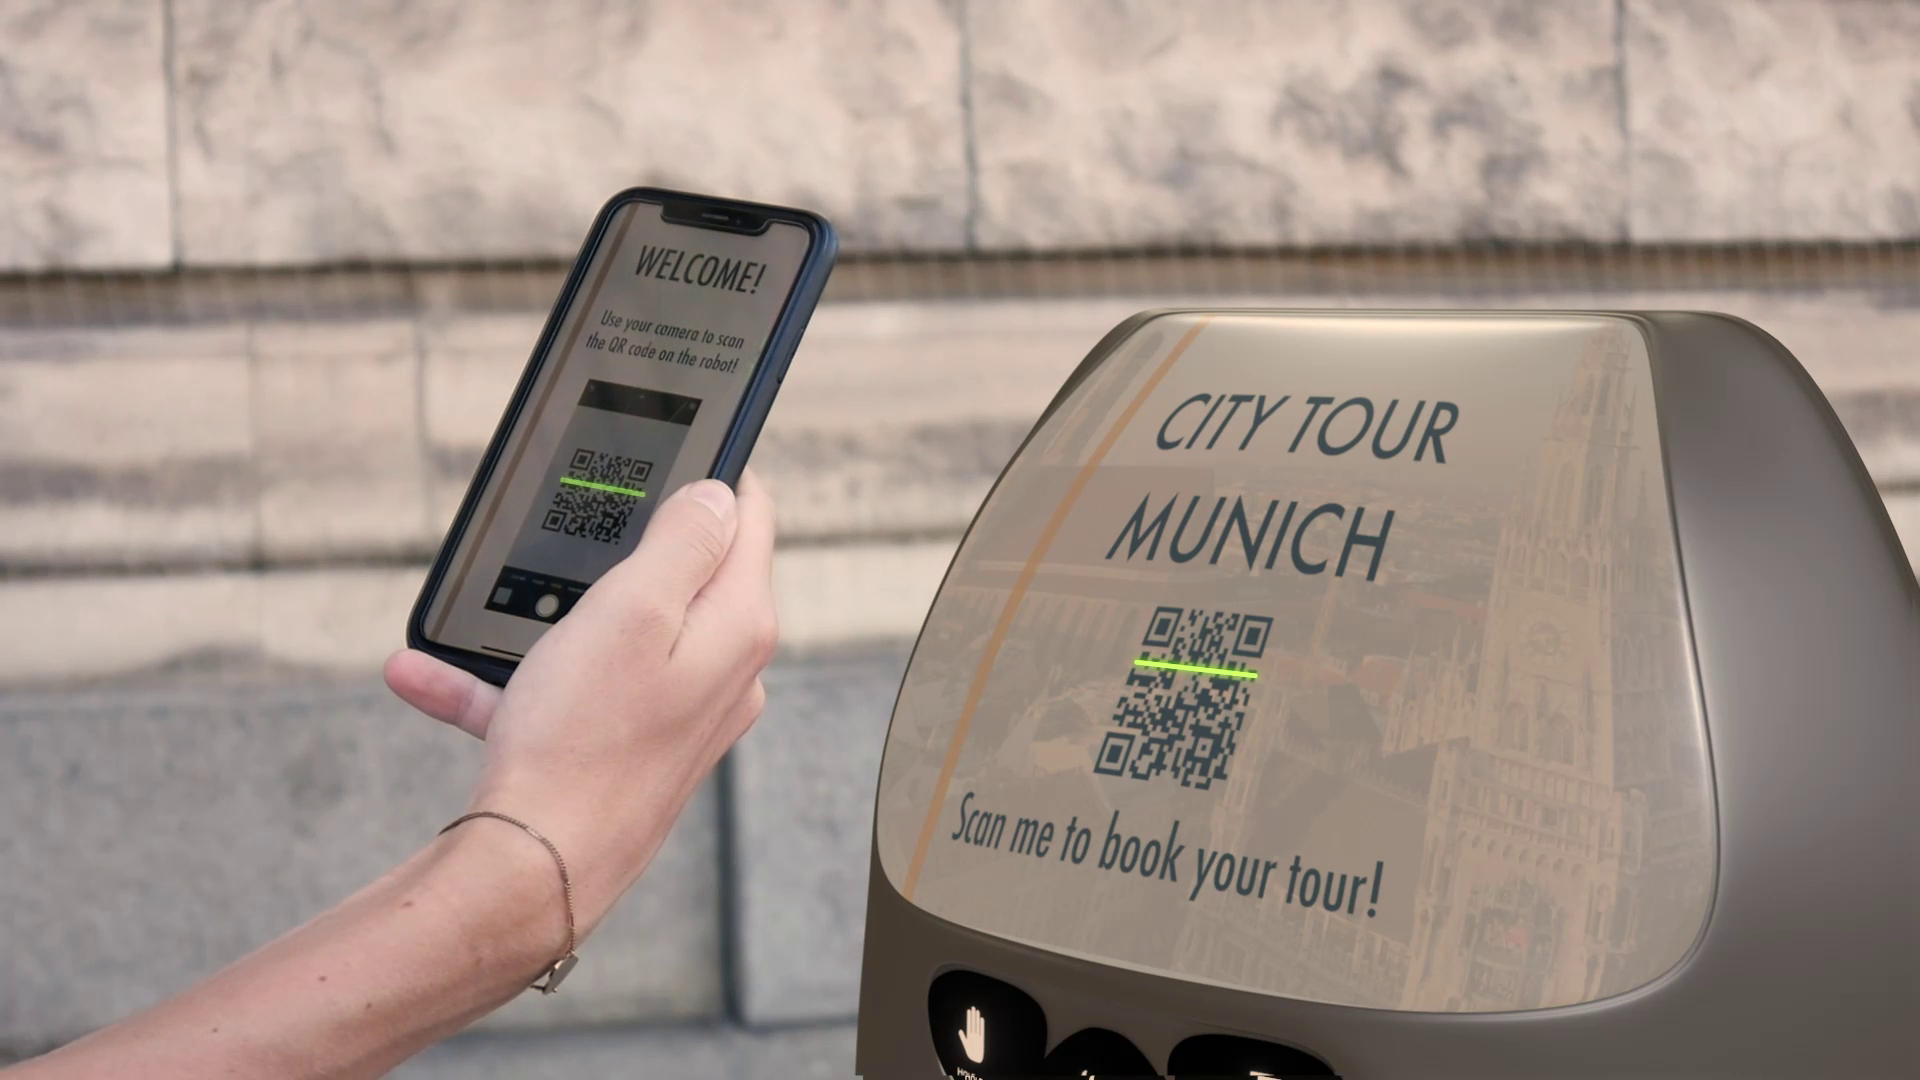
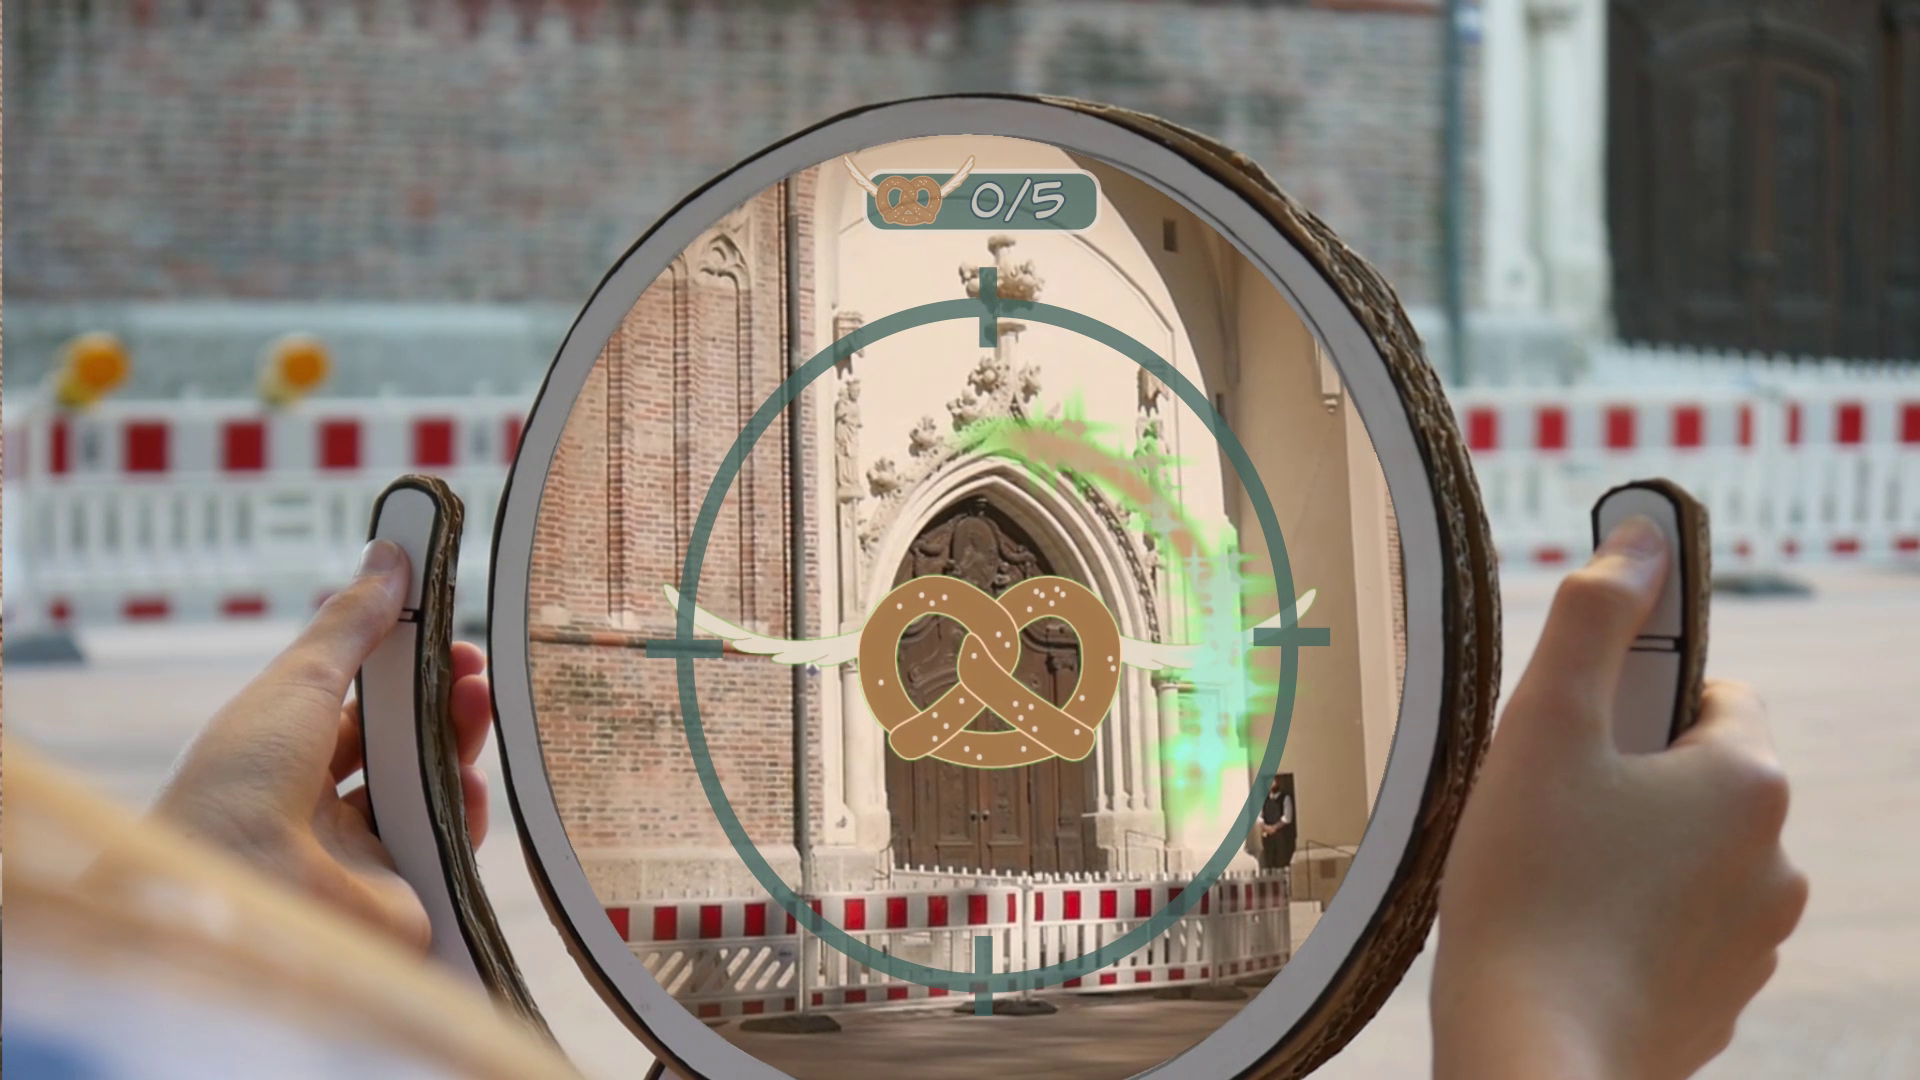
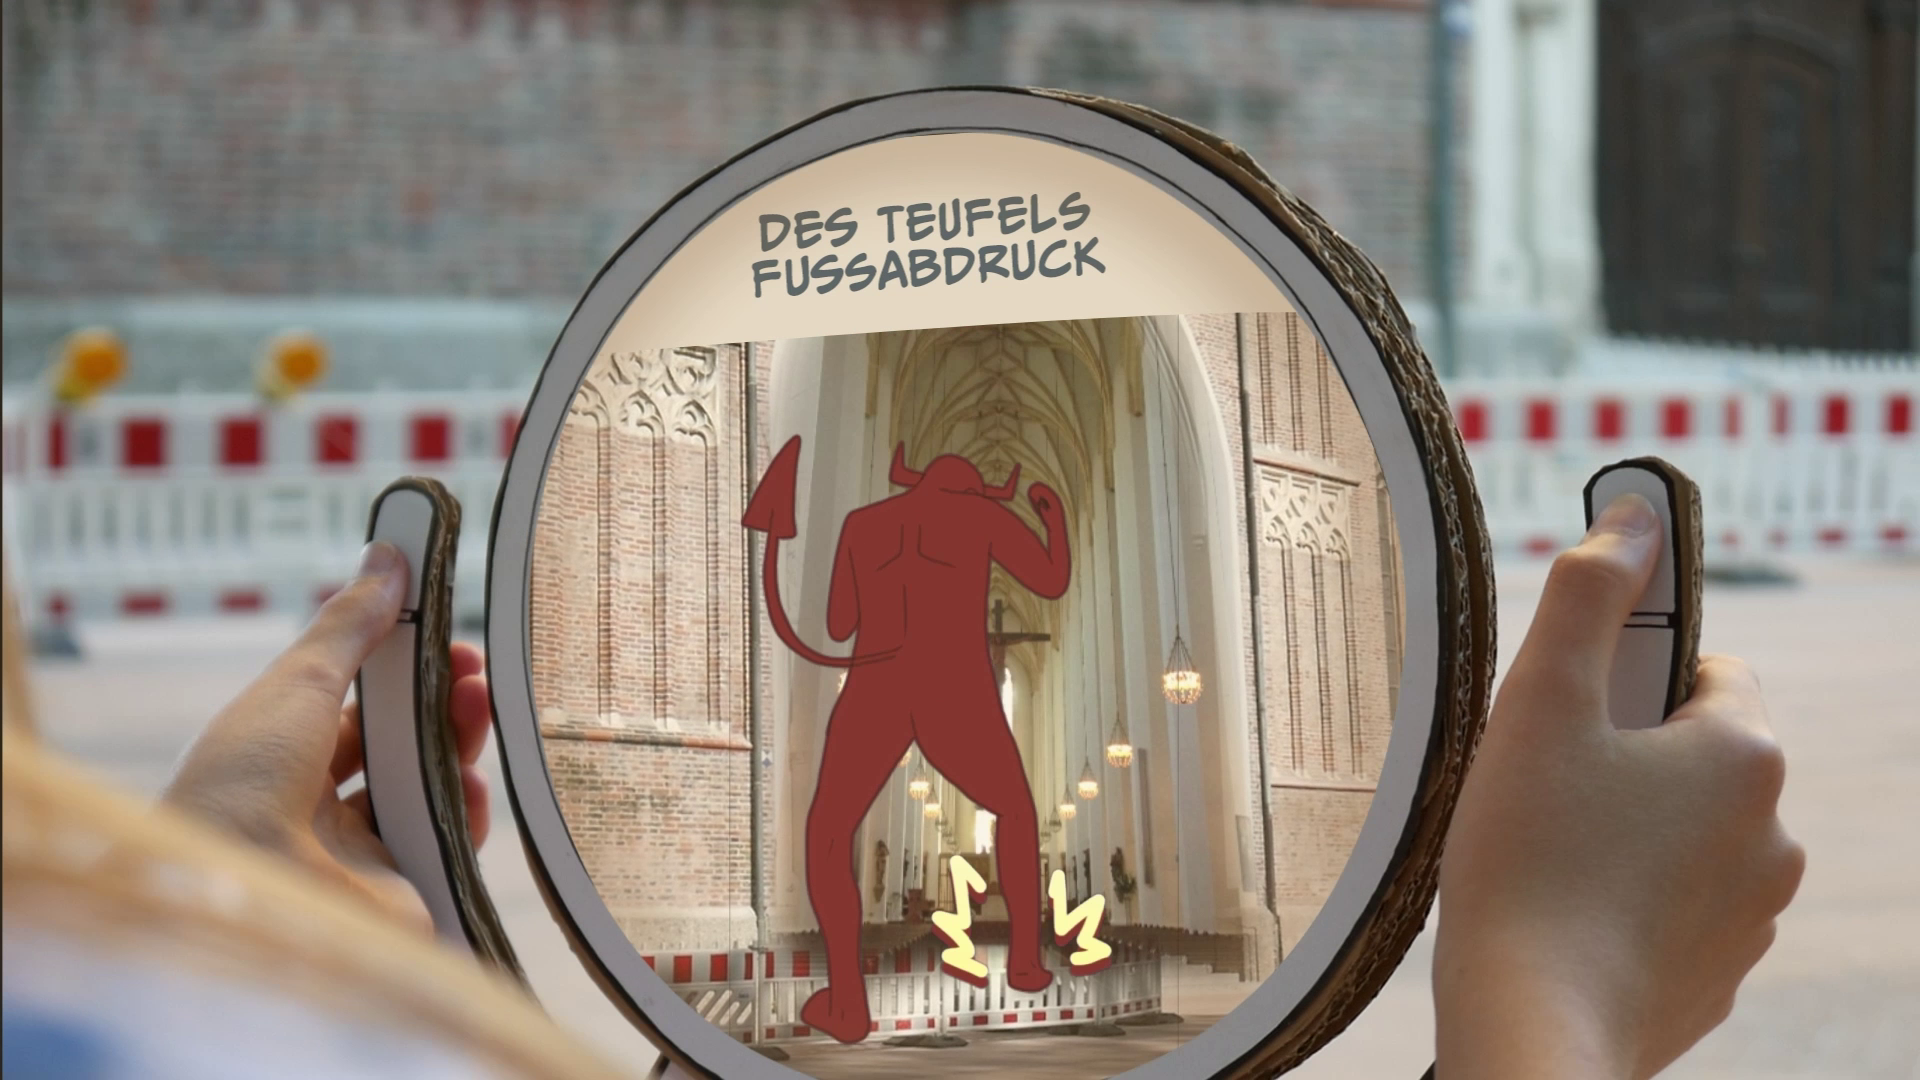
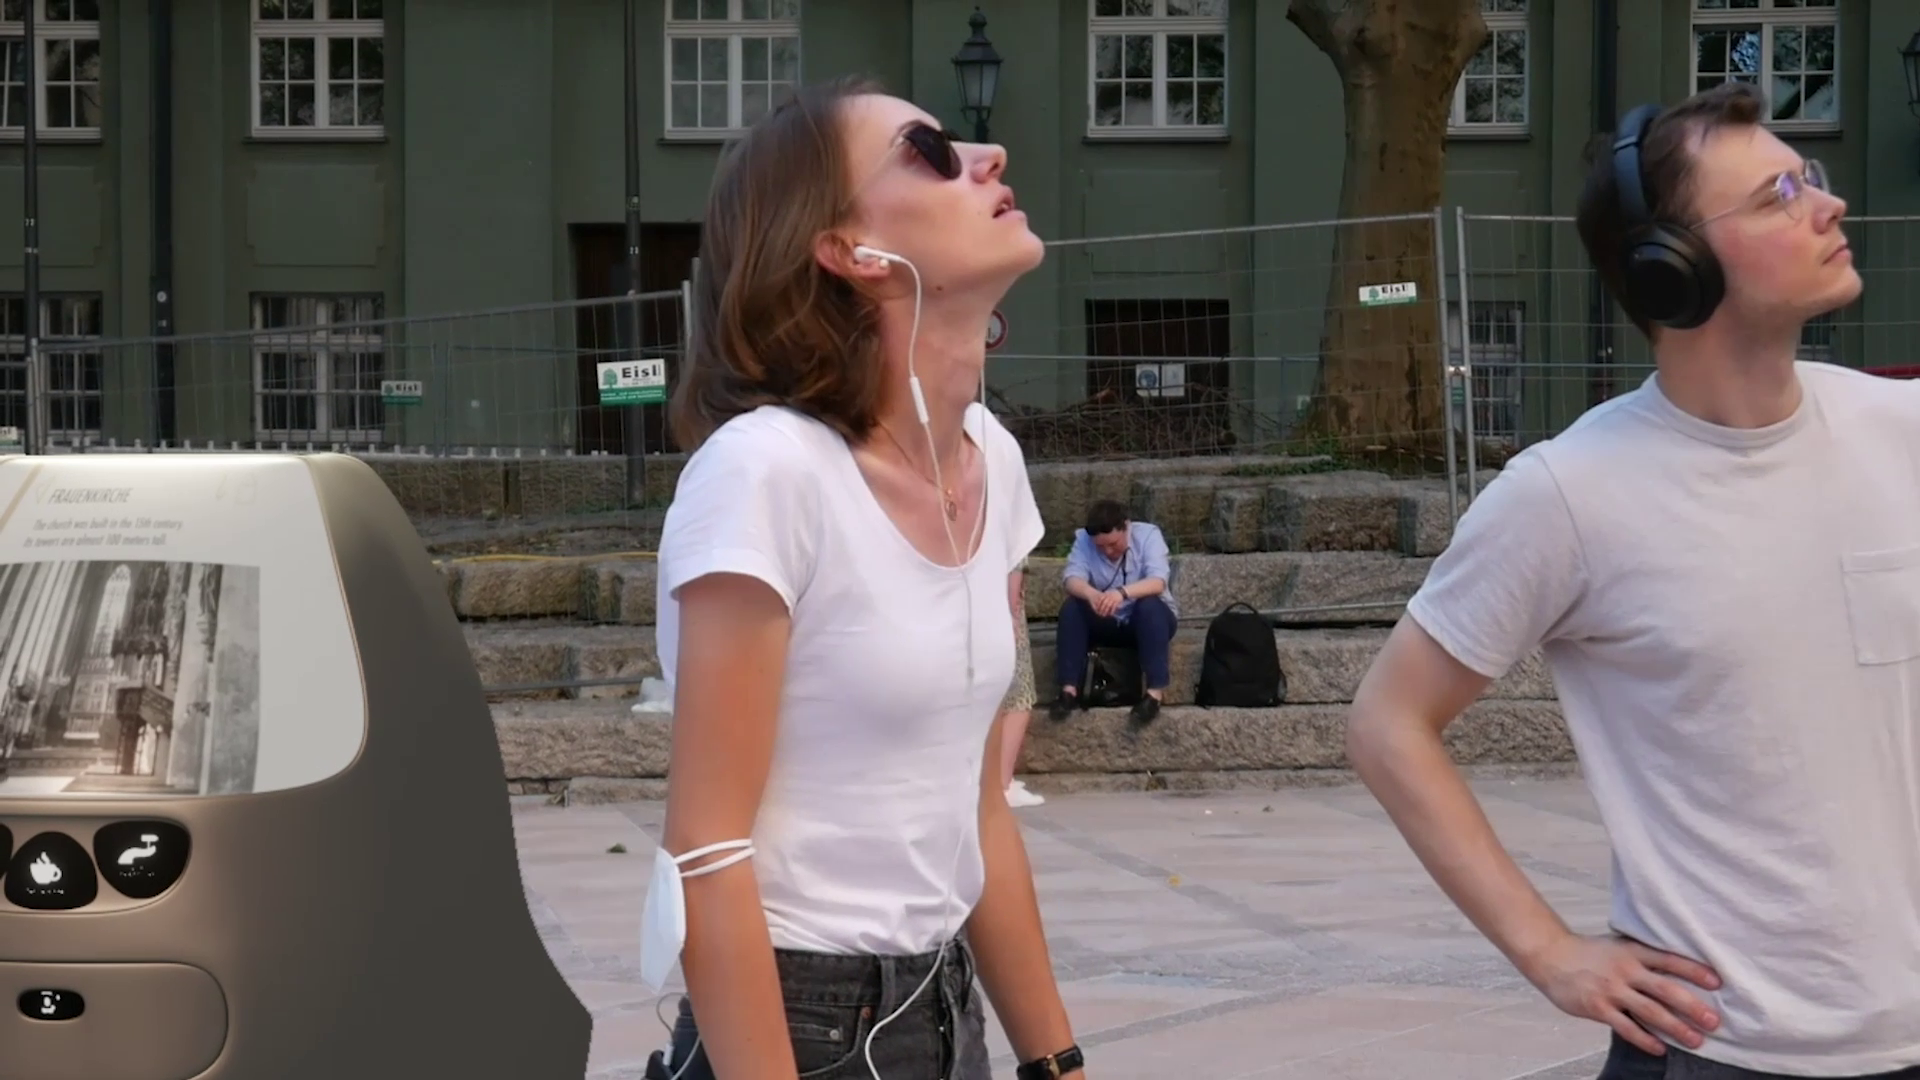
The following video shows only a snippet of our final three minute long video prototype to protect the identity of the minor actress that potrayed the daugther of the starring fictional family Martin.
Elevator Pitch
Our final deliverable also included a five minute elevator pitch introducing our concept and features.
Outcome
The project concluded with a three-minute video prototype and a five-minute elevator pitch, which we presented to the course instructors as part of Design Workshop II. The project remained a concept study within the scope of the workshop. Further development into functional hardware was not part of the course curriculum.
My Take-Aways
- Hardware design extends software design by multiple aspects, including haptic feedback, material, measurements, and alternative GUI presentations. And minding their interplay is crucial for a well-designed experience.
- The design of this robot-prototype will take several more iteration and working together with electro engineers, software developers and mechanics to achieve a first fully functional version.
- Working in a team not only requires good communication, but also letting each other thrive in what we are already capable of while challenging each other to take over tasks we've never done before.
- The designer ≠ the user - Involving user feedback from the beginning is crucial for not forgetting why we are even designing a product.